HumanoidUC Berkeley Hybrid Robotics Lab2024US
Berkeley Humanoid
Low-cost mid-scale research biped for learning-based control, 0.85 m and 16 kg with 12 leg DOF driven by in-house actuators.
Difficulty index
8.7/13| Class | humanoid | +5 |
|---|---|---|
| Cost | unknown · midpoint | +1.5 |
| DOF | 12 DOF | +1.2 |
| Parts | unknown · midpoint | +1 |
Top of the ladder. This robot lives on the humanoid domains.
humanoidrobots.systems/berkeley/humanoid ↗
Full spec sheet and comparisons
humanoidrobot.build/berkeley/humanoid
Closed hardware; no public CAD or BOM.
humanoidrobots.training/berkeley/humanoid ↗
Simulate and train policies
Specimen photographs
4 items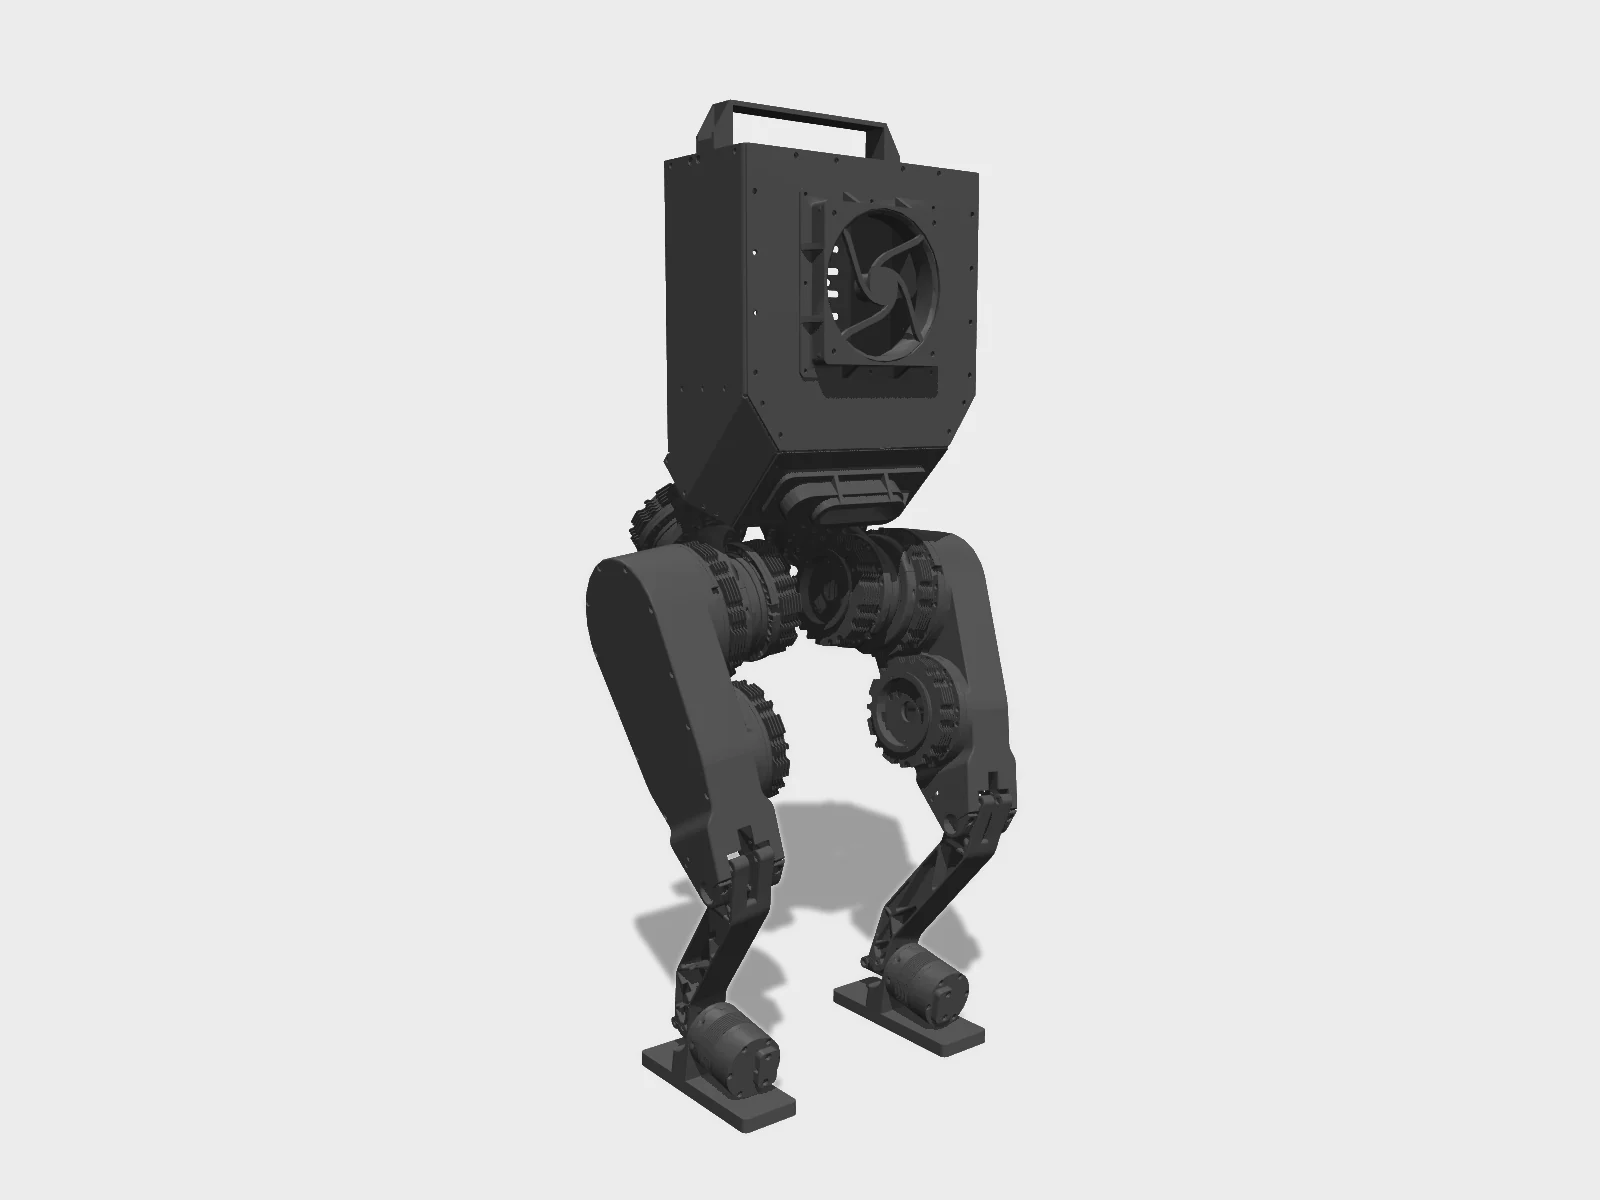
Studio render of the published MJCF, keyframe pose from the model. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/berkeley_humanoid (BSD-3-Clause) · Hyperspawn render · source 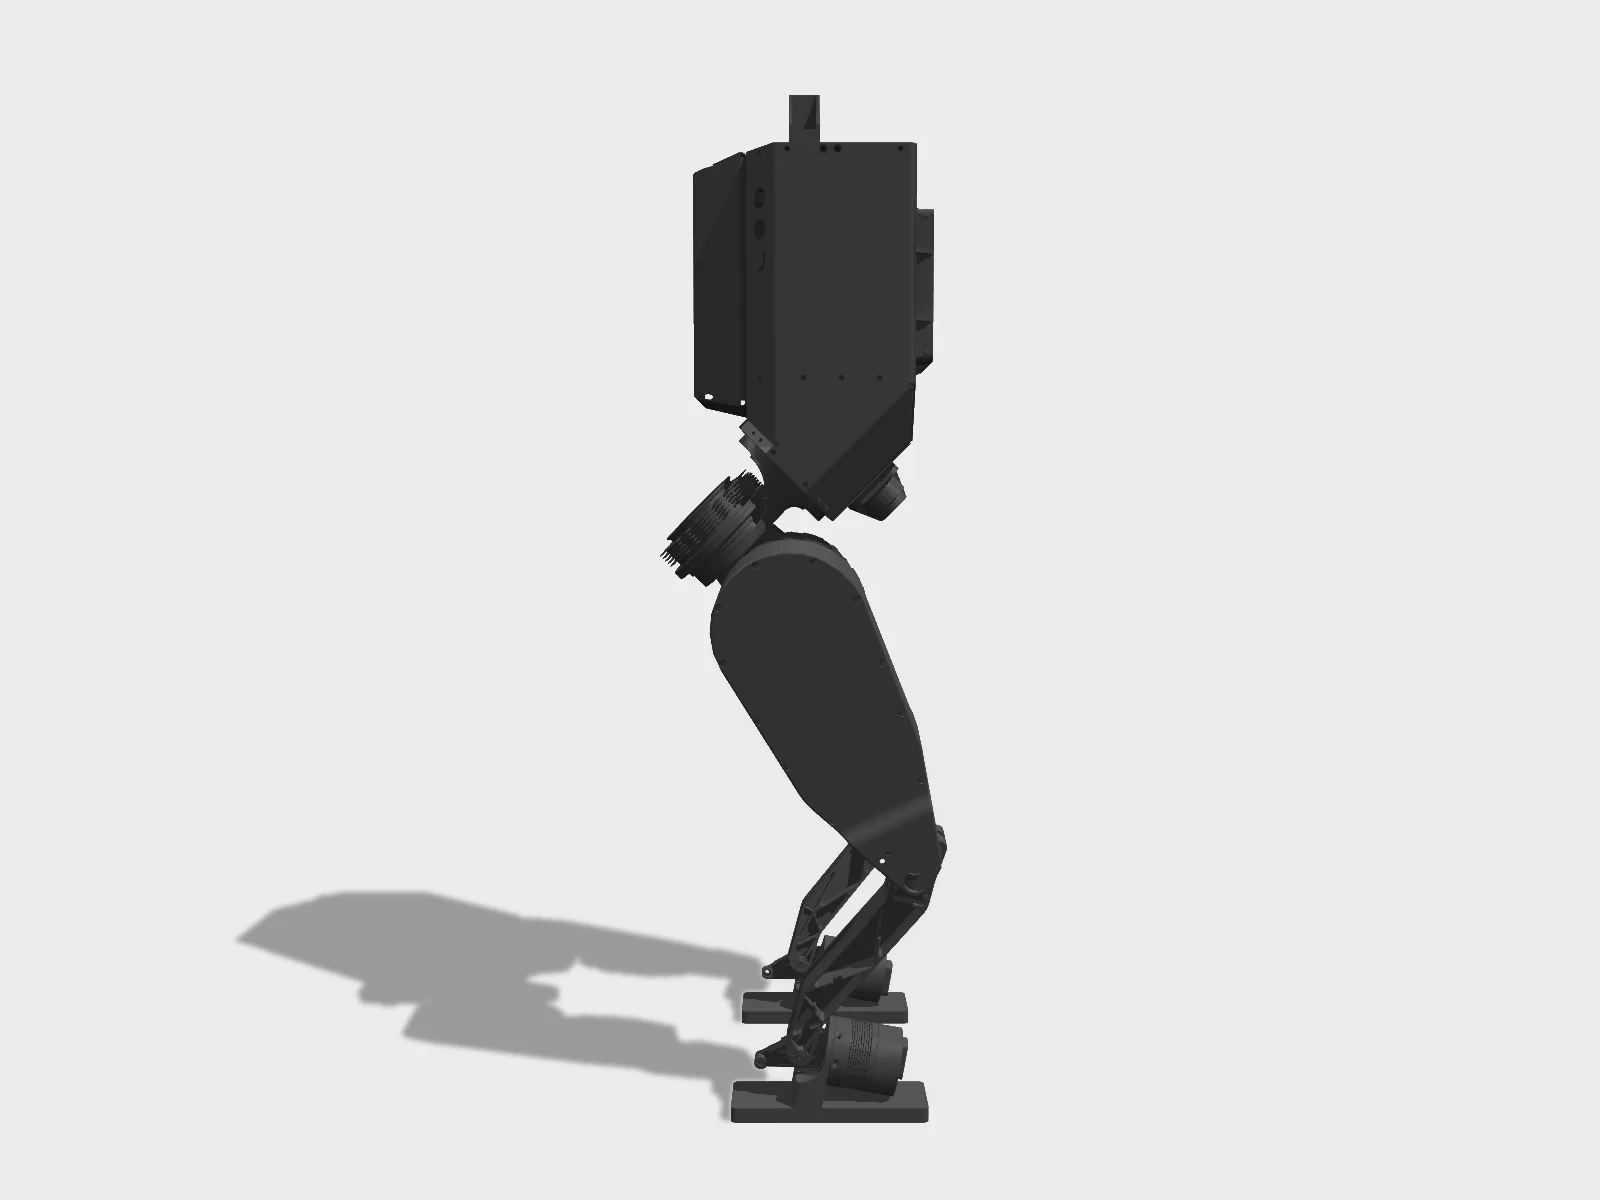
Side view of the same MJCF render, keyframe pose from the model.Rendered by Hyperspawn from mujoco_menagerie/berkeley_humanoid (BSD-3-Clause) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/berkeley_humanoid (BSD-3-Clause) · Hyperspawn render · source Berkeley Humanoid: A Research Platform for Learning-based ControlHybrid Robotics · official video, embedded · source
Spec card
7/13 known- Degrees of freedom
- 12
- Height
- 85 cm
- Mass
- 16 kg
- Price
- not for sale
- Actuators
- custom 5013/8513/8518/10413 motors, 9:1 planetary, EtherCAT
- Compute
- Intel i7-1255U onboard PC
- Sensors
- IMU, joint encoders
Not in the registry: payload, speed, runtime, battery, bom total, part count. Left blank rather than guessed.
What you learn building it
- +Whole-body control
- +Dozens of actuators on one bus
- +Balance and fall handling
- +Safe bring-up of a full-size machine
- +Testing in simulation (URDF/MJCF) before touching hardware
Openness
- not publicCAD
- not publicBOM
- not publicFirmware
- publicSim model
- publicSoftware
- not publicPolicies
Score 30/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Software license: BSD-3-Clause.
Repos & models
Build it
Closed hardware; no public CAD or BOM.humanoidrobot.build/berkeley/humanoid · Closed hardware; no public CAD or BOM.
Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
None. This is the top. Find people building it on humanoidrobots.team.
This is the top of the ladder.
NoteBatteries: two DJI TB50. 4-DOF arms designed but not built in the paper. Open hardware successor is Berkeley Humanoid Lite. isaac_berkeley_humanoid's LICENCE is BSD-3-Clause (GitHub reports NOASSERTION); berkeley_humanoid_description has no license file.
Sources
- [1]arXiv paperchecked 2026-09-24
- [2]Project sitechecked 2026-09-24
- [3]MuJoCo Menageriechecked 2026-09-24