Skip to content
buildrobots.io

A field guide to robots you can build · robotics for everyone

Start with an arm.
End with a humanoid.

Every open robot, sorted by class and by how hard it is to build. Each rung teaches what the next one needs. Same package format and the same /org/robot paths as the humanoid suite.

Robots indexed
72
Non-humanoid
20
Buildable
28
Build packages
30
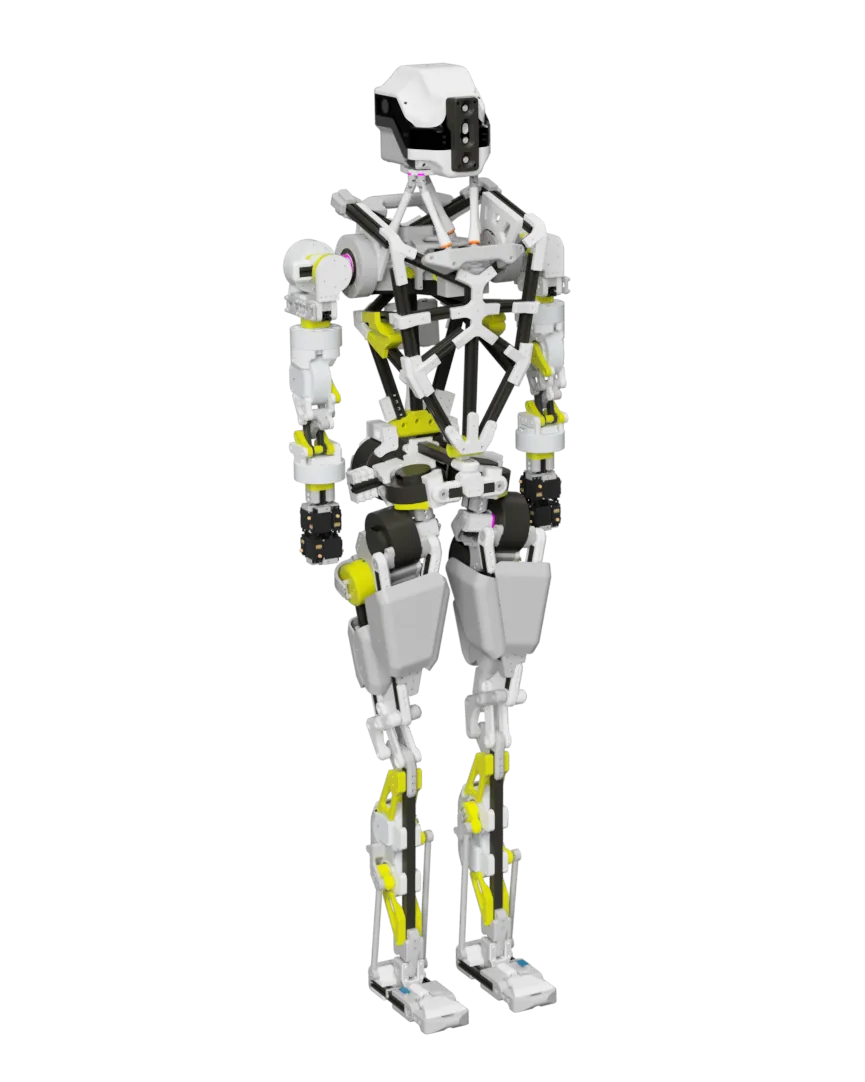
CAD render of the full Dropbear humanoid standing, open printed frame with yellow accent partsPl. Hu · flagship open platformHyperspawn · Hyperspawn

Hyperspawn's own robot · featured, not ranked

Dropbear

Full-size open-source humanoid from Hyperspawn and Pointblank: FDM-printed structure on 20x20 aluminium extrusion, MyActuator CAN actuators, an ESP32 node per limb and a Jetson Orin brain. CAD, BOM, printables, firmware, URDF/MJCF/USD and simulation walking policies are public; a pre-assembled kit is on preorder.

Height
180 cm
Mass
45 kg
DOF
32
BOM lines
94
Priced BOM
$9,948 (86/94)
Build steps
40

Openness

100/100

Difficulty index

12.0
01

Classes

Six classes, ordered by the difficulty they start at. Counts are live from the registry.
02

The starter ladder

Three rungs from first robot to humanoid, picked by a formula over registry data, not by taste. The formula and the full ordering are below.
  1. Rung 02 · Next
    5.5

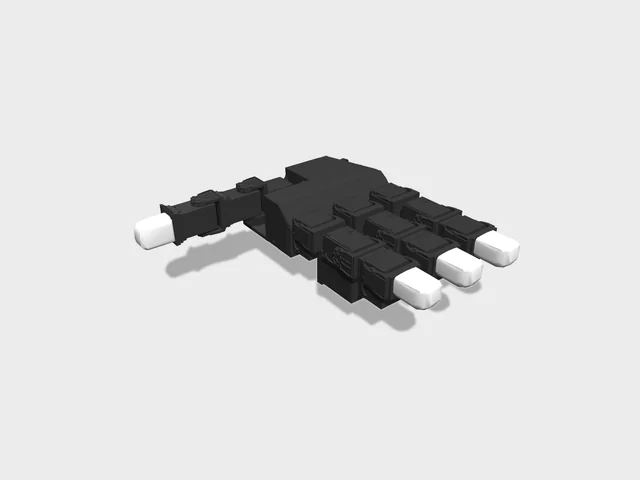
    Aero Hand Open

    Chestnut Robotics (formerly TetherIA) · hand

    Class
    hand
    +3
    Cost
    $324 BOM
    +0.5
    DOF
    7
    +0.7
    Parts
    194
    +1.3
    • →Next class up: arm → hand. Easiest buildable hand (index 5.5).
    • →Adds: tendon and linkage transmissions; controlling many coupled joints.

    Also on this rung: AmazingHand, LEAP Hand

  2. Rung 03 · Humanoid
    8.4

    Z-Bot (Zeroth Bot)

    K-Scale Labs · humanoid

    Class
    humanoid
    +5
    Cost
    $125 BOM
    +0.1
    DOF
    18
    +1.8
    Parts
    315
    +1.5
    • →Easiest of 12 buildable humanoids (index 8.4).
    • →Has an ORP build package.

    Also on this rung: Poppy Humanoid, Duke Humanoid v1

Difficulty index

Lower is easier. Sum of four parts, 1 to 13:

  1. class base 1 to 5

    gripper 1 · rover 1.5 · arm 2 · hand 3 · quadruped 3.5 · humanoid 5

  2. +

    cost 0 to 3

    log10(USD / 100): $100 → 0, $1k → 1, $10k → 2, $100k → 3. BOM total if a build package exists, else list price.

  3. +

    degrees of freedom 0 to 3

    DOF / 10, capped at 3

  4. +

    part count 0 to 2

    log10(parts / 10): BOM quantities + fabricated parts

Unknown facts count at the midpoint (cost 1.5, DOF 1.5, parts 1) so a robot never looks easy just because nobody measured it. Ties go to more known facts, then higher openness, then name. Class bases are this site's editorial rule.

Buildable means: not discontinued or merely announced, and a kit, DIY files, open CAD or a build package. Humanoids also need an open build path on humanoidrobot.build.
Full ordering

28 buildable
Robots, easiest to build first
#RobotIndex
01
SO-101 (SO-ARM101)
The Robot Studio / Hugging Facearm6 DOF
3.7
02
UMI Gripper (Universal Manipulation Interface)
Stanford / Columbia / Toyota Research Institutegripper
4.1
03
LeKiwi
SIGRobotics UIUC / Hugging Face LeRobotrover
4.4
04
AR4
Annin Roboticsarm6 DOF
4.7
05
Koch v1.1 Low-Cost Robot Arm
Alexander Koch / Hugging Face LeRobotarm
4.9
06
Sawppy the Rover
Roger Chengrover
5.4
07
Aero Hand Open
Chestnut Robotics (formerly TetherIA)hand7 DOF
5.5
08
PAROL6
Source Roboticsarm6 DOF
5.7
09
JPL Open Source Rover
NASA Jet Propulsion Laboratoryrover
5.9
10
AmazingHand
Pollen Roboticshand8 DOF
6.5
11
LEAP Hand
Carnegie Mellon Universityhand16 DOF
6.6
12
ALOHA
Stanford (Tony Zhao et al.)arm
6.7
13
Bittle / Bittle X
Petoiquadruped
7.5
14
Pupper v3
Stanford Student Robotics / Hands-On Roboticsquadruped12 DOF
7.6
15
Solo-12
Open Dynamic Robot Initiativequadruped12 DOF
8.2

Top 15 shown. Each class page lists all of its robots.

03

Identify a robot

A dichotomous key, the way field guides do it. Answer each couplet, land on a class.
  1. 1.
    1aBolted to one spotgo to 2
    1bMoves itself aroundgo to 3
  2. 2.
    2aOnly opens and closes on thingsGripper
    2bSeveral joints in a rowgo to 4
  3. 3.
    3aRolls on wheels or tracksRover
    3bWalks on legsgo to 5
  4. 4.
    4aA chain of joints ending in a toolArm
    4bThe joints are fingersHand
  5. 5.
    5aFour legsQuadruped
    5bTwo legs, a torso, usually armsHumanoid
04

Learn

Three paths, arm to quadruped to humanoid, built from 29 checked courses, docs and repos. Each step names a skill, a proof that you have it, and a robot to practise on.
  1. Path 1 · 5 stepsArmA 5 or 6 DOF desktop arm. Kinematics, calibration and teleoperation, then your first learned policy.
  2. Path 2 · 4 stepsQuadrupedFour legs and a robot that can fall. Actuators, gaits, state estimation, then sim-to-real walking.
  3. Path 3 · 4 stepsHumanoidEverything below at once, standing up. Small biped first, then a full humanoid with a published package.

All guides and courses