HumanoidThe Robot Studio & Hugging Face2025FR
HopeJR
Open-source DIY full-size humanoid with dexterous hands and exoskeleton teleoperation, targeting ~$3,000, with LeRobot integration.
Difficulty index
10.7/13| Class | humanoid | +5 |
|---|---|---|
| Cost | $3,000 list | +1.5 |
| DOF | 66 DOF | +3 |
| Parts | 163 parts | +1.2 |
Top of the ladder. This robot lives on the humanoid domains.
Specimen photographs
3 items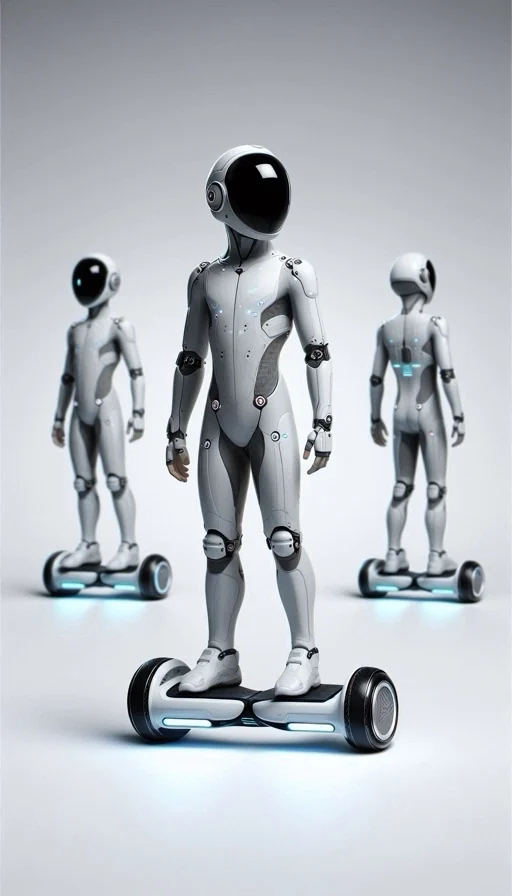
Concept artwork from the HOPEJr Humanoid folder, not a photo of a build.The Robot Studio (HOPEJr) · Apache-2.0 · source HOPEJr assembled for the first time at Humanoids Summit London 25therobotstudio · official video, embedded · source HOPEJr now integrated with LeRobot from HuggingFace!therobotstudio · official video, embedded · source

Spec card
4/13 known- Degrees of freedom
- 66
- Price
- $3,000 · ~$3,000 target (May 2025); first units planned for end of 2025, delivery not verified
- Part count
- 163
- Actuators
- Robstride 02 (humanoid body update)
Not in the registry: height, mass, payload, speed, runtime, battery, bom total, compute, sensors. Left blank rather than guessed.
What you learn building it
- +Whole-body control
- +Dozens of actuators on one bus
- +Balance and fall handling
- +Safe bring-up of a full-size machine
- +FDM 3D printing: 7 parts
- +Tools used: FDM printer, Arduino IDE (or arduino-cli) with ESP32 core, Host computer (Linux/macOS), Python, USB camera (OpenCV)
- +14 assembly steps across 7 subassemblies
- +Flashing firmware for Homunculus exoskeleton PCB (ESP32-C3, Arm/code/exo.cs), Homunculus glove PCB (ESP32-C3, Arm/code/glove.cs), Robot arm + hand: stock Feetech servo firmware driven from LeRobot over URT-1 / Waveshare bus adapters
- +Testing in simulation (URDF/MJCF) before touching hardware
Openness
- publicCAD
- publicBOM
- publicFirmware
- publicSim model
- publicSoftware
- not publicPolicies
Score 90/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10.
Repos & models
Build it
Has an ORP build package.Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
None. This is the top. Find people building it on humanoidrobots.team.
This is the top of the ladder.
NoteRepo has no LICENSE detected by GitHub (license API returns none, 2026-09-25); Humanoid/LICENSE is Apache-2.0 text with an 'all rights reserved' header and covers only Humanoid/, so no license is declared here. Arm/hand + exoskeleton (Arm/ dir, LeRobot) is the most developed part. sim=true rests on the right-leg + pelvis URDF only. Commercial shipping status in 2026 unconfirmed. HQ left null (joint project). Repo last pushed May 2026.
Sources
- [1]TechCrunchchecked 2026-09-24
- [2]Official repochecked 2026-09-24
- [3]HOPEJr Humanoid/URDF/Right_Leg (only URDF)checked 2026-09-25
- [4]LeRobot HopeJR docs (arm, hand, exoskeleton, glove)checked 2026-09-25