HumanoidMenlo Research (Asimov)2026SG
Asimov 1
1.2 m, 35 kg open-source biped with 25 actuated DOF, sold as an unassembled DIY kit or self-sourced from the published BOM and CAD.
Difficulty index
11.8/13| Class | humanoid | +5 |
|---|---|---|
| Cost | $20k list | +2.3 |
| DOF | 25 DOF | +2.5 |
| Parts | 969 parts | +2 |
Top of the ladder. This robot lives on the humanoid domains.
Specimen photographs
5 items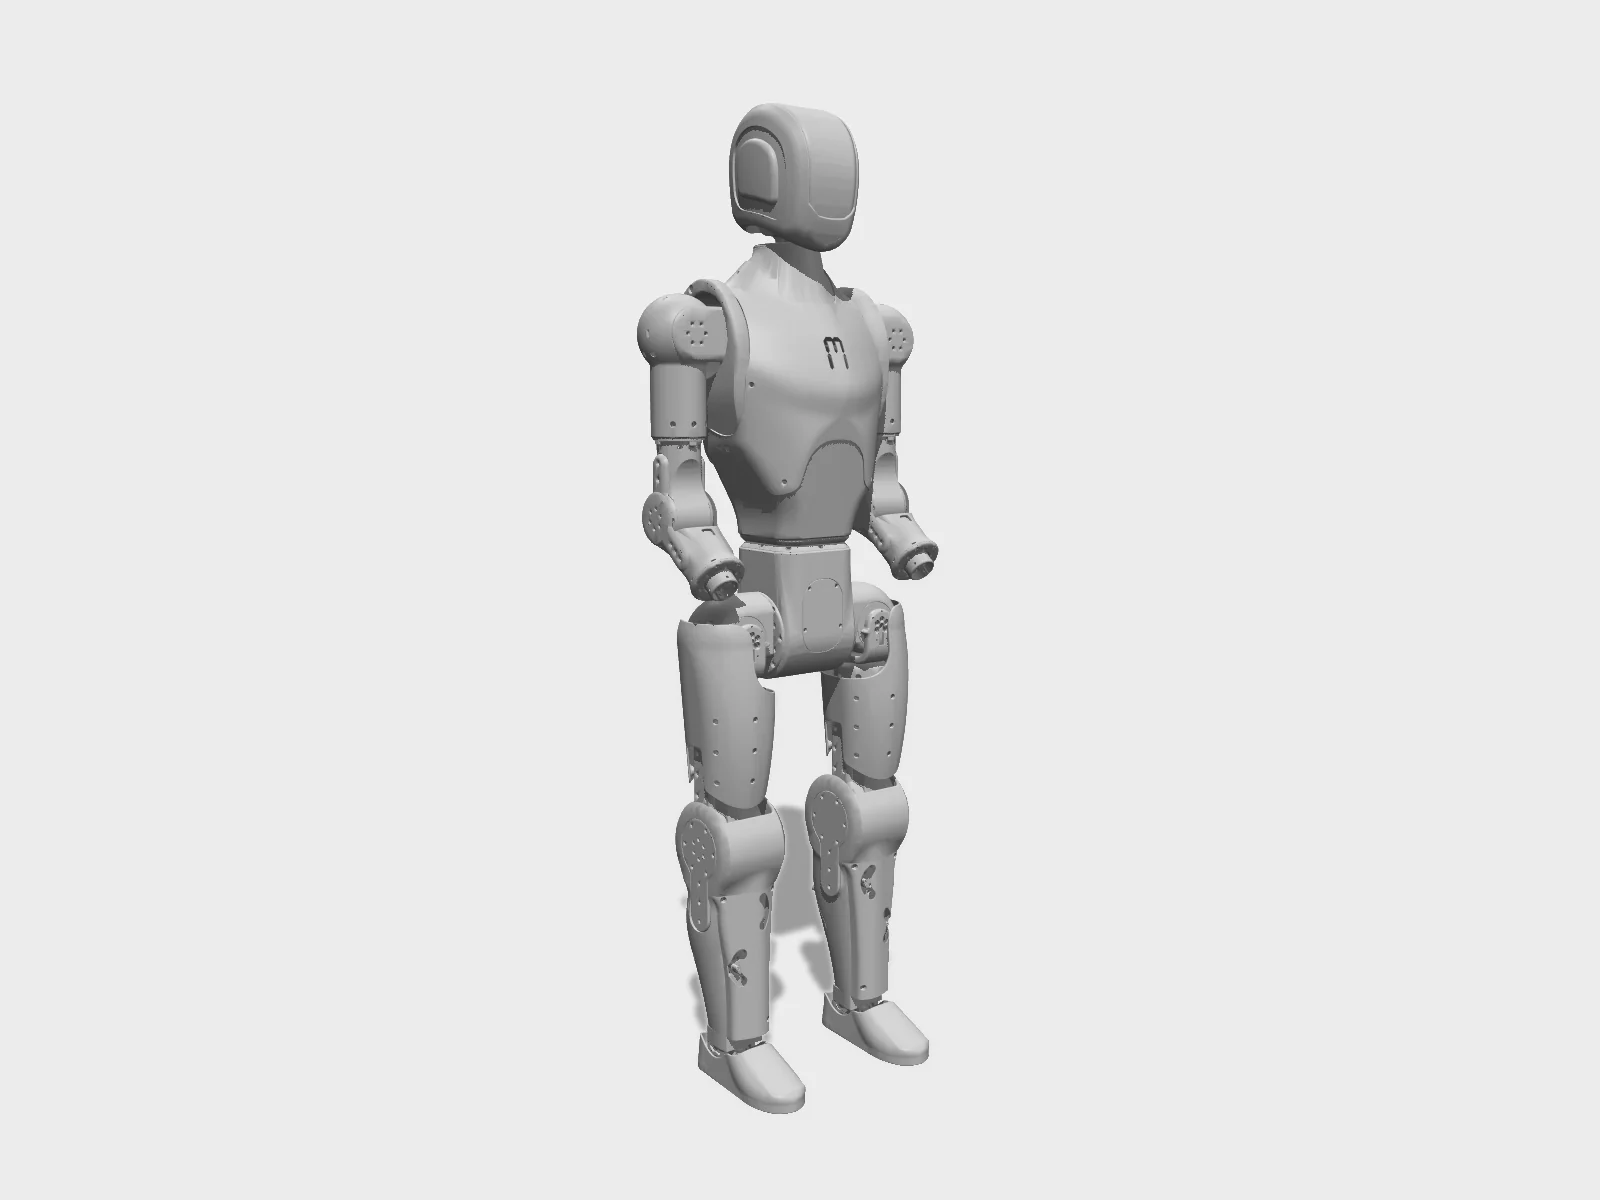
Studio render of the published MJCF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from menloresearch/asimov-1 (CERN-OHL-S-2.0) · Hyperspawn render · source 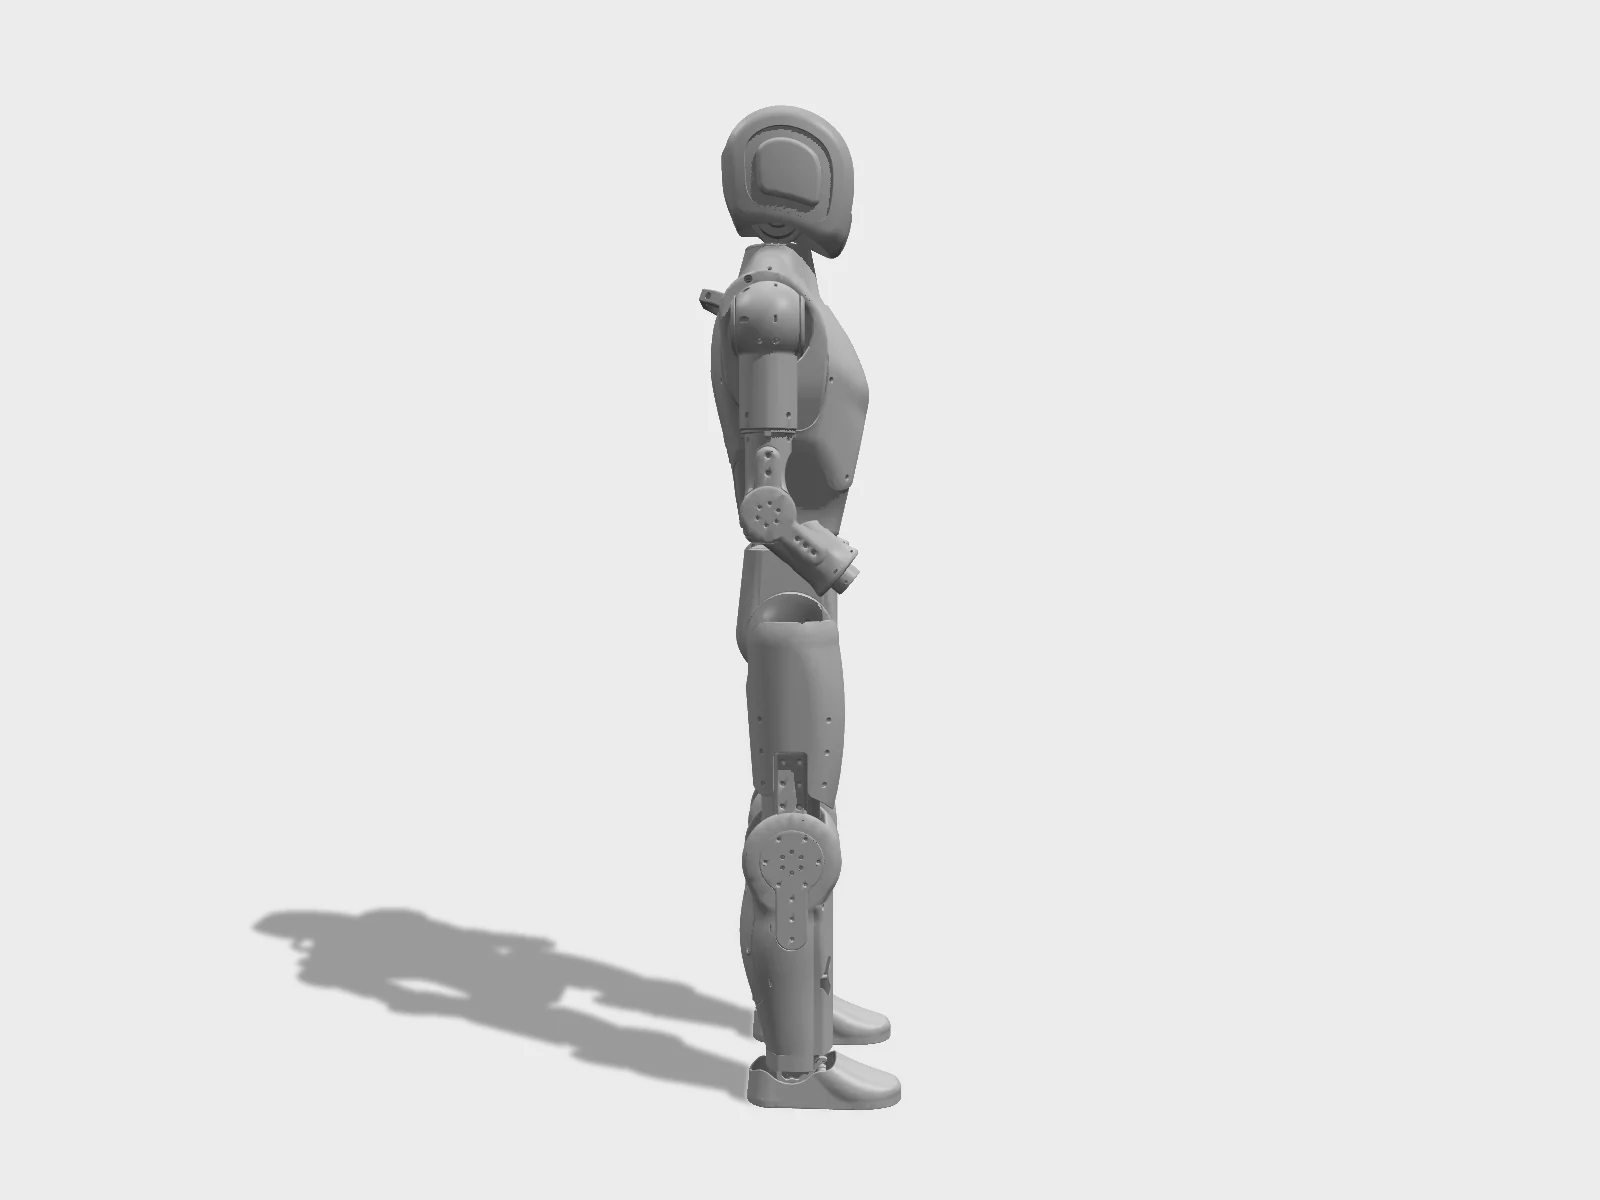
Side view of the same MJCF render, the model's zero pose.Rendered by Hyperspawn from menloresearch/asimov-1 (CERN-OHL-S-2.0) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from menloresearch/asimov-1 (CERN-OHL-S-2.0) · Hyperspawn render · source 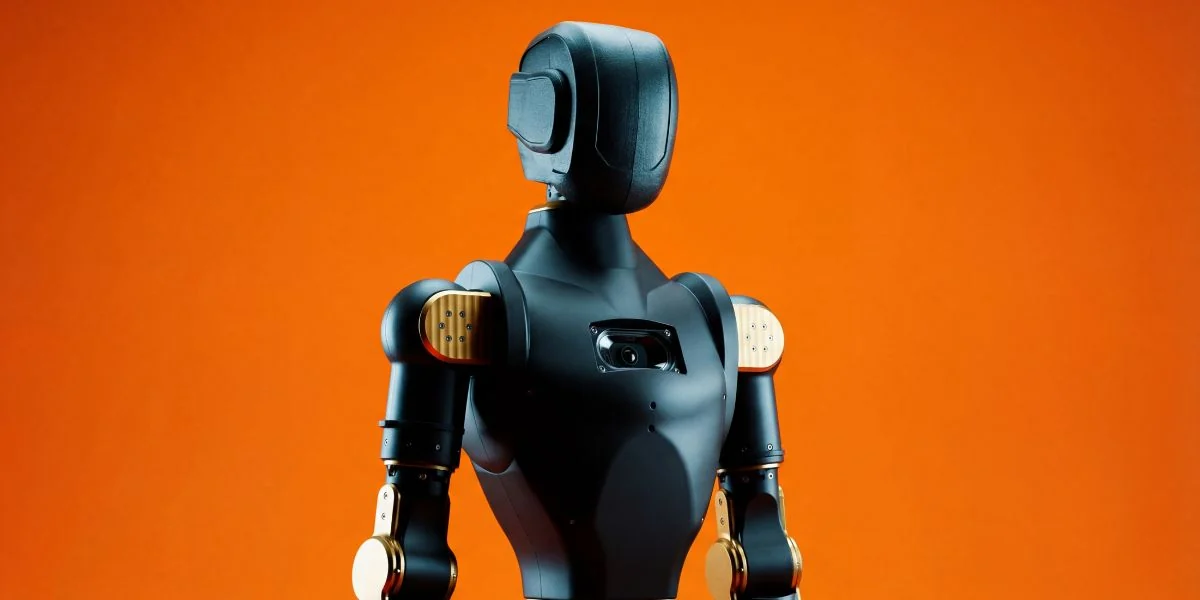
From the asimov-1 README.Menlo Research (asimov-1) · CERN-OHL-S-2.0 · source We're open-sourcing Asimov v1, a humanoid robotAsimov · official video, embedded · source

Spec card
8/13 known- Degrees of freedom
- 25
- Height
- 120 cm
- Mass
- 35 kg
- Price
- $20k · DIY kit $20,000 shipping (README); announced Mar 2026 at $15,000 target with $499 deposit
- Part count
- 969
- Actuators
- CAN-bus actuators; 6 DOF/leg, 5 DOF/arm, 1 waist, 2 neck; RSU ankle with passive toes
- Compute
- Raspberry Pi 5 (media/network) + Radxa CM5 (motion control)
- Sensors
- 2MP monocular camera, stereo mic array, 6-DOF IMU, joint states
Not in the registry: payload, speed, runtime, battery, bom total. Left blank rather than guessed.
What you learn building it
- +Whole-body control
- +Dozens of actuators on one bus
- +Balance and fall handling
- +Safe bring-up of a full-size machine
- +CNC machining: 43 parts
- +SLS printing (usually a print service): 55 parts
- +Tools used: metric Allen keys 2/2.5/3/4/5/6 mm (included), Phillips screwdriver, flush cutters, wire strippers, heat gun, soldering iron + third hand, digital multimeter, masking/paper tape +6
- +14 assembly steps across 8 subassemblies
- +Flashing firmware for Radxa CM5 on RPU (asimov-rpu-v<version>.img.xz via rkdeveloptool, RK3588 SPL loader v1.15.113), Raspberry Pi 5 (asimov-rpi-v<version>.img.xz via Raspberry Pi Imager manifest), 25 Encos EC-A actuators (CAN ID assignment via dashboard)
- +Testing in simulation (URDF/MJCF) before touching hardware
Openness
- publicCAD
- not publicBOM
- publicFirmware
- publicSim model
- publicSoftware
- not publicPolicies
Score 70/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Hardware license: CERN-OHL-S-2.0. Software license: GPL-2.0.
Repos & models
Build it
Has an ORP build package.Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
None. This is the top. Find people building it on humanoidrobots.team.
This is the top of the ladder.
NoteKit announced Mar 2026; CAD and sim model open-sourced Apr 2026; shipments reported from Aug 2026. Hands not included in the kit. Build pages send buyers to the maker's own kit first. Repo asimovinc/asimov-v1 redirects to menloresearch/asimov-1. bom=false: docs gate the BOM behind a request form. policies=false: the locomotion policy ships inside the RPU firmware image, not as a separate published file.
Sources
- [1]Official repo READMEchecked 2026-09-24
- [2]Humanoids Daily kit launchchecked 2026-09-24
- [3]eWeek (Singapore-based)checked 2026-09-24