HandPollen Robotics2025FR
AmazingHand
Fully 3D-printable 8-DOF four-finger humanoid hand with all actuators inside the hand, designed for Pollen's Reachy2 wrist but adaptable.
Difficulty index
6.5/13| Class | hand | +3 |
|---|---|---|
| Cost | unknown · midpoint | +1.5 |
| DOF | 8 DOF | +0.8 |
| Parts | 152 parts | +1.2 |
Specimen photographs
7 items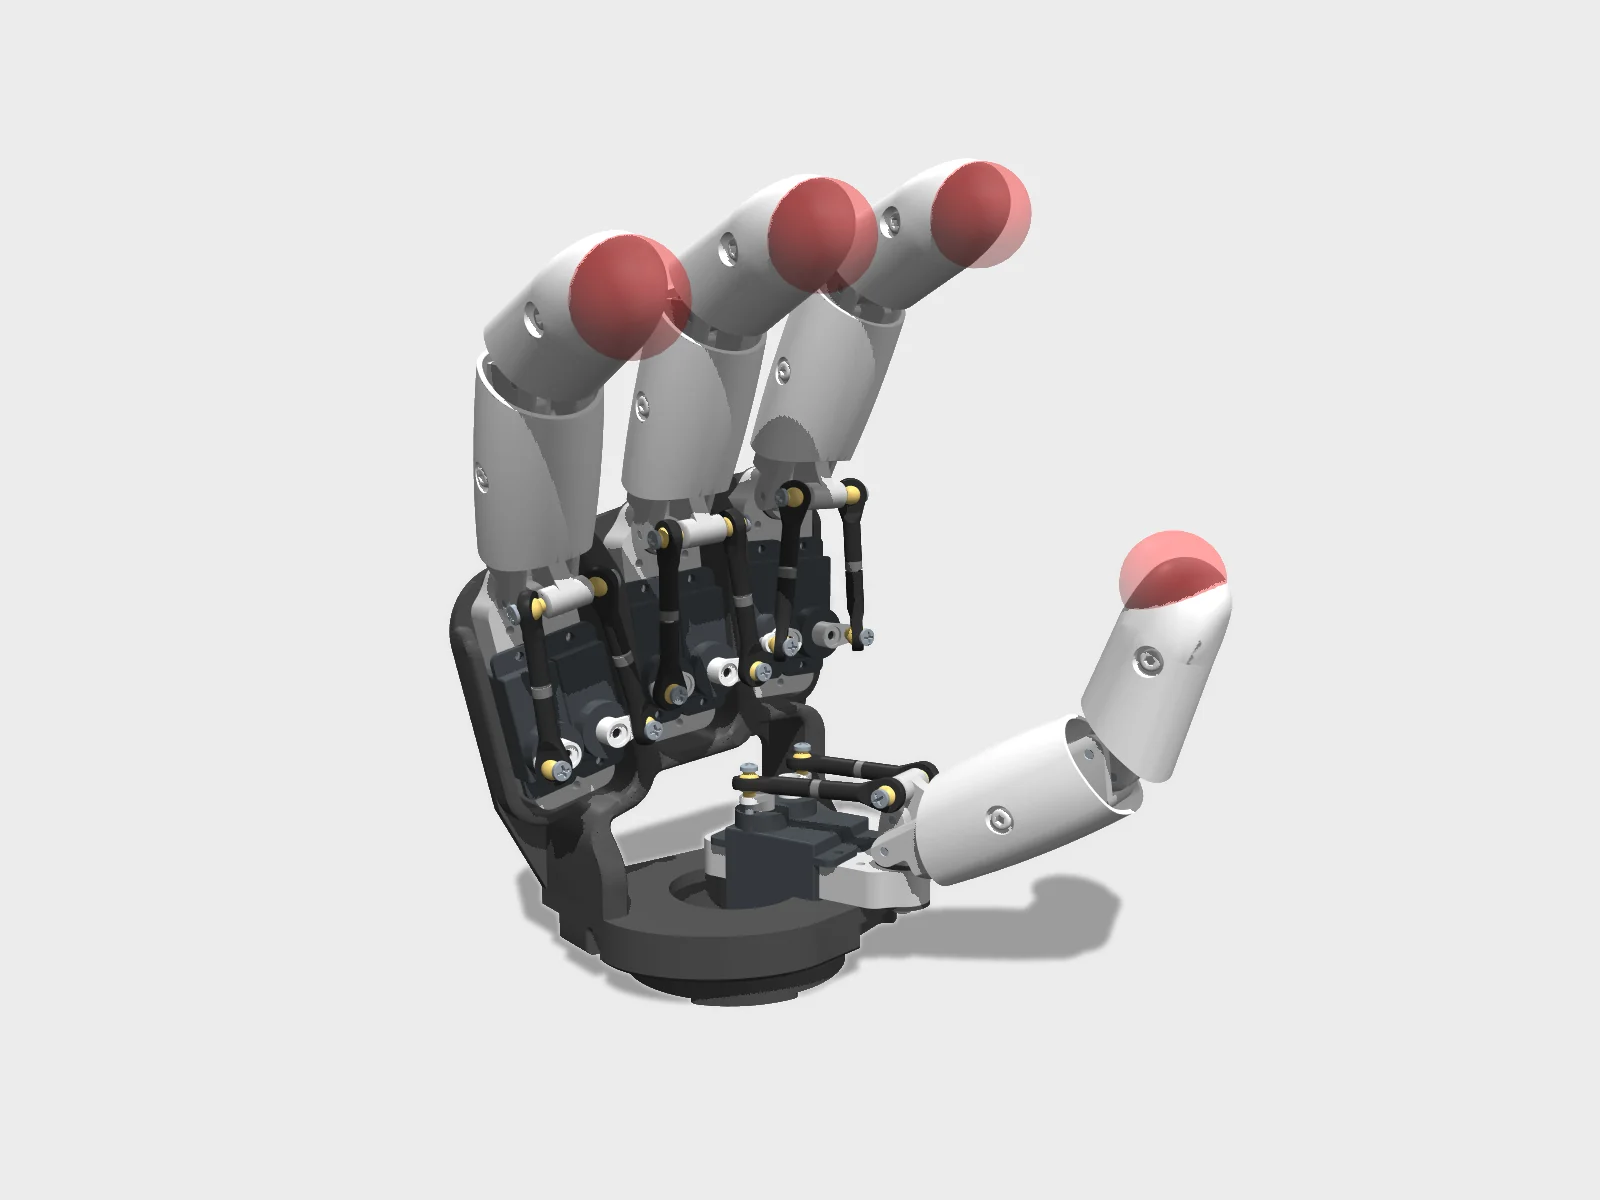
Studio render of the published MJCF, keyframe pose from the model. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from pollen-robotics/AmazingHand (Apache-2.0) · Hyperspawn render · source 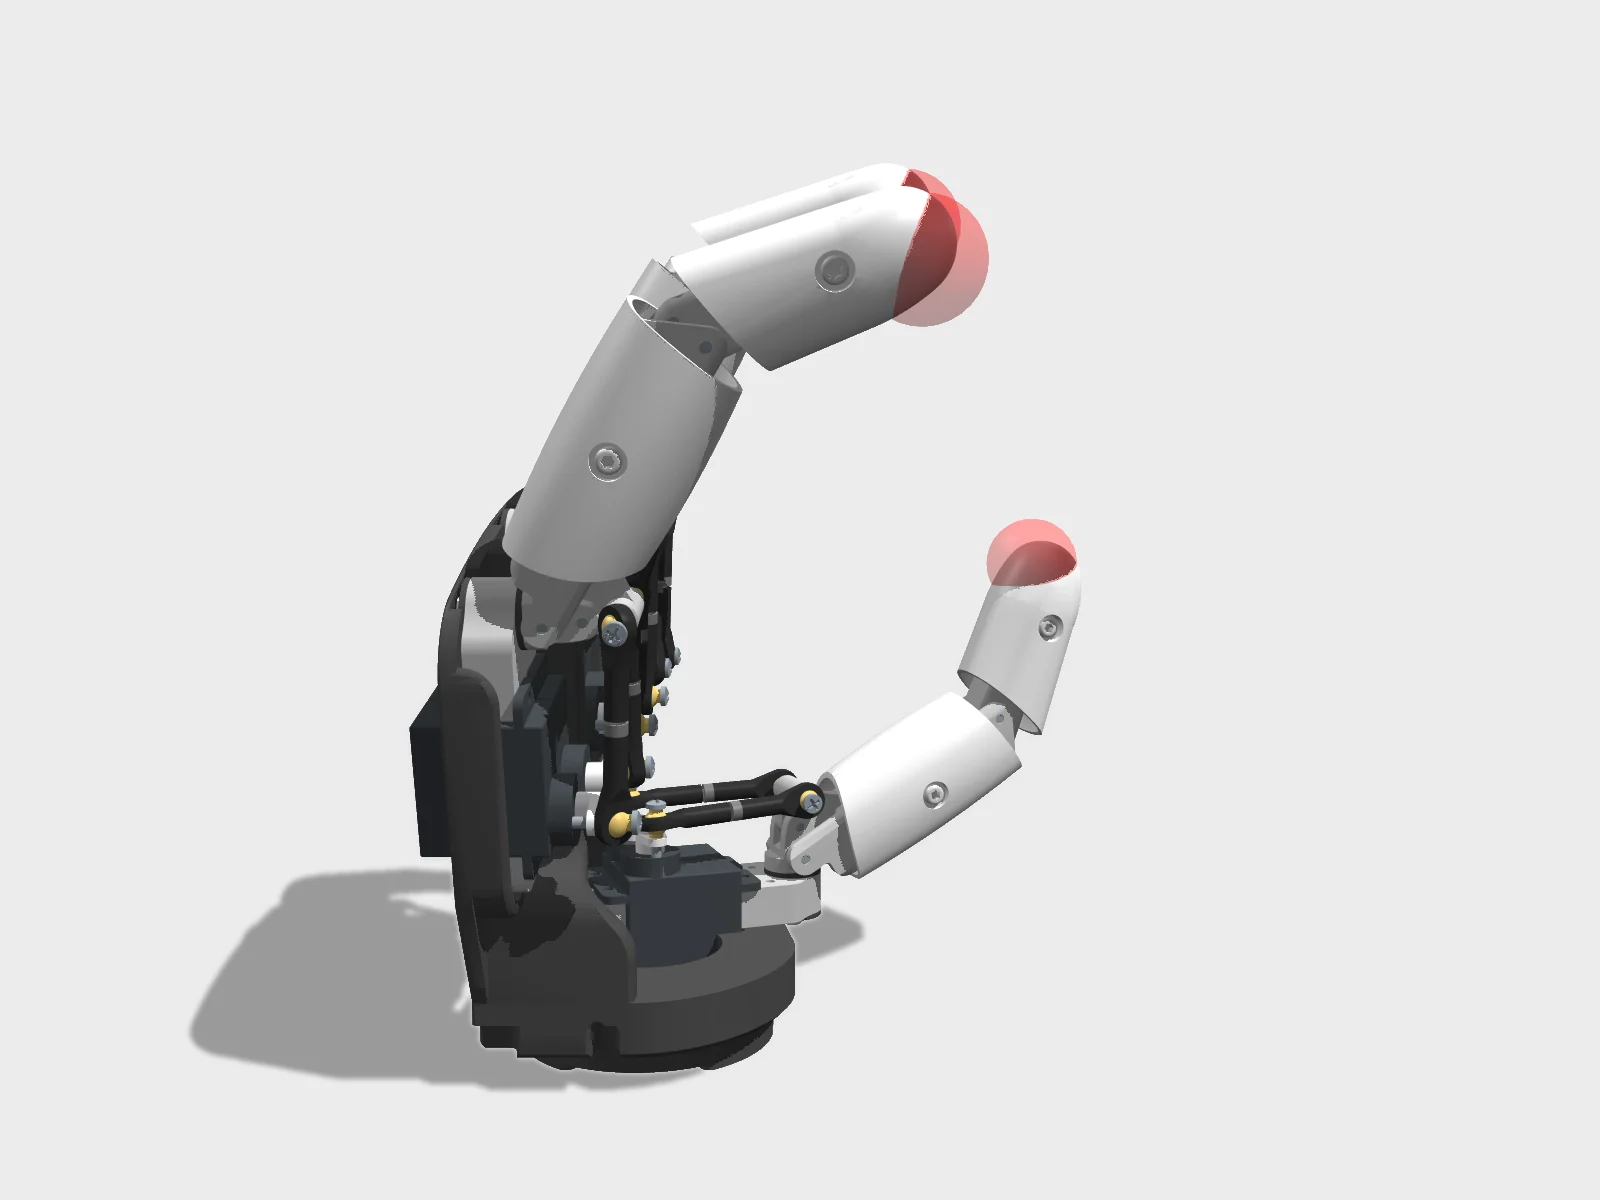
Side view of the same MJCF render, keyframe pose from the model.Rendered by Hyperspawn from pollen-robotics/AmazingHand (Apache-2.0) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from pollen-robotics/AmazingHand (Apache-2.0) · Hyperspawn render · source 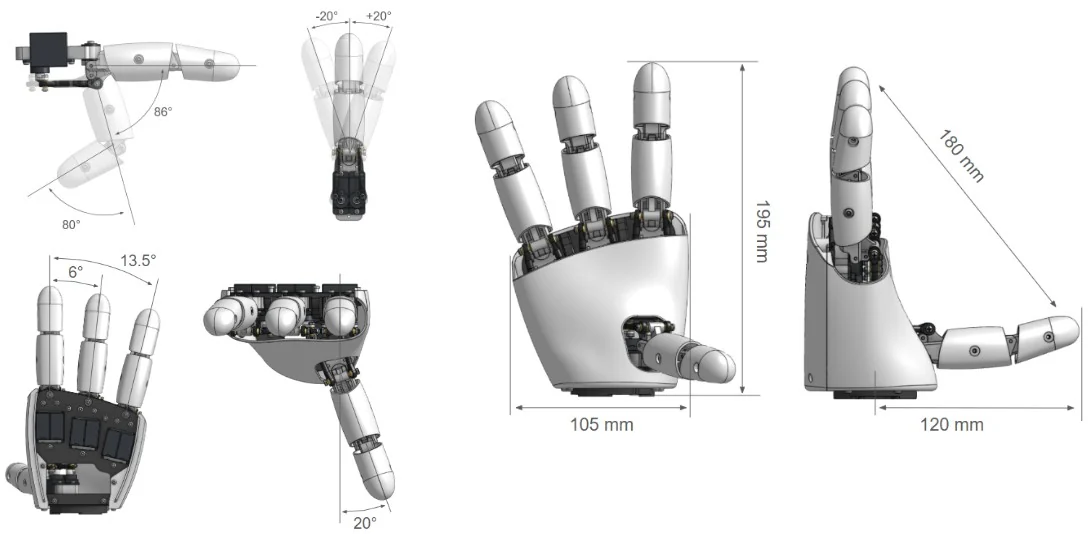
Overview drawing from the AmazingHand README.Pollen Robotics (AmazingHand) · Apache-2.0 · source 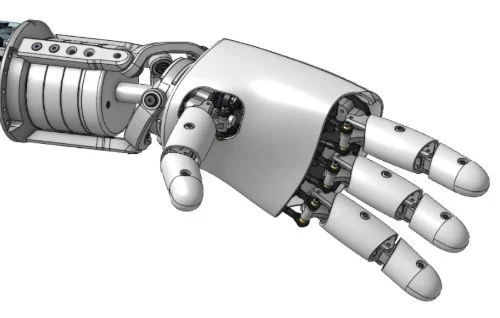
From the AmazingHand README.Pollen Robotics (AmazingHand) · Apache-2.0 · source Amazing handPollen Robotics · official video, embedded · source Amazing Hand x Reachy 2 🤯Pollen Robotics · official video, embedded · source


Spec card
4/13 known- Degrees of freedom
- 8
- Mass
- 0.4 kg
- Part count
- 152
- Actuators
- 8x Feetech SCS0009 servos (2 per finger)
Not in the registry: height, payload, speed, runtime, battery, price, bom total, compute, sensors. Left blank rather than guessed.
What you learn building it
- +Tendon and linkage transmissions
- +Controlling many coupled joints
- +Tactile and proprioceptive sensing
- +Cable routing in tight spaces
- +FDM 3D printing: 47 parts
- +Tools used: FDM printer, FDM printer with a short extruder-to-hotend path (direct drive), Dremel with abrasive disk (or strong cutting pliers), Portable drill, 1.5 mm drill bit, M2 tap, Flat pliers, 2 mm drill bit +8
- +21 assembly steps across 8 subassemblies
- +Flashing firmware for Feetech SCS0009 bus (IDs 1-8, 1 Mbaud), Waveshare serial bus servo driver + host Python (rustypot), Arduino Mega 2560 + Feetech TTLinker (SCServo library)
- +Testing in simulation (URDF/MJCF) before touching hardware
Openness
- publicCAD
- publicBOM
- publicFirmware
- publicSim model
- publicSoftware
- not publicPolicies
Score 90/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Hardware license: CC-BY-4.0. Software license: Apache-2.0.
Repos & models
Build it
Has an ORP build package.- BOM total
- unpriced
- Lines priced
- 0/15
- Parts
- 152
- Steps
- 21
- Version
- 0.1.0
15 lines have no price yet, so the real total is higher.
Largest BOM lines
| Part | Qty | Unit |
|---|---|---|
| Feetech SCS0009 serial bus micro servo (2 per finger; package includes cross horn, 2x7 screws and M2x4 horn screw)SCS0009 | 8 | ? |
| M2 ball joint, L19 mm (supplied with M2x12 screw and M2 nuts) | 16 | ? |
| M2 threaded rod, 300 mm (cut into 4 long and 8 short rods) | 1 | ? |
| Steel axis (dowel pin) D2 x 10 mm | 8 | ? |
| Steel axis (dowel pin) D2 x 16 mm | 8 | ? |
| Plain bushing, 6 mm ID / 8 mm OD (igus GFM-0608-04 type)GFM-0608-04 | 8 | ? |
| Thermoplastic (self-tapping) screw 2.5 x 6 mm | 16 | ? |
| Thermoplastic (self-tapping) screw 2.5 x 8 mm | 30 | ? |
- All upstream prices are in EUR (BOM total €116.89 per hand, €128.28 with the Waveshare board, €142.29 with Arduino + TTLinker; the sheet's own USD conversion uses 1.16). They are kept as notes; no USD prices are set.
- Most vendor links are French Amazon/AliExpress listings (tracking parameters stripped). Alibaba links are the Feetech supplier pages. A Chinese-market BOM is maintained separately by Jianliang Shen (linked in the README).
- Rod lengths are inconsistent inside the assembly guide: page 6 says cut 4 rods at 26-28 mm and 8 rods at 14-16 mm, page 9 lists 2x 18 mm and 1x 25 mm per finger. Cut long, then trim against the length tooling.
- The length tooling needs 2 extra D2x16 axes that stay pressed in; the BOM lists 8 D2x16, exactly the 4 fingers' need. Order 10.
- The BOM sheet's screw rows carry swapped link annotations ('M2.5 x 8' on the 2.5x6 row and vice versa); both point to the same listing.
- Material for the top shell differs: the parts sheet says flexible filament, the printing guide also shows a rigid PLA hand shell (20-40% infill).
- The wrist interface is designed for Pollen's Reachy2 (Orbita 3D wrist). An SO-ARM interface and a desk base are community additions in cad/.
- Upstream disclaimer: real finger angles vary from the CAD, and the hand is not yet validated for long grasping tasks; stalled SCS0009 servos can overheat.
- An 'Amazing Hand Enhanced' revision lives on a separate branch (Amazing-Hand-Enhanced); this package follows main.
- Print hours and filament grams are not published. Assembly time per the Overview is 5-6 hours.
- Ready-made kits exist: Seeed Studio (https://www.seeedstudio.com/Amazing-Hand-Right-Hand-The-Open-Source-Robotic-Hand-Developer-Kit.html) and WowRobo (https://shop.wowrobo.com/products/amazing-hand-the-open-source-robotic-hand-kit).
Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
Bittle / Bittle X →Petoi · quadruped · index 7.5Easiest buildable quadruped, the next class up from hand. Adds gait generation.
NoteAn 'Amazing Hand Enhanced' branch exists. Third-party kits from WowRobo/Seeed. Onshape CAD public. Left and right MJCF models ship in Demo/AHSimulation.
Sources
- [1]AmazingHand repo (licenses, specs)checked 2026-09-24
- [2]Hugging Face blog announcementchecked 2026-09-24
- [3]AmazingHand BOM sheet (EUR totals)checked 2026-09-25