HumanoidPoppy Project (Inria Flowers)FR
Poppy Humanoid
Open-source 3D-printed 25-DOF humanoid (~83-85 cm, 3.5 kg) from Inria Bordeaux's Flowers lab for research, education and art.
Difficulty index
8.7/13| Class | humanoid | +5 |
|---|---|---|
| Cost | $9 BOM | +0 |
| DOF | 25 DOF | +2.5 |
| Parts | 143 parts | +1.2 |
Top of the ladder. This robot lives on the humanoid domains.
Specimen photographs
7 items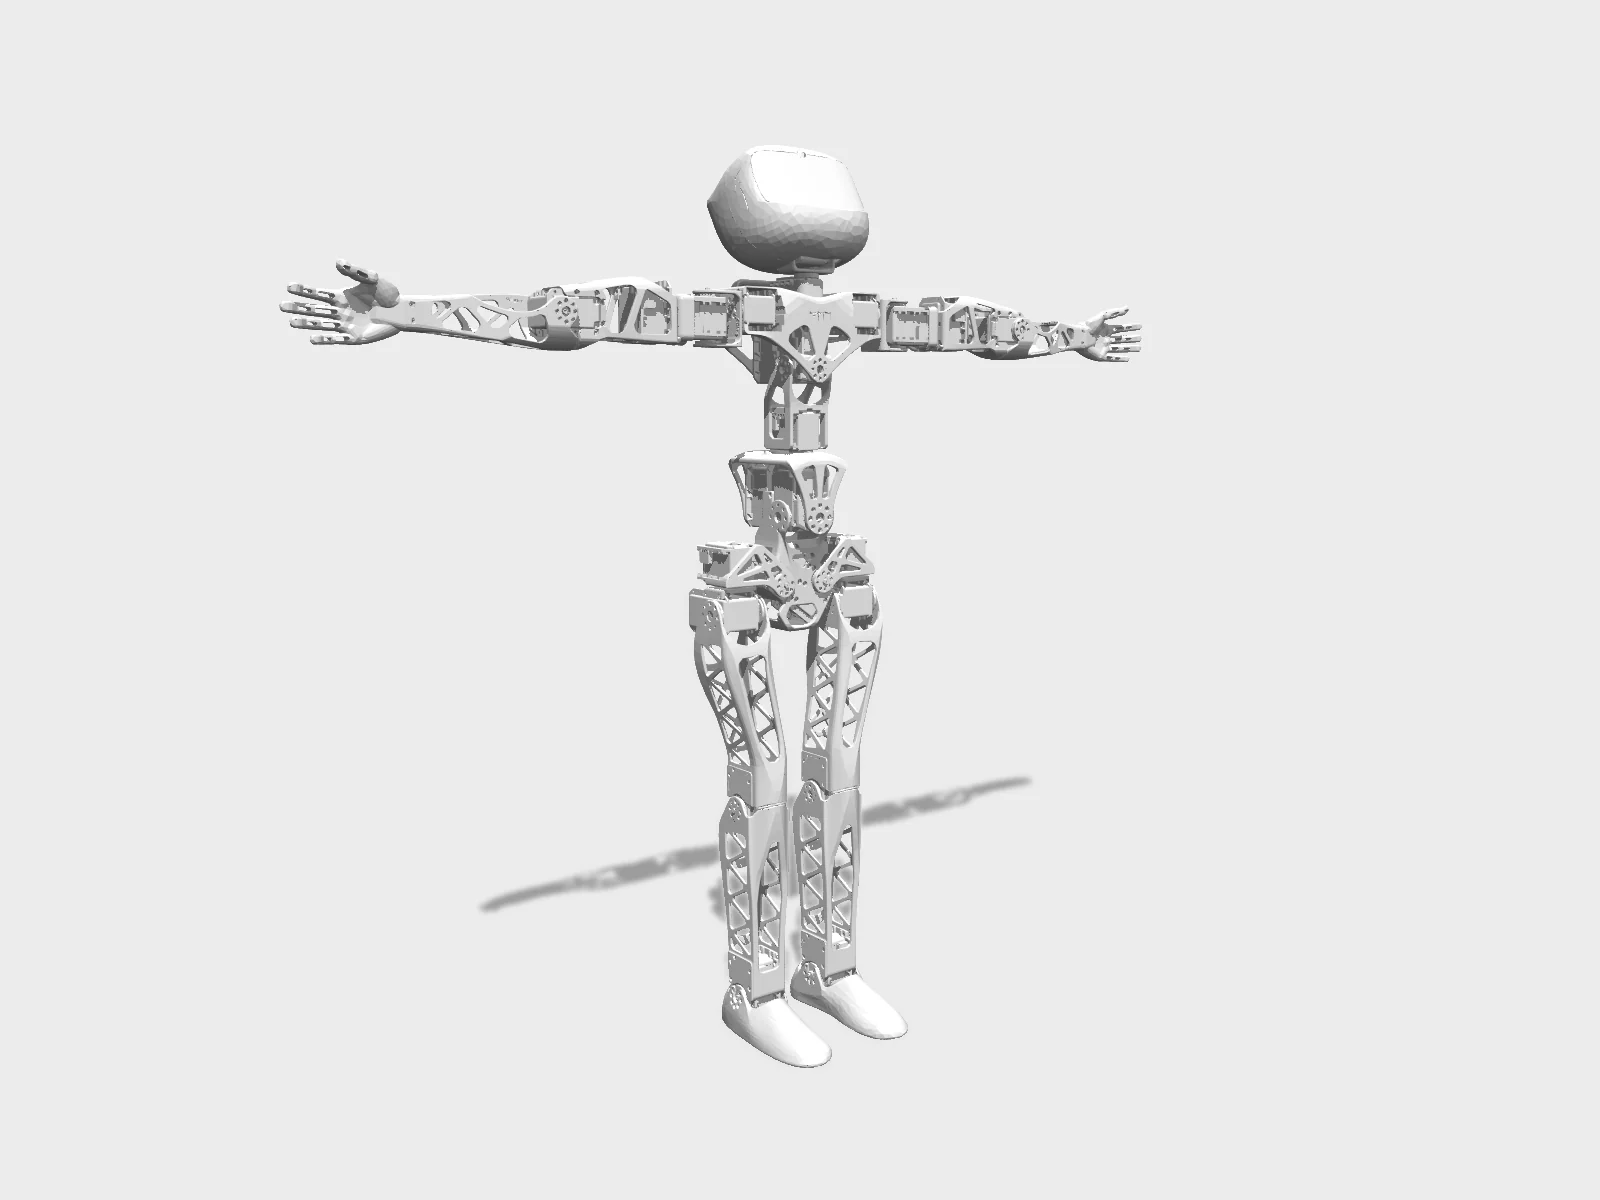
Studio render of the published URDF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from poppy-project/poppy-humanoid (CC-BY-SA-4.0) · Hyperspawn render · source 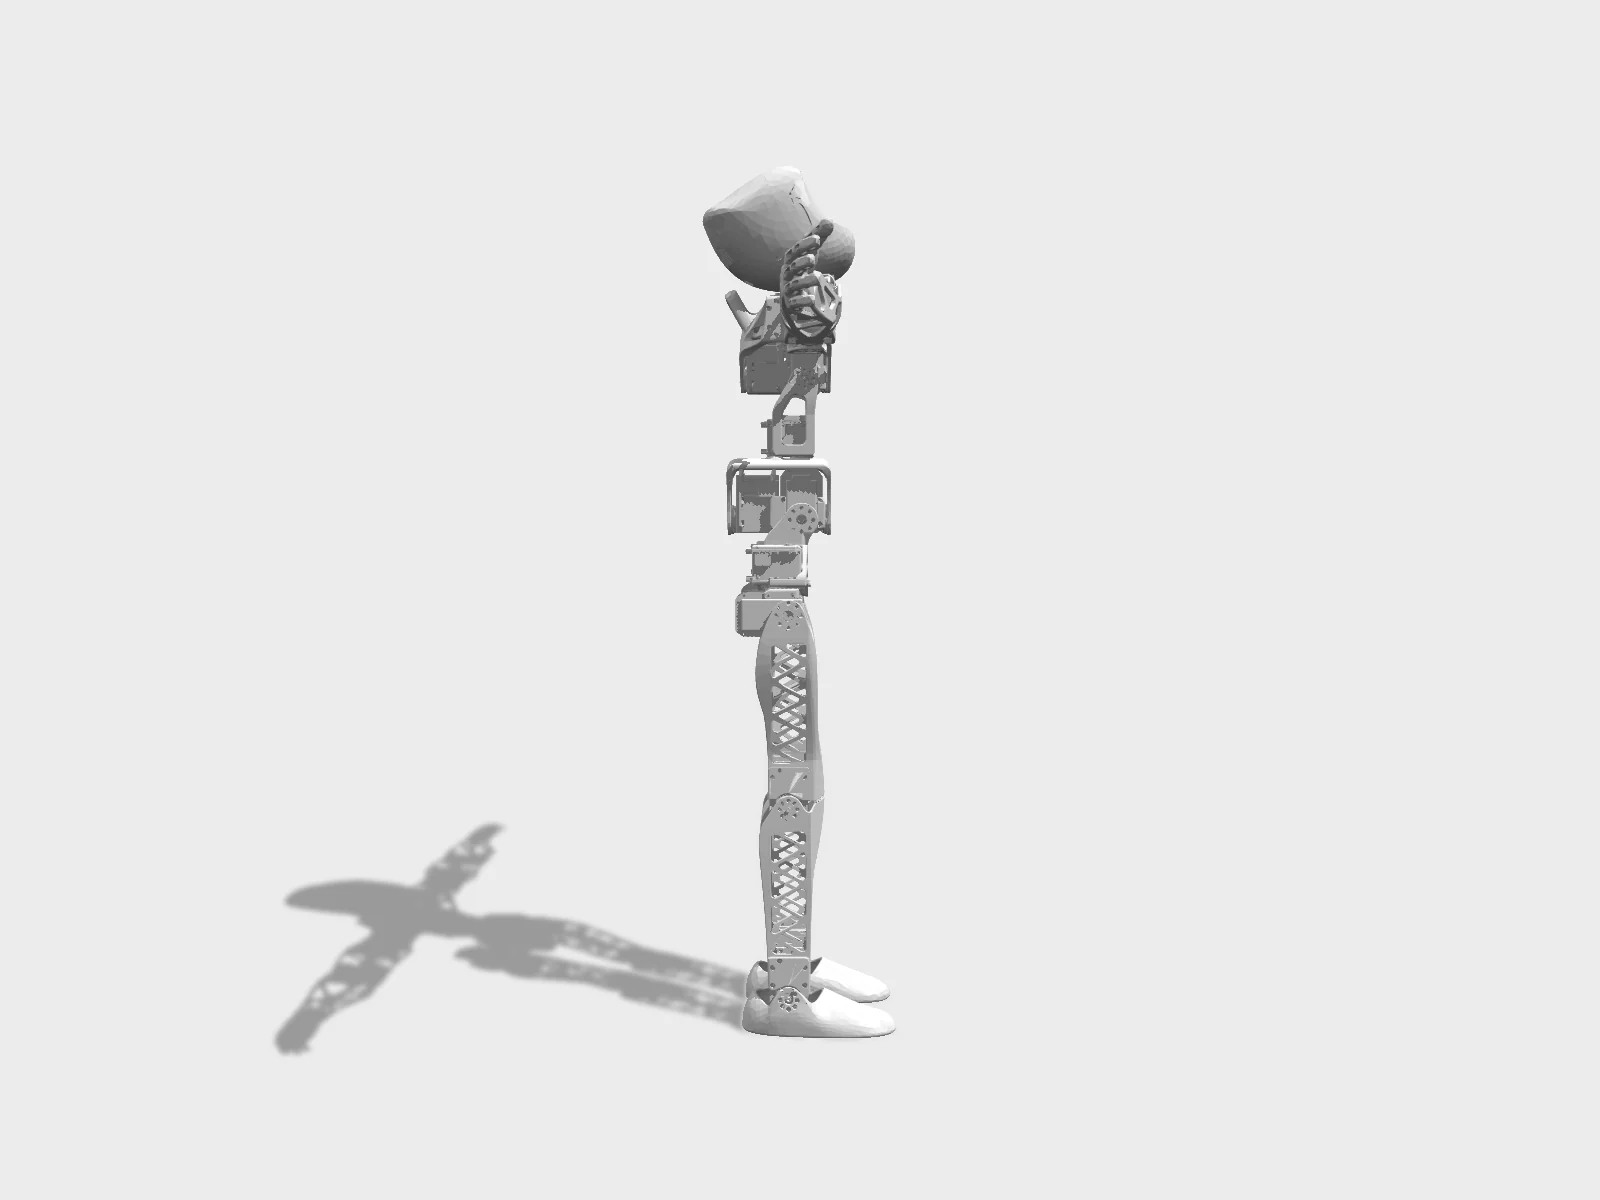
Side view of the same URDF render, the model's zero pose.Rendered by Hyperspawn from poppy-project/poppy-humanoid (CC-BY-SA-4.0) · Hyperspawn render · source 4 s turntable of the URDF studio render.Rendered by Hyperspawn from poppy-project/poppy-humanoid (CC-BY-SA-4.0) · Hyperspawn render · source 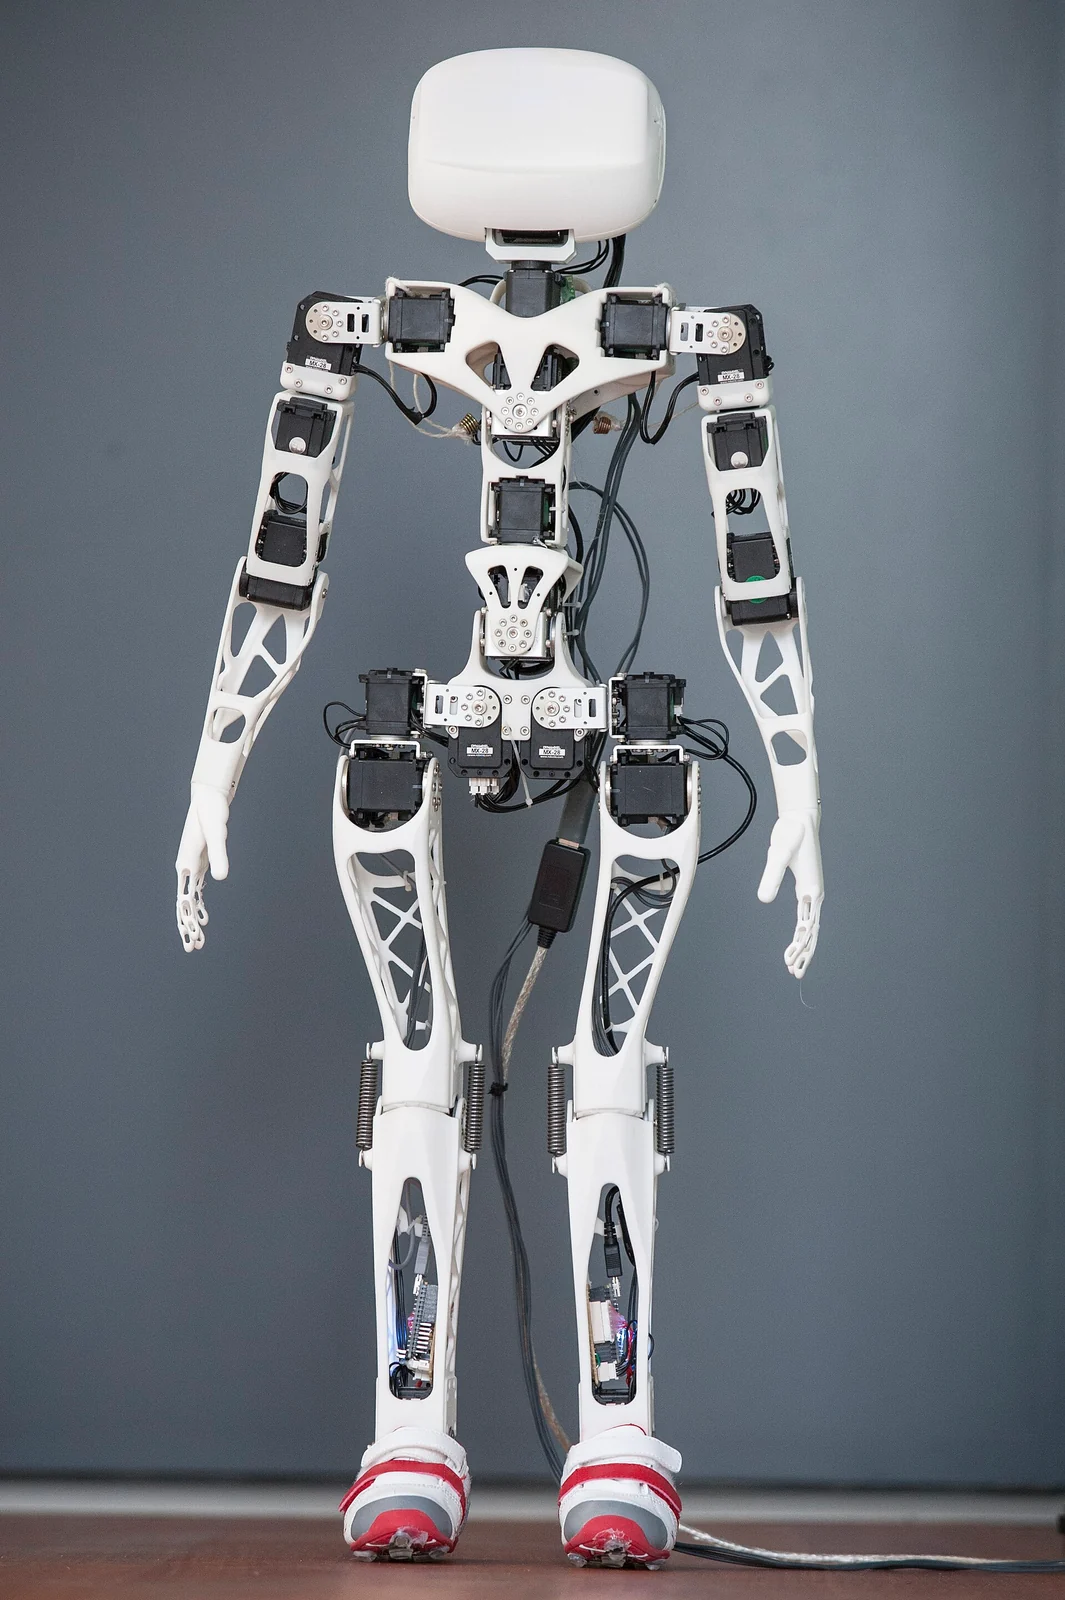
Via Wikimedia Commons (CC BY-SA 4.0).Inria / Poppy-project.org / Photo H. Raguet., via Wikimedia Commons · CC-BY-SA-4.0 · source 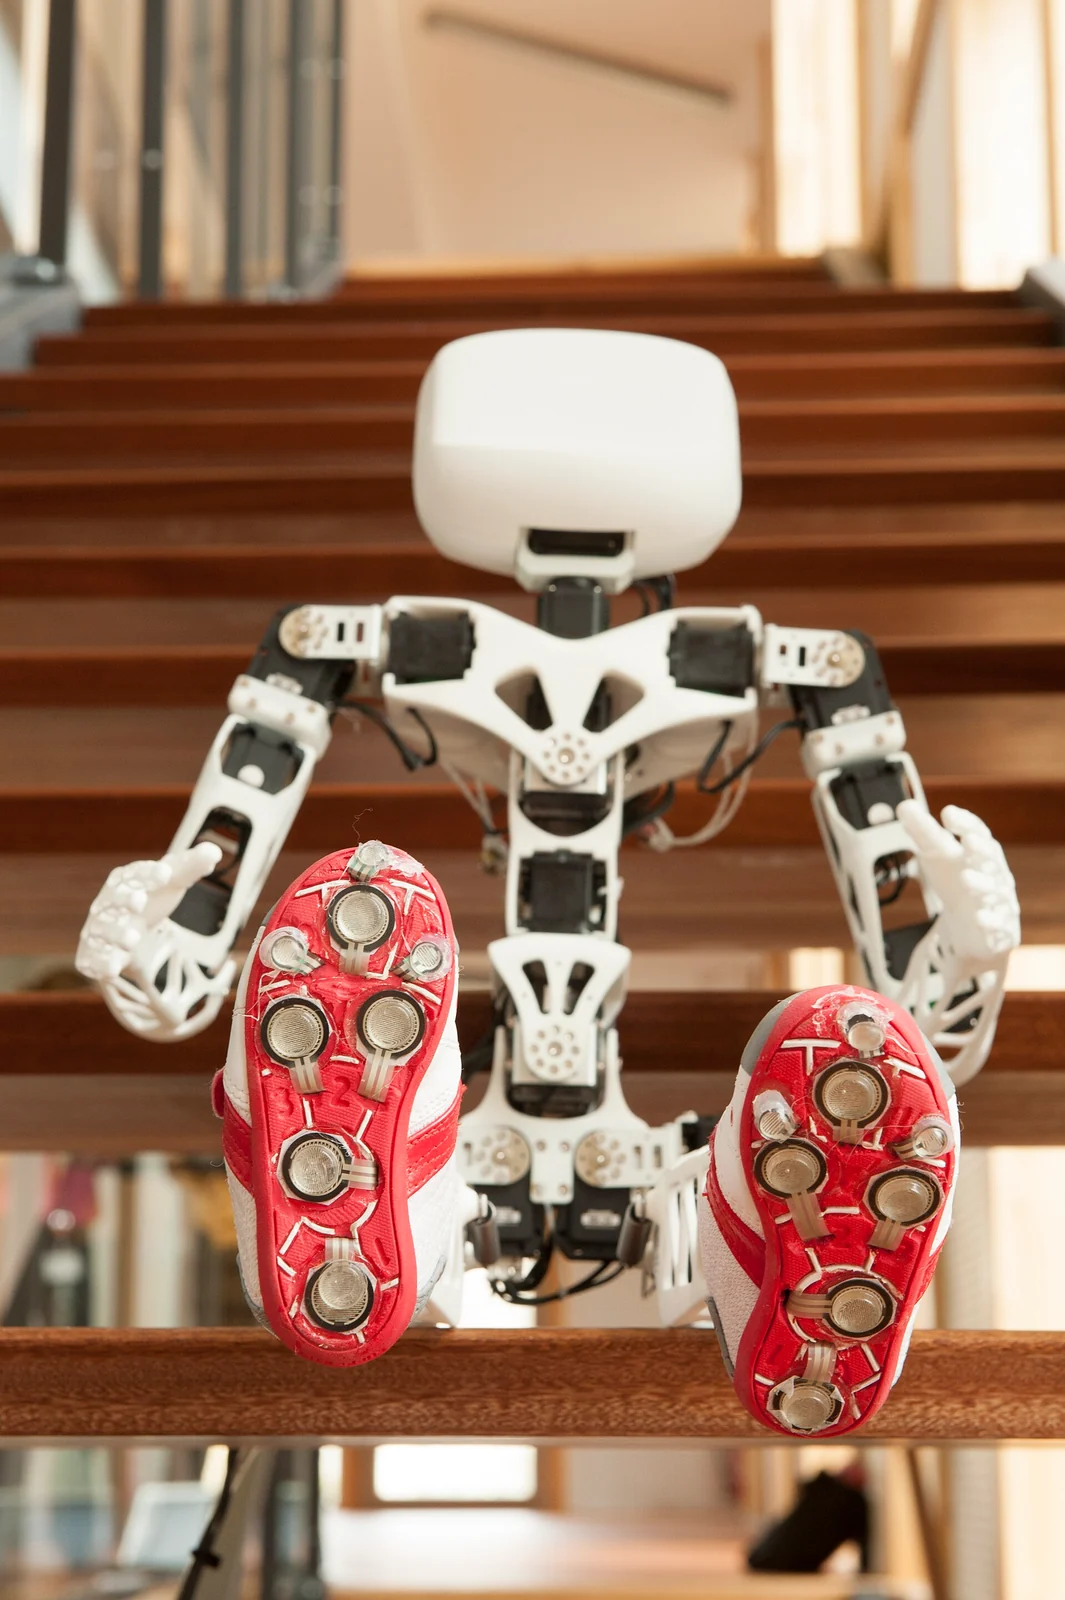
Via Wikimedia Commons (CC BY-SA 4.0).Inria / Poppy-project.org / Photo H. Raguet., via Wikimedia Commons · CC-BY-SA-4.0 · source Poppy Humanoid Beta OverviewPoppy Project · official video, embedded · source Poppy Humanoid first stepsPoppy Project · official video, embedded · source


Spec card
7/13 known- Degrees of freedom
- 25
- Height
- 84 cm
- Mass
- 3.5 kg
- BOM total
- $9 · 1/32 lines priced
- Part count
- 143
- Actuators
- Dynamixel: 19 MX-28AT, 4 MX-64AT, 2 AX-12A
- Compute
- Raspberry Pi (current kit version)
Not in the registry: payload, speed, runtime, battery, price, sensors. Left blank rather than guessed.
What you learn building it
- +Whole-body control
- +Dozens of actuators on one bus
- +Balance and fall handling
- +Safe bring-up of a full-size machine
- +SLS printing (usually a print service): 38 parts
- +Resin (SLA) printing: 1 part
- +Tools used: Computer running Linux, Windows or macOS, pip install poppy-humanoid, Allen keys 1.5 / 2 / 2.5 mm, Tweezers, Flat pliers, Hot glue gun, SD card writer (e.g. Etcher)
- +22 assembly steps across 8 subassemblies
- +Flashing firmware for Raspberry Pi 3/4 (Poppy Humanoid SD image, pypot + poppy-humanoid), Dynamixel MX-28AT / MX-64AT / AX-12A (stock Robotis firmware, configured at 1 Mbps)
- +Testing in simulation (URDF/MJCF) before touching hardware
Openness
- publicCAD
- publicBOM
- publicFirmware
- publicSim model
- publicSoftware
- not publicPolicies
Score 90/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Hardware license: CC-BY-SA-4.0. Software license: GPL-3.0.
Repos & models
Build it
Has an ORP build package.Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
None. This is the top. Find people building it on humanoidrobots.team.
This is the top of the ladder.
NoteProject born 2012 in Inria Flowers lab (Lapeyre PhD); exact public-unveil year not pinned (paper 2014). Main repo last pushed Dec 2021; poppy-project.org failed DNS on fetch (Sep 2026). Lapeyre later co-founded Pollen Robotics. Height quoted as 83 or 85 cm. Actuator mix (19 MX-28AT, 4 MX-64AT, 2 AX-12A) is from the motor configuration file and the archived 1.0 BOM, which agree; the current guide's per-section counts omit the arms. README puts a full build at $8,000-9,000, about 60% of it for the Dynamixels. URDF is in hardware/URDF.
Sources
- [1]Poppy Humanoid motor configuration (motor models)checked 2026-09-25
- [2]Poppy Humanoid URDFchecked 2026-09-25
- [3]Generation Robots: Poppy Humanoid kits (EUR prices)checked 2026-09-25
- [4]Official repochecked 2026-09-24
- [5]Lapeyre et al. 2014 paperchecked 2026-09-24
- [6]New Atlaschecked 2026-09-24