ArmROBOTISKR
OpenMANIPULATOR-X (RM-X52-TNM)
Compact ROS-based 4-DOF arm with a 1-DOF gripper built from Dynamixel XM430 servos, sold as an educational/research manipulator.
Difficulty index
5.0/13| Class | arm | +2 |
|---|---|---|
| Cost | unknown · midpoint | +1.5 |
| DOF | 5 DOF | +0.5 |
| Parts | unknown · midpoint | +1 |
Specimen photographs
5 items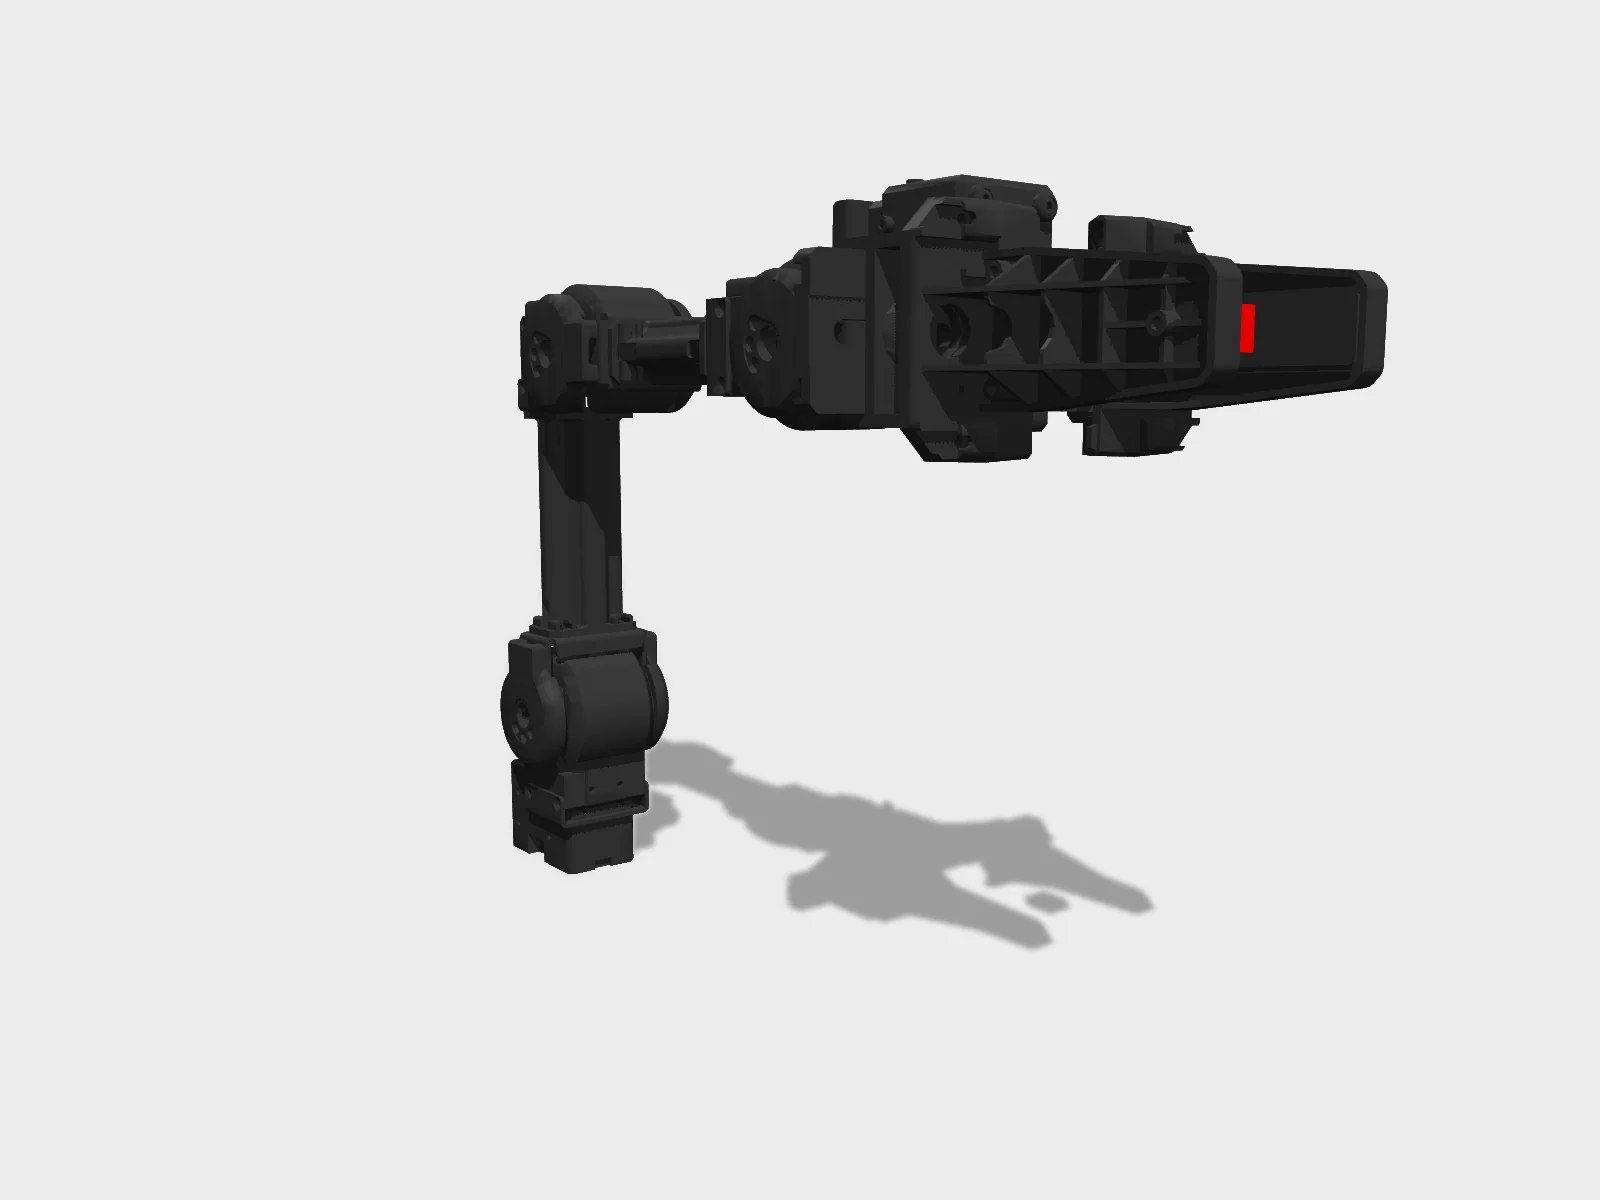
Studio render of the published URDF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from ROBOTIS-GIT/open_manipulator (Apache-2.0) · Hyperspawn render · source 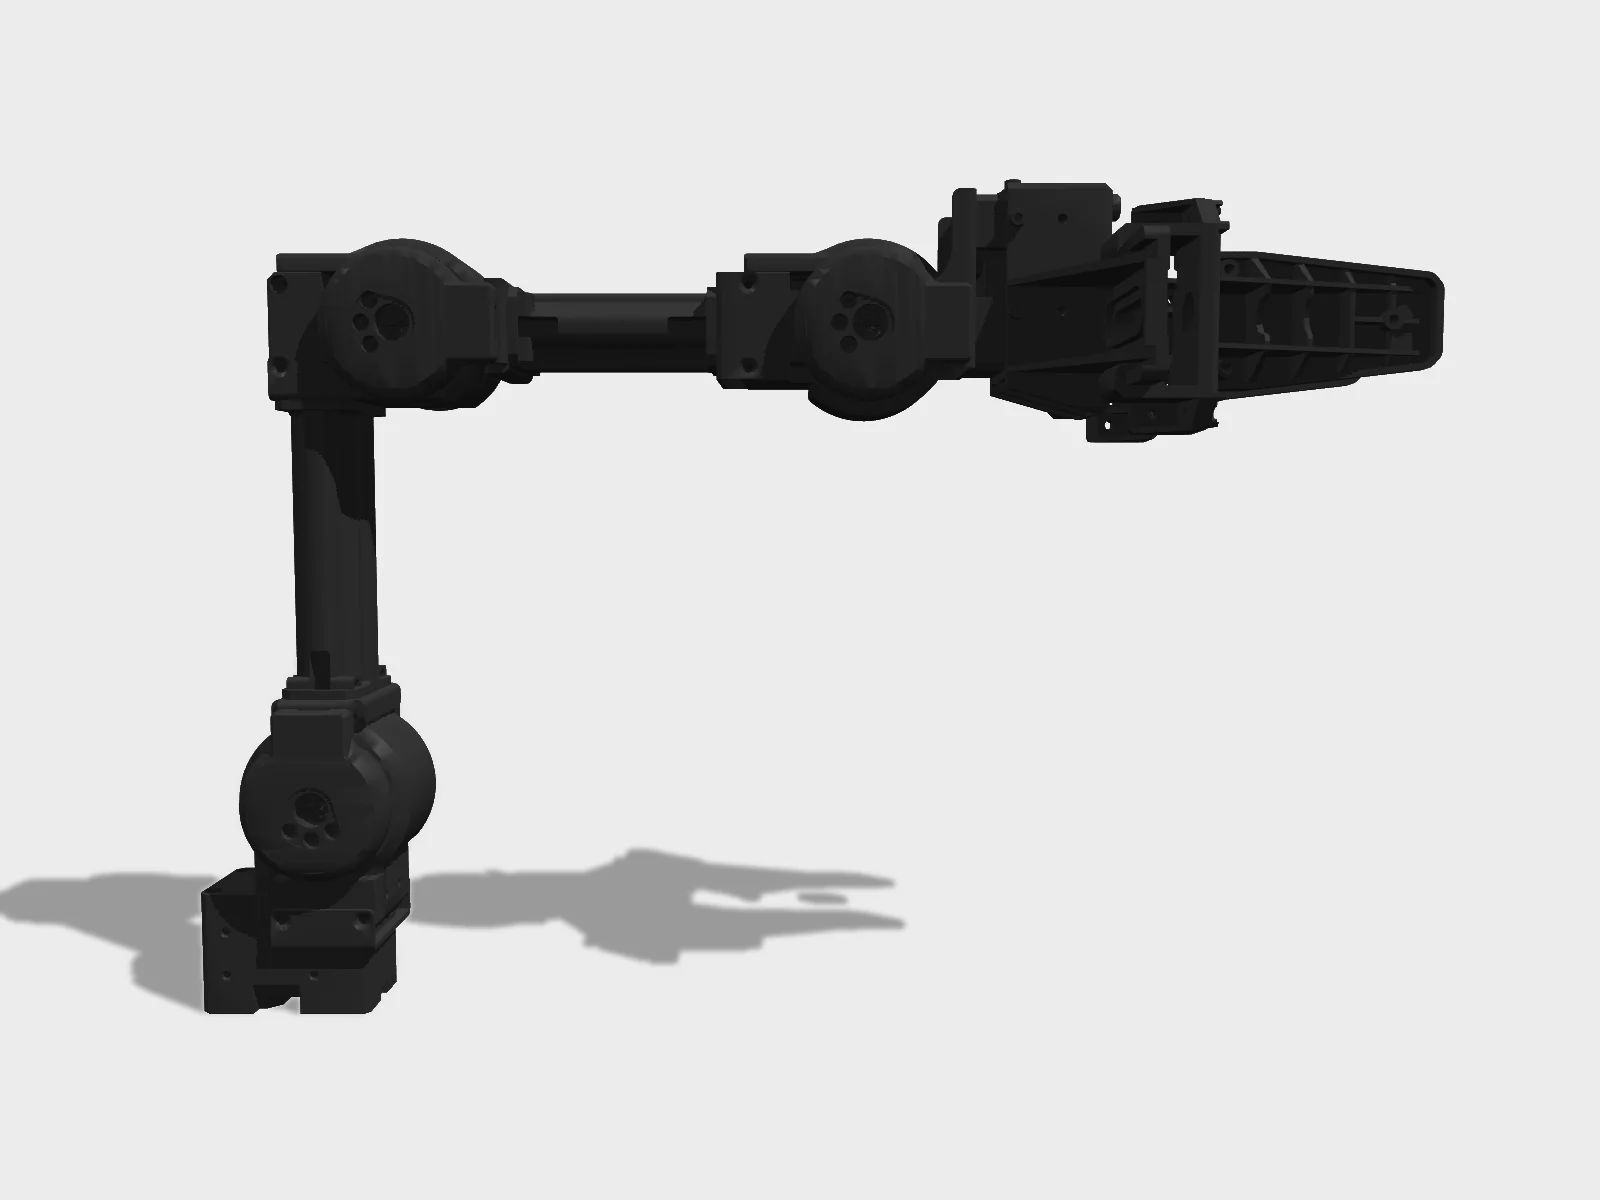
Side view of the same URDF render, the model's zero pose.Rendered by Hyperspawn from ROBOTIS-GIT/open_manipulator (Apache-2.0) · Hyperspawn render · source 4 s turntable of the URDF studio render.Rendered by Hyperspawn from ROBOTIS-GIT/open_manipulator (Apache-2.0) · Hyperspawn render · source OpenManipulator 03 : Assembling the OpenManipulatorROBOTIS OpenSourceTeam · official video, embedded · source OpenManipulator 06 : Manipulation with ROSROBOTIS OpenSourceTeam · official video, embedded · source
Spec card
4/13 known- Degrees of freedom
- 5
- Mass
- 0.7 kg
- Payload
- 0.5 kg
- Actuators
- 5x Dynamixel XM430-W350-T
Not in the registry: height, speed, runtime, battery, price, bom total, part count, compute, sensors. Left blank rather than guessed.
What you learn building it
- +Forward and inverse kinematics
- +Joint calibration and homing
- +Trajectory planning
- +Teleoperation and collecting demonstrations for learning
- +Testing in simulation (URDF/MJCF) before touching hardware
Openness
- not publicCAD
- not publicBOM
- not publicFirmware
- publicSim model
- publicSoftware
- not publicPolicies
Score 30/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Software license: Apache-2.0.
Repos & models
Build it
No public build path.No ORP build package yet.
That means no BOM with prices, no fabrication list and no step graph in the registry. Build from the upstream material, or write the package: a robot.toml plus BOM and steps.
Package spec on buildhumanoids.devSimulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
Aero Hand Open →Chestnut Robotics (formerly TetherIA) · hand · index 5.5Easiest buildable hand, the next class up from arm. Adds tendon and linkage transmissions.
NoteROBOTIS' newer OMX (OMX-F follower / OMX-L leader) targets LeRobot-style imitation learning and lives in the same repo. CAD/BOM openness not verified, so marked false.
Sources
- [1]ROBOTIS US product pagechecked 2026-09-24
- [2]ROBOTIS e-Manualchecked 2026-09-24
- [3]open_manipulator repochecked 2026-09-24
- [4]ROBOTIS OMXchecked 2026-09-24