ArmSource RoboticsHR
PAROL6
3D-printed 6-axis desktop robot arm with industrial-style mechanics, with open-source STL files, BOM, control software and GUI.
Difficulty index
5.7/13| Class | arm | +2 |
|---|---|---|
| Cost | unknown · midpoint | +1.5 |
| DOF | 6 DOF | +0.6 |
| Parts | 417 parts | +1.6 |
Specimen photographs
6 items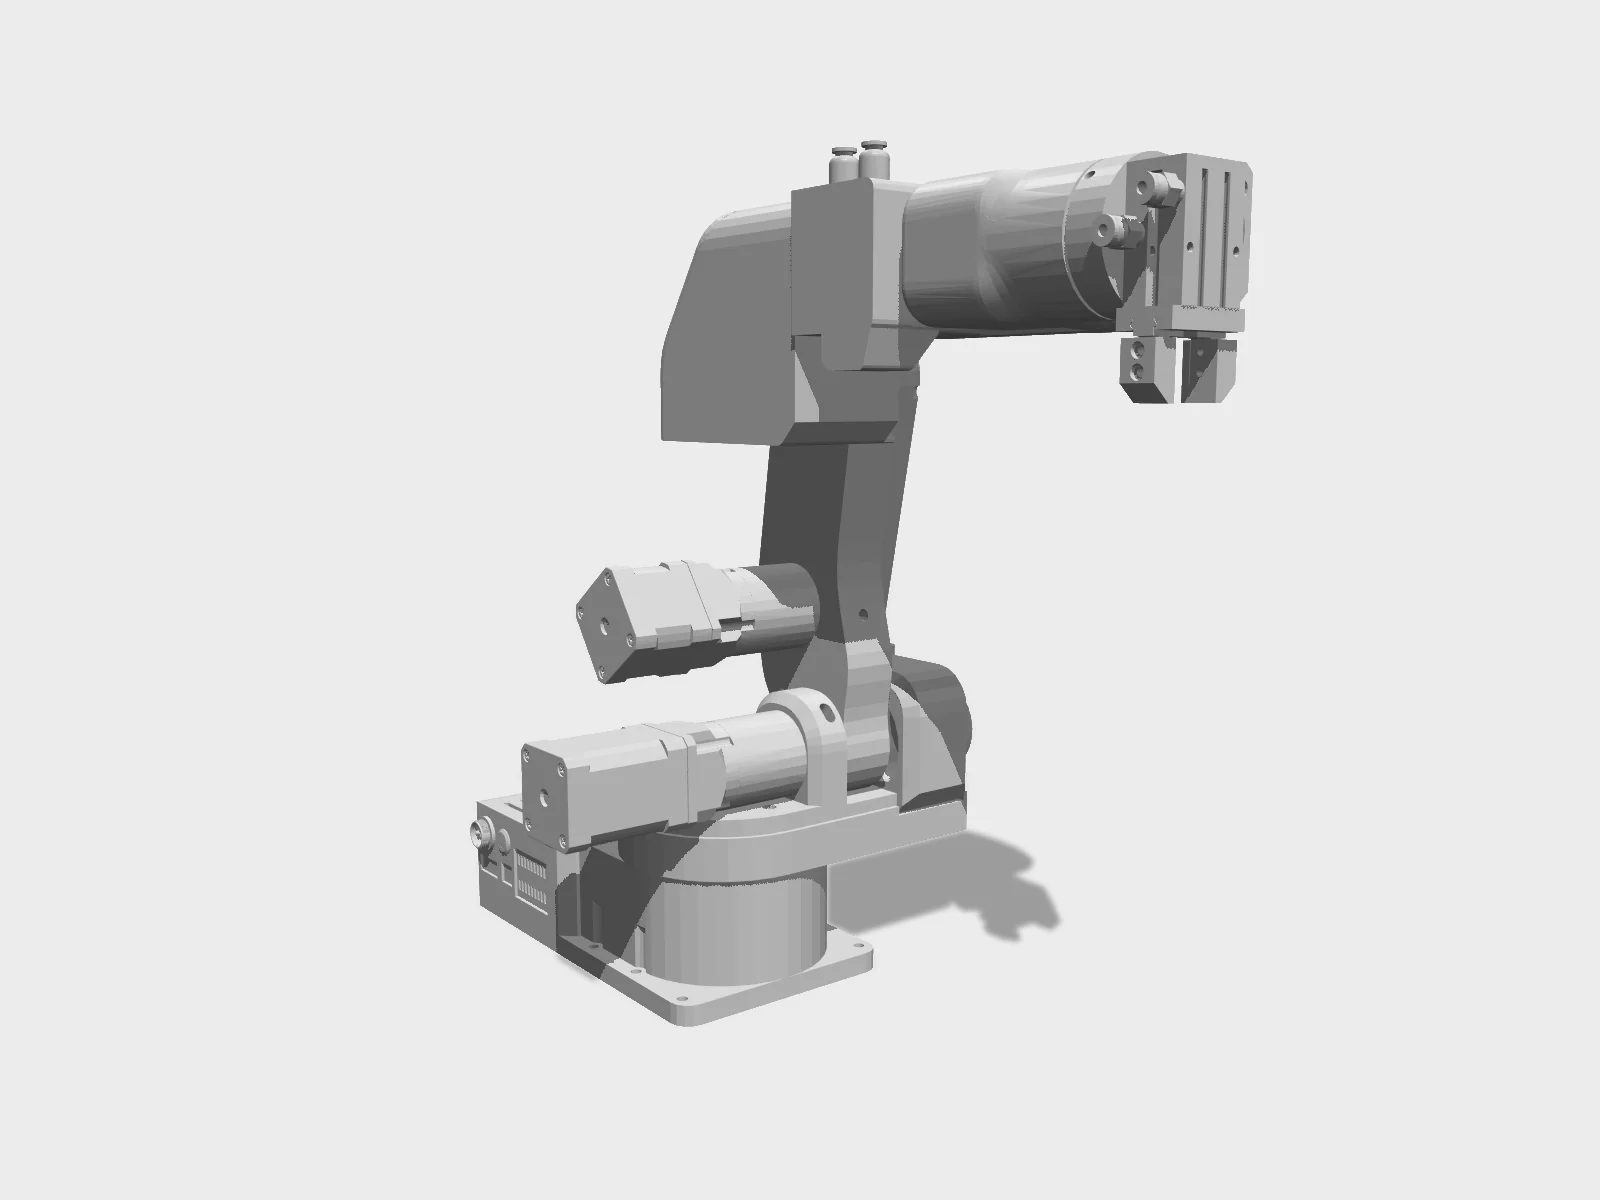
Studio render of the published URDF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from Source-Robotics/PAROL6-Desktop-robot-arm (GPL-3.0) · Hyperspawn render · source 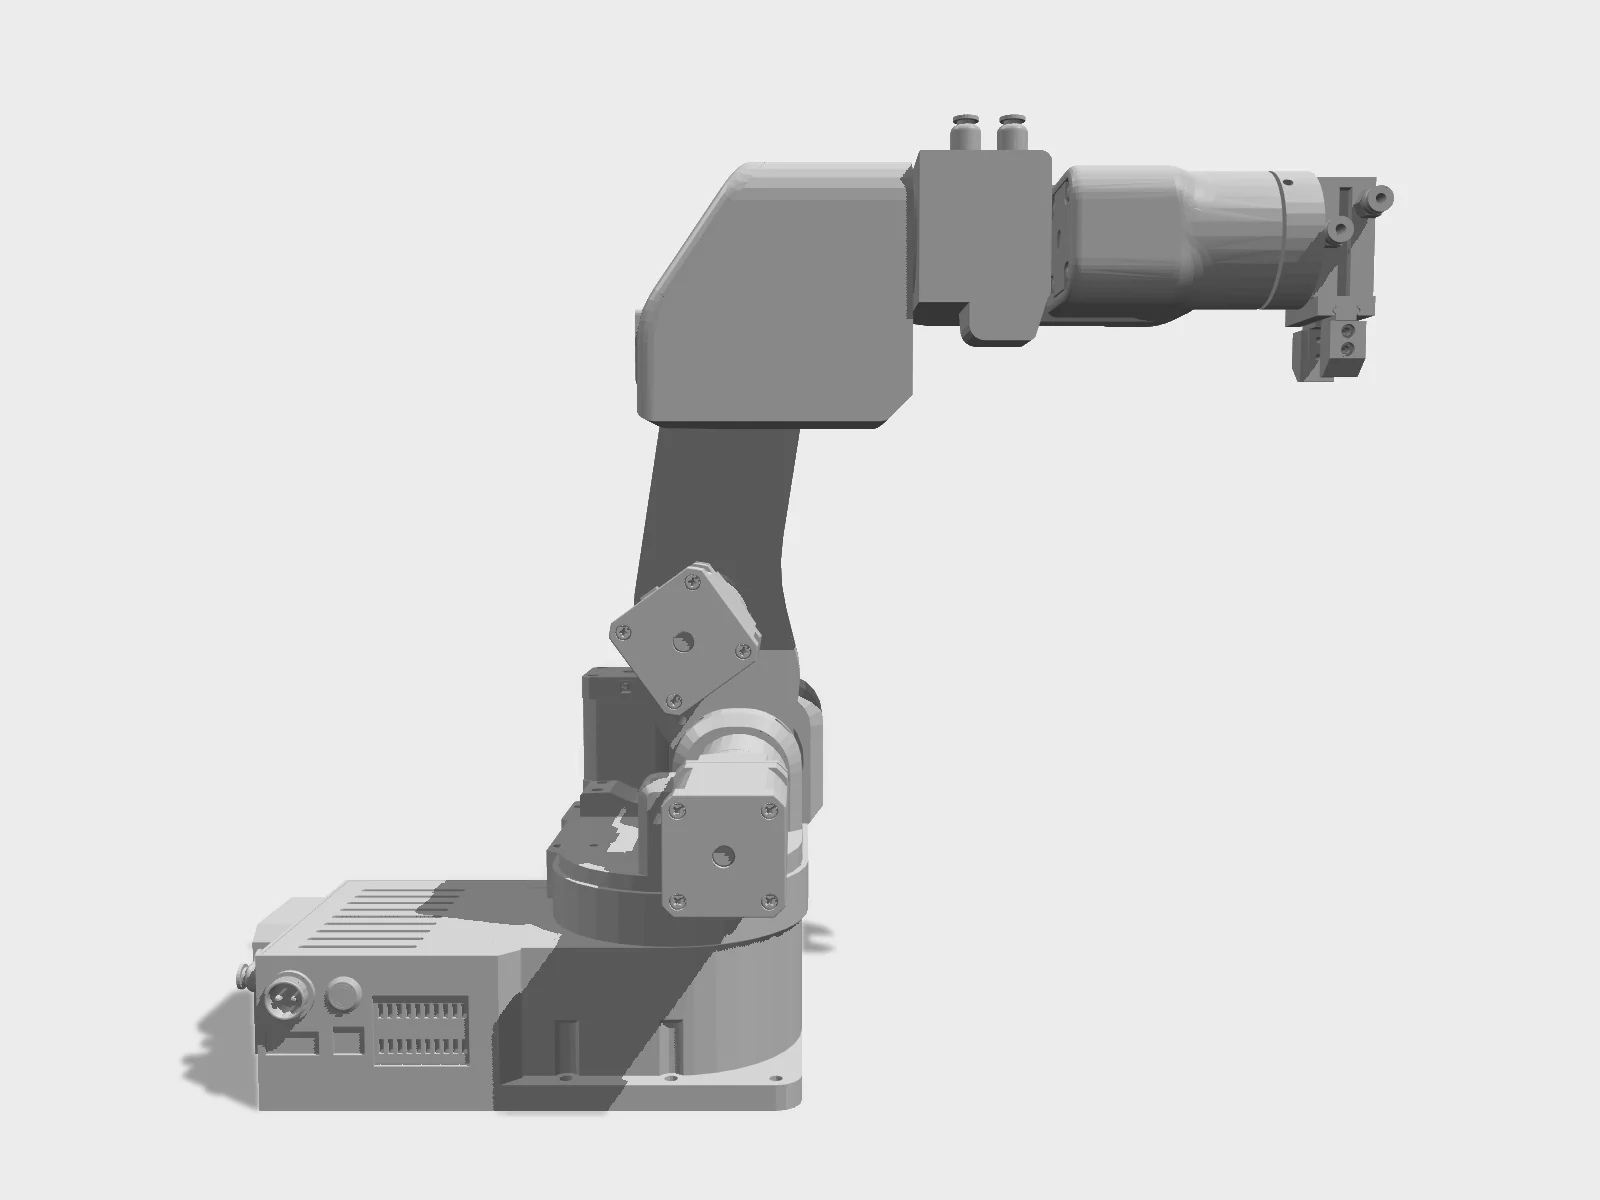
Side view of the same URDF render, the model's zero pose.Rendered by Hyperspawn from Source-Robotics/PAROL6-Desktop-robot-arm (GPL-3.0) · Hyperspawn render · source 4 s turntable of the URDF studio render.Rendered by Hyperspawn from Source-Robotics/PAROL6-Desktop-robot-arm (GPL-3.0) · Hyperspawn render · source 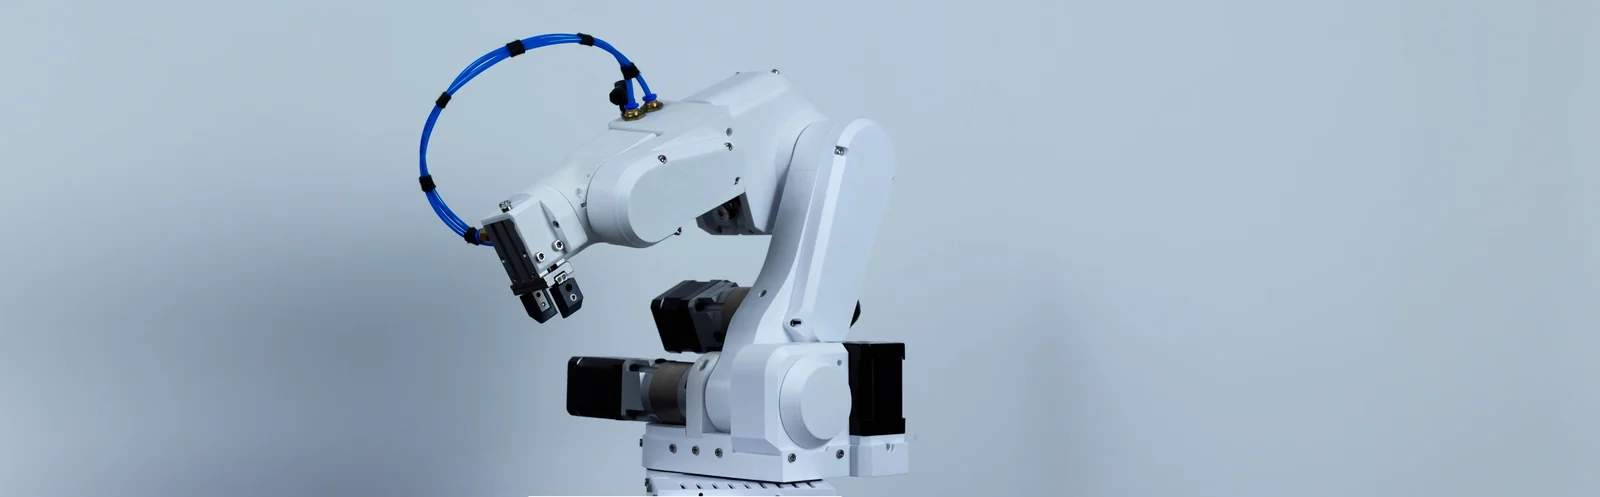
From the PAROL6 README.Source Robotics (PAROL6-Desktop-robot-arm) · GPL-3.0 · source PAROL6 - 3D printed desktop robot arm - PresentationSource Robotics · official video, embedded · source PAROL6 v1 - 3D printed 6 axis robot arm - 1 year overviewSource Robotics · official video, embedded · source

Spec card
3/13 known- Degrees of freedom
- 6
- Mass
- 5.5 kg
- Part count
- 417
Not in the registry: height, payload, speed, runtime, battery, price, bom total, actuators, compute, sensors. Left blank rather than guessed.
What you learn building it
- +Forward and inverse kinematics
- +Joint calibration and homing
- +Trajectory planning
- +Teleoperation and collecting demonstrations for learning
- +FDM 3D printing: 41 parts, about 95 h of printing
- +Tools used: FDM printer, about 175 mm bed for Upper_arm and J1 turret (or use the SMALL_PRINT_BED split parts), Reamers per the small print bed PDF, Clamps, Soldering iron, Heat gun, Hex key set, Torque screwdriver, Rubber hammer +14
- +25 assembly steps across 7 subassemblies
- +Flashing firmware for STM32F446RE (PAROL6 control board, PlatformIO env genericSTM32F446RE, ST-Link upload), 6x TMC5160 over SPI (configured by the main firmware)
- +Testing in simulation (URDF/MJCF) before touching hardware
Openness
- publicCAD
- publicBOM
- publicFirmware
- publicSim model
- publicSoftware
- not publicPolicies
Score 90/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Hardware license: GPL-3.0. Software license: GPL-3.0.
Repos & models
Build it
Has an ORP build package.- BOM total
- unpriced
- Lines priced
- 0/63
- Parts
- 417
- Steps
- 25
- Version
- 0.1.0
63 lines have no price yet, so the real total is higher.
Largest BOM lines
| Part | Qty | Unit |
|---|---|---|
| Stepper 1: NEMA 17, 16 Ncm, 42x42x20 mm, 1 A (J6 wrist)17HS08-1004S | 1 | ? |
| Stepper 2: NEMA 17, 45 Ncm, 42x42x40 mm, 2 A (J3, J4, J5)17HS16-2004S1 | 3 | ? |
| Stepper 3: NEMA 17, 65 Ncm, 42x42x60 mm, 2.1 A (J1, J2)17HS24-2104S | 2 | ? |
| EG-series precision planetary gearbox 20:1 for NEMA 17 (J2, J3)EG17-G20 | 2 | ? |
| EG-series precision planetary gearbox 10:1 for NEMA 17 (J6)EG17-G10 | 1 | ? |
| HTD 3M belt, 396 mm, 6 mm wide (J1) | 1 | ? |
| HTD 3M belt, 342 mm, 6 mm wide (J3) | 1 | ? |
| HTD 3M belt, 201 mm, 6 mm wide (J4) | 1 | ? |
- Upstream pins: Source-Robotics/PAROL6-Desktop-robot-arm@3892e9c85c1f6d8041cda01c47c9db9d18b30ad8 (2026-09-07; BOM/BOM.md, STL/, Print table/PR_EXCEL.xlsx, assembly manual v1.2 rev1 dated 27.10.2023, control board main + test firmware); Source-Robotics/PAROL-docs@6a30a7fadc73e6e270e8e86f3afb96d55346af69 (2026-03-13, published at source-robotics.github.io/PAROL-docs as of 2026-09-25); PAROL-commander-software@65c844fd5e0e5ec20c30352092ac4fb29b997bd5 (2025-09-23)
- No USD prices anywhere upstream. BOM.md gives links only (many are AliExpress affiliate short links), and the control board and programming adapter are priced in EUR on source-robotics.com.
- The PAROL6 control board is only sold by Source Robotics. The manual states the STEP files and the control board are not open source; STL files, BOM, firmware and Commander are GPL-3.0.
- The BOM supply (Mean Well EDR-120-24) is an open-terminal mains DIN-rail unit. It needs an enclosure, earth and qualified wiring. The kit is sold without printed parts or a PSU.
- The print table (PR_EXCEL.xlsx) predates some STL renames: several files (J1_turret_rework_blocker, J1_belt_cover_rework, main_base_blocker, lid_electronics) are matched to older row names, some parts have two conflicting rows, and E-stop, gripper jaws and J1_wires_cover have no row at all.
- The assembly manual is v1.2 rev1 (27.10.2023) and some images are outdated (the J5 stepper orientation is shown 180° wrong; J1 turret stopper rails were added later).
- TMC5160 modules from other sellers must match the docs pinout and have the DIAG pins removed. A reversed or wrong driver, or an ST-Link connected without the adapter, destroys the board.
- No brakes: the arm falls when power is cut. For long runs the docs require lowering motor currents in constants.h to keep PETG parts cool (J4-J6 reach 72-73 °C when moving).
- The manual calls for an M3x20 screw as the J1 rotation limiter and 'M3 ?' in one optional shoulder step, but BOM.md has no M3x20 line. Buy a few extra M3 lengths.
- Open-loop steppers with homing switches. Position is lost on a stall until the next homing.
- No trained policies or datasets were found on Hugging Face for PAROL6 (search 2026-09-25).
Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
Aero Hand Open →Chestnut Robotics (formerly TetherIA) · hand · index 5.5Easiest buildable hand, the next class up from arm. Adds tendon and linkage transmissions.
NoteRepo moved from PCrnjak (Petar Crnjak) to the Source-Robotics org. Maker reports >250 units in use worldwide. URDF (ROS package with Gazebo launch) is in PAROL6_URDF/. STL files, BOM, firmware and PAROL Commander are GPL-3.0; per the assembly manual the STEP files and the PAROL6 control board are not open source, and the board is only sold by Source Robotics. No trained policies or datasets found on Hugging Face (2026-09-25).
Sources
- [1]PAROL docschecked 2026-09-25
- [2]PAROL6 assembly manual v1.2 (STEP files and control board not open source)checked 2026-09-25
- [3]PAROL Commander software (GPL-3.0)checked 2026-09-25
- [4]Source Robotics contact info (Zagreb address)checked 2026-09-24
- [5]GitHub repo (GPL-3.0)checked 2026-09-24
- [6]Source Robotics sitechecked 2026-09-24
- [7]Hackaday.io projectchecked 2026-09-24