QuadrupedStanford Student Robotics / Hands-On Robotics2024US
Pupper v3
Open-source educational quadruped developed through Stanford courses, with brushless motors, a Raspberry Pi 5 and a reinforcement-learning locomotion policy out of the box.
Difficulty index
7.6/13| Class | quadruped | +3.5 |
|---|---|---|
| Cost | $2,043 BOM | +1.3 |
| DOF | 12 DOF | +1.2 |
| Parts | 443 parts | +1.6 |
Specimen photographs
4 items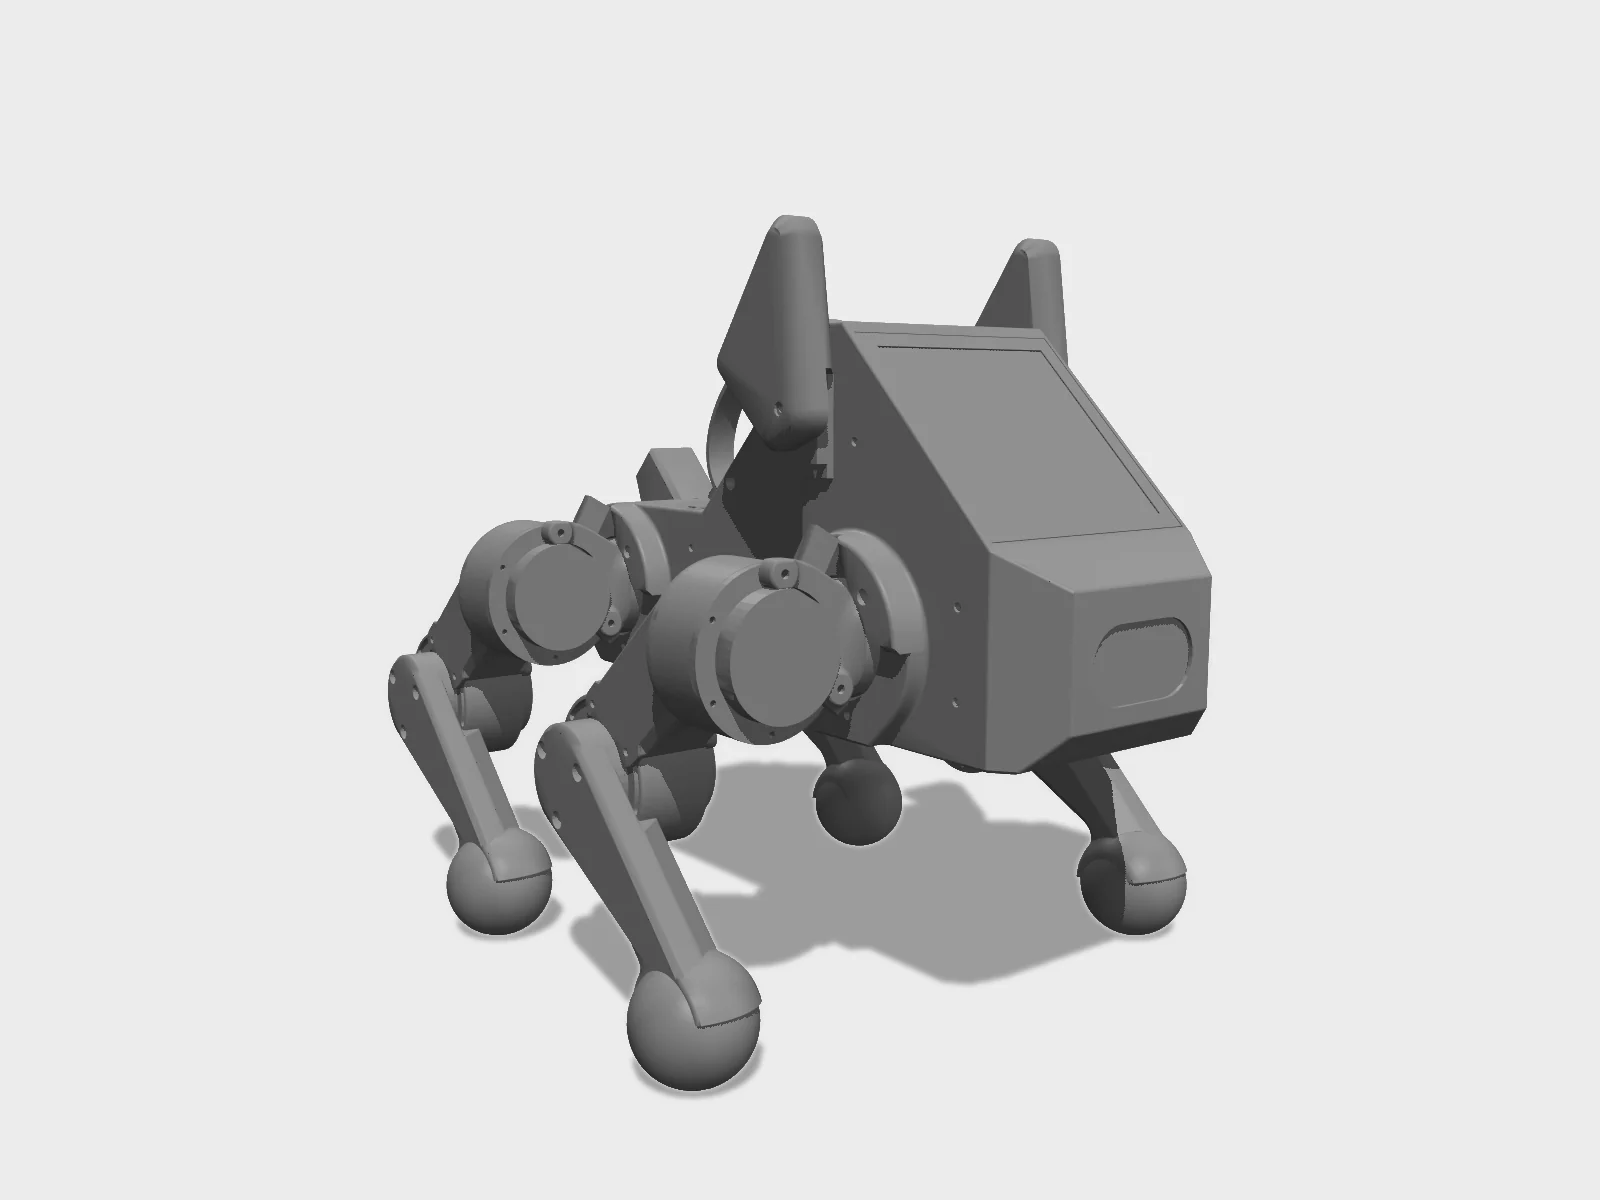
Studio render of the published MJCF, keyframe pose from the model. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from G-Levine/pupper_v3_description (MIT) · Hyperspawn render · source 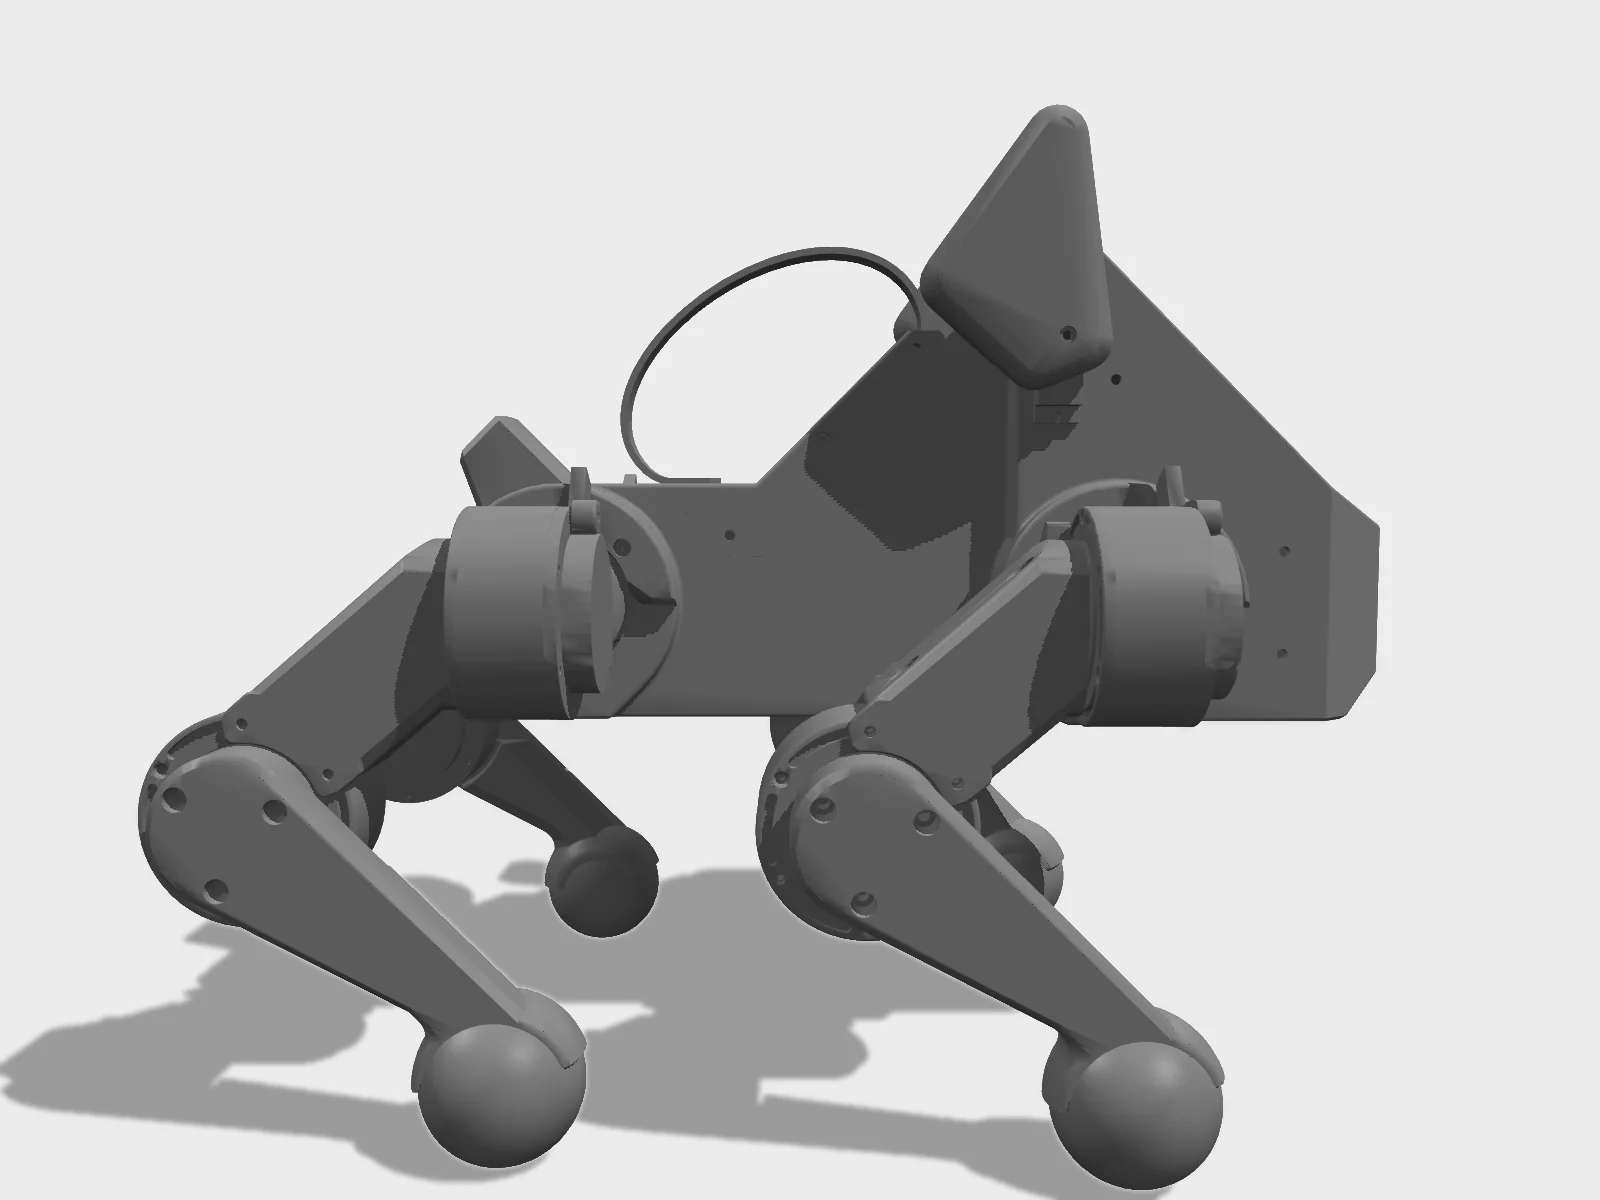
Side view of the same MJCF render, keyframe pose from the model.Rendered by Hyperspawn from G-Levine/pupper_v3_description (MIT) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from G-Levine/pupper_v3_description (MIT) · Hyperspawn render · source 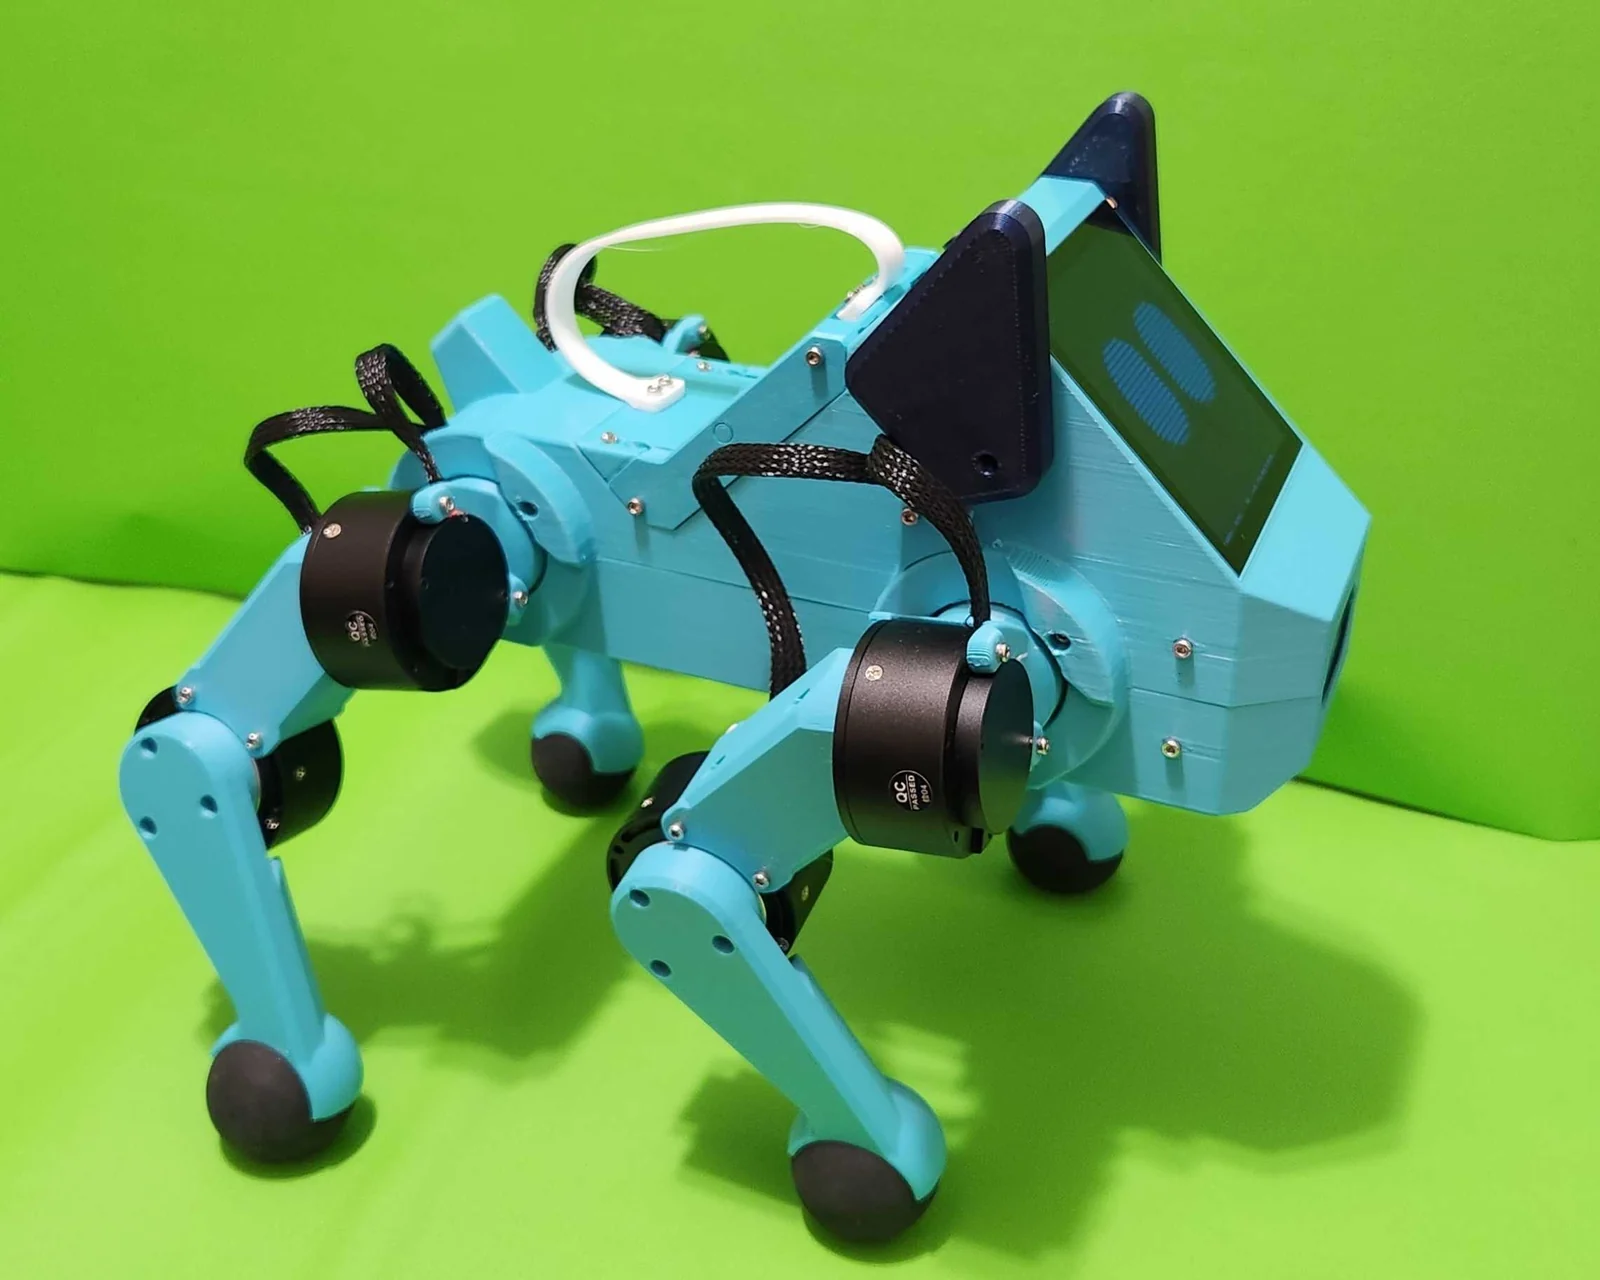
From the pupper-v3 documentation.Hands-On Robotics (pupper-v3-documentation) · AGPL-3.0 · source

Spec card
7/13 known- Degrees of freedom
- 12
- Mass
- 3 kg
- BOM total
- $2,043 · 27/33 lines priced
- Part count
- 443
- Actuators
- GIM4305 400 W brushless motors
- Compute
- Raspberry Pi 5
- Sensors
- Luxonis SR depth camera
Not in the registry: height, payload, speed, runtime, battery, price. Left blank rather than guessed.
What you learn building it
- +Gait generation
- +State estimation from an IMU
- +Sim-to-real policy transfer
- +High-current power and motor drivers
- +FDM 3D printing: 29 parts
- +Laser cutting: 1 part
- +Tools used: ST-Link V2, JST SH kit to make a 7-pin cable, STM32CubeProgrammer, 3/4-pin JST SH cable, CP2102 USB-UART adapter (must be CP2102), Windows PC with Steadywin Motor Wizard, FDM printer with a 0.6 mm nozzle, Soldering iron at 250 °C +8
- +21 assembly steps across 9 subassemblies
- +Flashing firmware for Control board Rev 3.5, two STM32 MCUs: SPIneV1.elf via ST-Link V2 / STM32CubeProgrammer, 12 x Steadywin GIM4305 SHS drivers: vendor firmware .elf via ST-Link, parameters and CAN ID via Steadywin Motor Wizard over CP2102 UART, Raspberry Pi 5: pupOS image (PiOS + ROS 2 Jazzy + pupperv3-monorepo)
- +Testing in simulation (URDF/MJCF) before touching hardware
- +Running published learned policies
Openness
- publicCAD
- publicBOM
- publicFirmware
- publicSim model
- publicSoftware
- publicPolicies
Score 100/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Software license: AGPL-3.0 AND GPL-3.0 AND MIT.
Repos & models
Build it
Has an ORP build package.- BOM total
- $2,043
- Lines priced
- 27/33
- Parts
- 443
- Steps
- 21
- Version
- 0.1.0
6 lines have no price yet, so the real total is higher.
Largest BOM lines
| Part | Qty | Unit |
|---|---|---|
| Steadywin GIM4305 with SHS driver (select the 'Pupper v3 version' so drivers come pre-flashed)GIM4305 | 12 | $110 |
| DeWalt 20 V POWERSTACK battery 1.7 Ah | 2 | $50 |
| Raspberry Pi 5, 8 GBSC1112 | 1 | $80 |
| Waveshare 4 x 4 in HDMI Raspberry Pi screen (face display; ships with the HDMI to micro HDMI adapter) | 1 | $75.99 |
| PS5 wireless controller | 1 | $75 |
| [Optional] Raspberry Pi AI Kit (Hailo-8L); the build slides install it | 1 | $70 |
| [Optional] Arducam IMX296 global shutter cameraIMX296 | 1 | $62 |
| Pi hat control board Rev 3.5 (custom PCBA, needs a BNO086 IMU; firmware SPIneV1) | 1 | $60 |
- Upstream pins: HandsOnRobotics/pupper-v3-documentation@c25c91d54f09a1ed202b9cd9a3b13b33f09c0df2 (2025-10-20), readthedocs latest as of 2026-09-25; Google Sheets BOM tab 'v3.5' exported 2026-09-25; Google Slides 'Pupper Build Instructions' and motor flashing Google Doc exported 2026-09-25; Nate711/pupperv3-monorepo@6f96c5e79faa05492992c19918f8cd90b9243281 (2026-07-25); Nate711/pupperv3-mjx@684932a451819584847b10e5c9aec546443a9462 (2025-10-17); G-Levine/pupper_v3_description@1a3c8590189d3a406219d155f4177afc491a7d77 (2024-11-08)
- BOM totals (v3.5 tab): $2,158.91 all lines, $1,785.91 'min cost'. The docs index says about $2,000; the StanfordQuadruped README says roughly $1,000 BOM (older figure). The 12 motors are $1,320 of that.
- USD figures are the BOM's approximate line totals; per-unit prices here are those totals divided by quantity (motors: 12 x $105 + $60). Cable and sleeving lines have no price.
- Several items the build slides install as standard are marked [Optional] in the BOM (AI kit, M.2 adapter, camera, lens, speaker, ear servos, microphone).
- The motor driver firmware, control board firmware (SPIneV1.elf), Motor Wizard and pupOS image are Google Drive downloads with no source repo; build instructions and the motor flashing guide are Google Slides/Docs, so they can change without version history visible here.
- Custom PCBs need a JLCPCB PCBA order with the BNO086 global-sourced; the docs call this 'a little tricky'. Motors bought as the AIFitLab 'Pupper v3 version' skip the driver flashing.
- Kits: Present Perfection (US, run by the project's kit builder) and AIFitLab (China, unaffiliated) per the docs; neither is a BOM line here.
- The DeWalt pack has no low-voltage cutoff on the robot; the docs say not to run longer than 40 minutes. Motors get hot after long runs.
- The build slides contain a 'TODO COME BACK TO THIS' note at the screen pogo-pin step, and a few screw callouts differ (e.g. M2.5x8 text vs M2.5x10 label on the abduction bracket).
- Licenses: pupper-v3-documentation AGPL-3.0; pupperv3-monorepo and pupperv3-mjx GPL-3.0; pupper_v3_description MIT. CAD is a public Onshape/Fusion share with no stated licence.
- Default password in the docs is `rhea123`; change it.
Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
Z-Bot (Zeroth Bot) →K-Scale Labs · humanoid · index 8.4No buildable class sits between quadrupeds and humanoids yet, so the next rung is the easiest humanoid.
NoteShips with an RL locomotion policy. Third-party vendors (e.g. AIFITLAB) sell kits. Year = docs '2024' edition. Licenses (GitHub license API, 2026-09-25): pupper-v3-documentation AGPL-3.0, pupperv3-monorepo and pupperv3-mjx GPL-3.0, pupper_v3_description MIT. CAD is a public Onshape/Fusion share with no stated license. Mass 3 kg per the docs tech specs page.
Sources
- [1]Pupper v3 docs: technical specifications (3 kg)checked 2026-09-25
- [2]pupperv3-monorepo (ROS 2 stack, policies; GPL-3.0)checked 2026-09-25
- [3]pupperv3-mjx (MJX training; GPL-3.0)checked 2026-09-25
- [4]Pupper v3 docs: modifying code, training a policychecked 2026-09-25
- [5]Pupper v3 documentationchecked 2026-09-24
- [6]README: Pupper v3 quick specschecked 2026-09-24