HumanoidStanford University2025US
ToddlerBot
Low-cost, fully 3D-printed open-source small humanoid (0.56 m, 3.4 kg, 30 DOF) for scalable policy learning research.
Difficulty index
11.4/13| Class | humanoid | +5 |
|---|---|---|
| Cost | $5,728 BOM | +1.8 |
| DOF | 30 DOF | +3 |
| Parts | 355 parts | +1.6 |
Top of the ladder. This robot lives on the humanoid domains.
Specimen photographs
6 items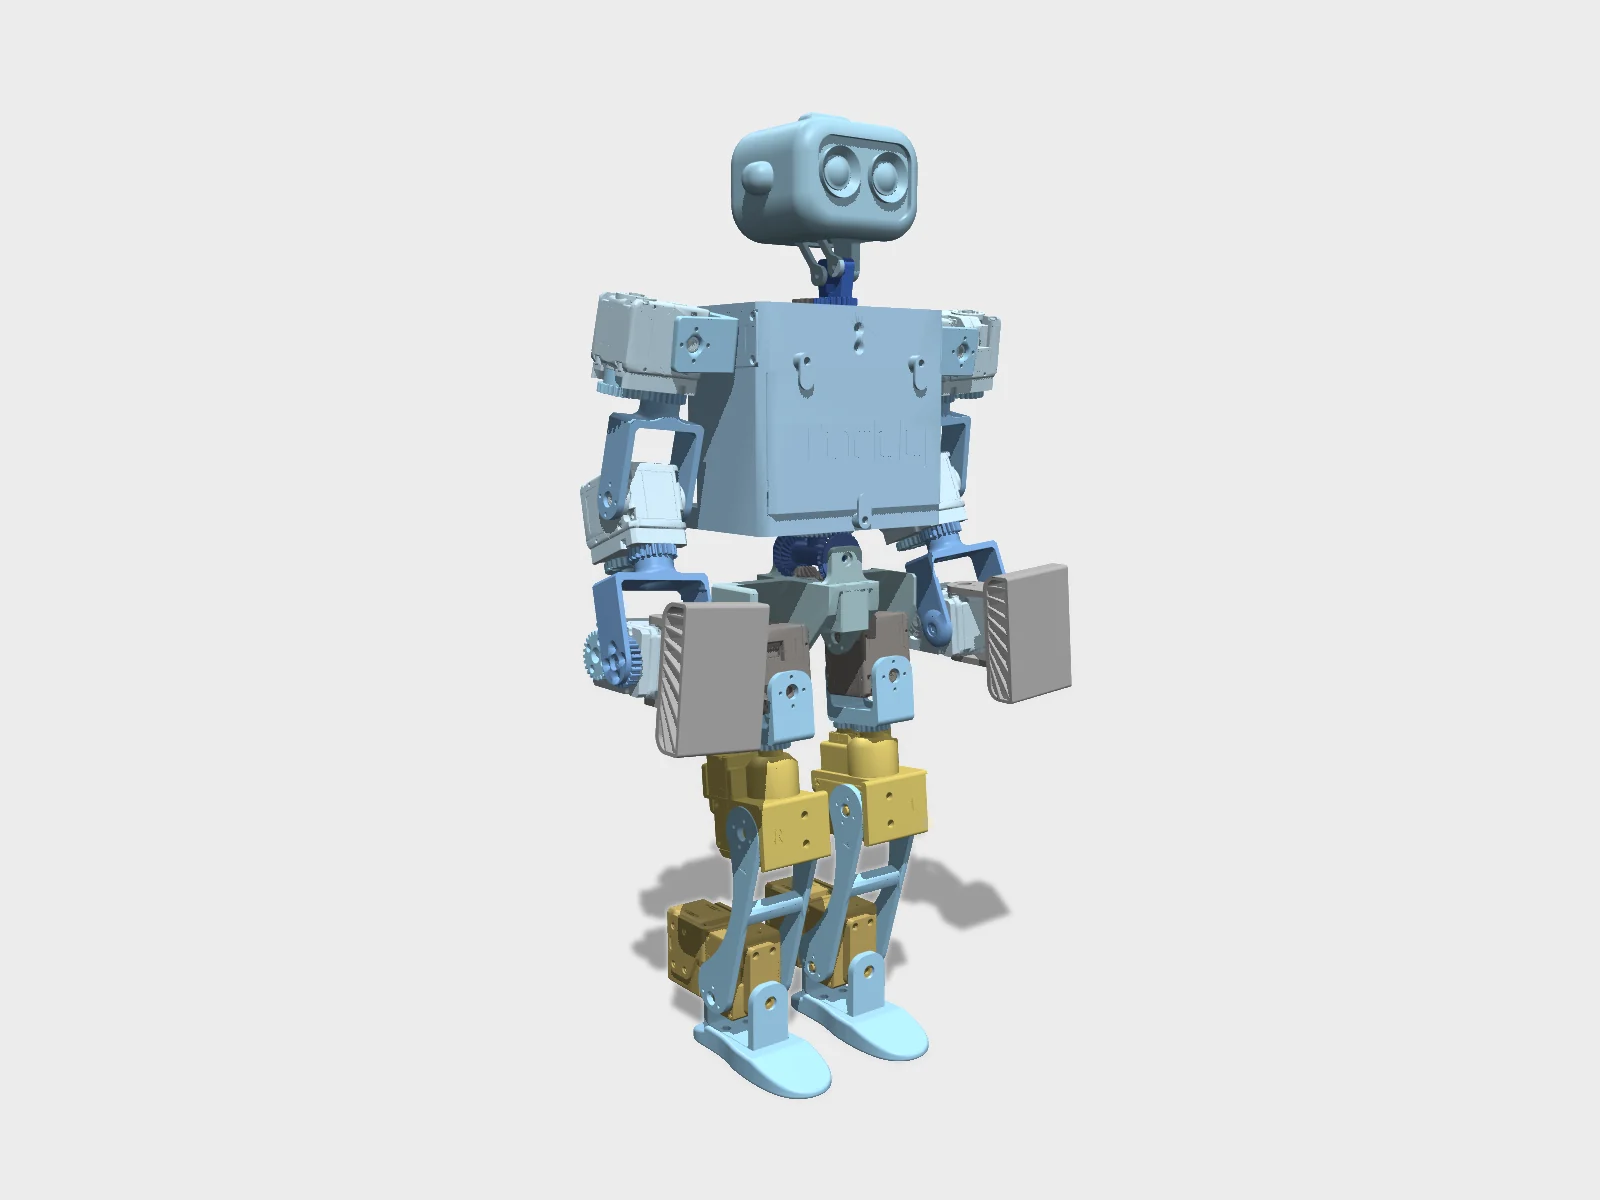
Studio render of the published MJCF, keyframe pose from the model. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/toddlerbot_2xc (MIT) · Hyperspawn render · source 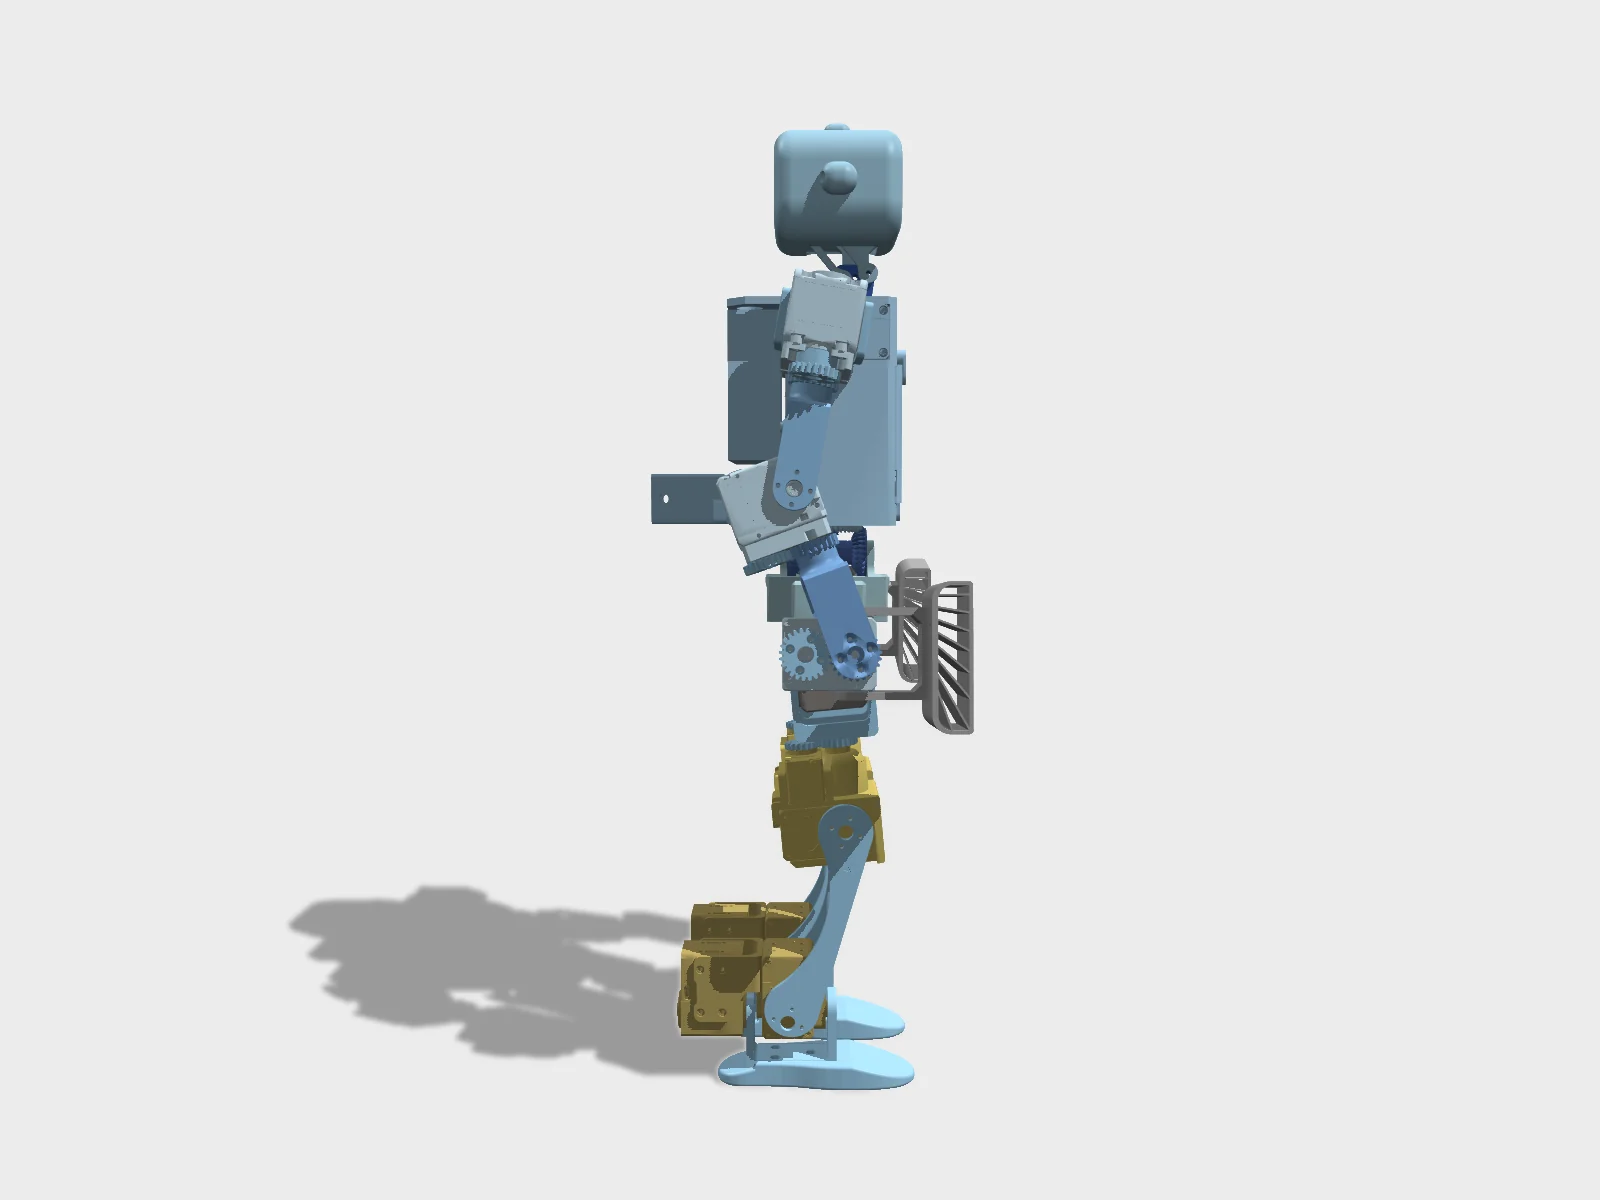
Side view of the same MJCF render, keyframe pose from the model.Rendered by Hyperspawn from mujoco_menagerie/toddlerbot_2xc (MIT) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/toddlerbot_2xc (MIT) · Hyperspawn render · source 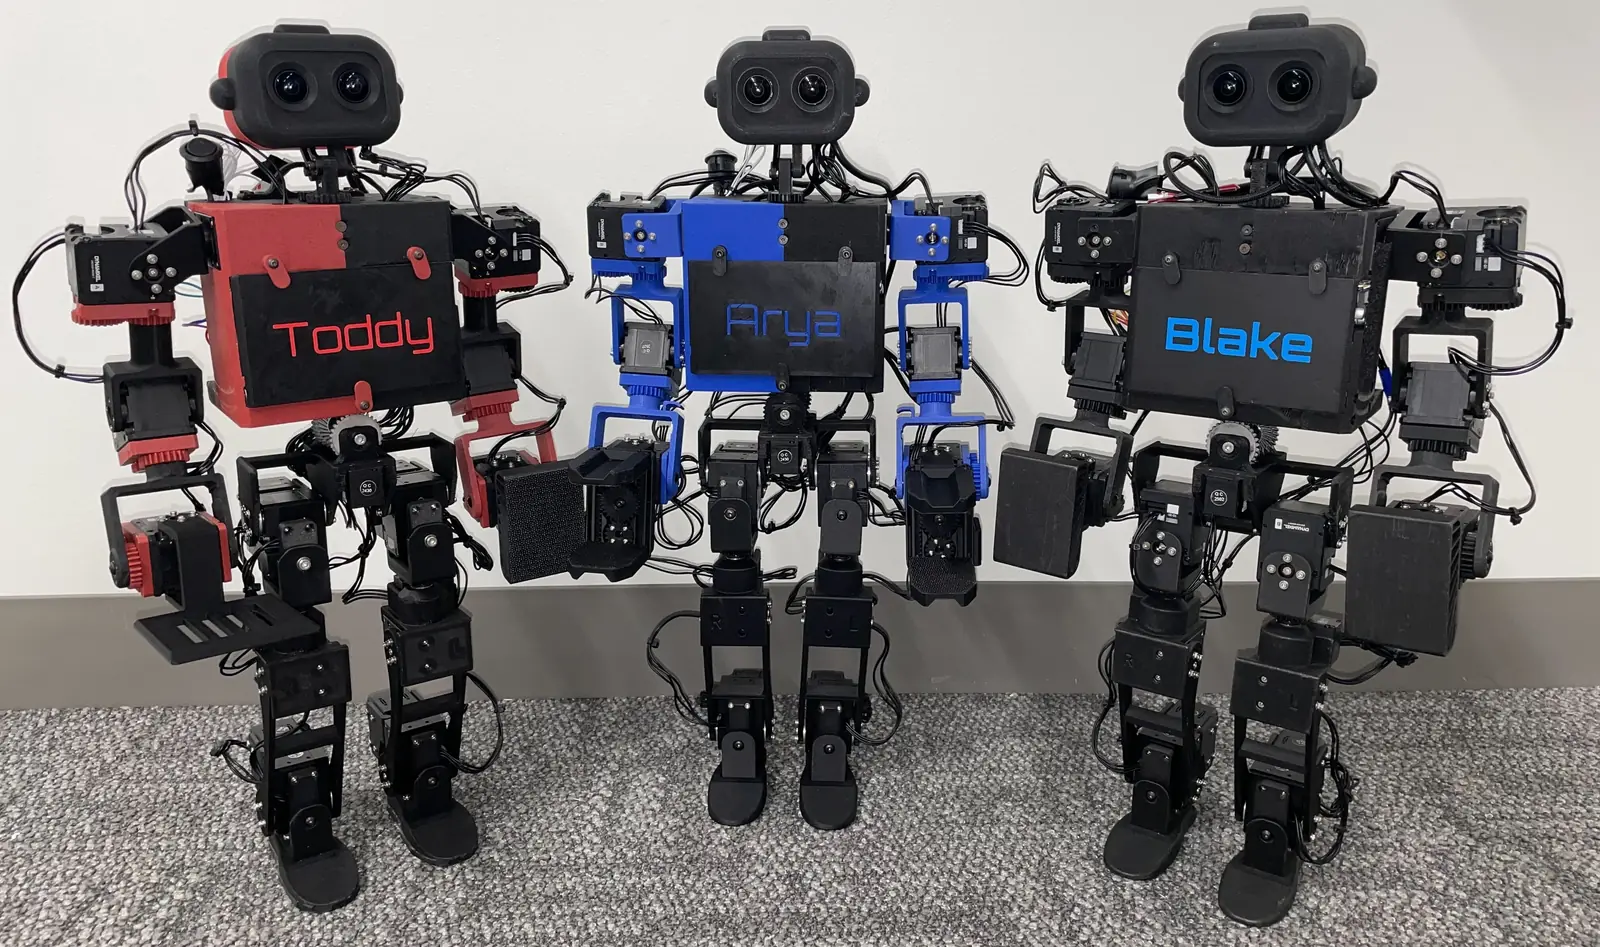
ToddlerBot banner from the project repo.Haochen Shi et al. (ToddlerBot) · MIT · source ToddlerBot: Open-Source ML-Compatible Humanoid Platform for Loco-ManipulationHaochen Shi · official video, embedded · source ToddlerBot 2.0 Arm OverviewHaochen Shi · official video, embedded · source

Spec card
8/13 known- Degrees of freedom
- 30
- Height
- 56 cm
- Mass
- 3.4 kg
- Payload
- 1.48 kg
- BOM total
- $5,728 · 46/47 lines priced
- Part count
- 355
- Actuators
- servo actuators; 7 DOF/arm, 6 DOF/leg, 2 neck, 2 waist
- Compute
- NVIDIA Jetson Orin NX 16GB
Not in the registry: speed, runtime, battery, price, sensors. Left blank rather than guessed.
What you learn building it
- +Whole-body control
- +Dozens of actuators on one bus
- +Balance and fall handling
- +Safe bring-up of a full-size machine
- +FDM 3D printing: 13 parts, about 55 h of printing
- +Tools used: Bambu Lab printer (recommended; sheet lists X1-Carbon Combo + smooth PEI plate + glue), Electric screwdriver (low torque for M2), PH1 screwdriver, Allen keys, Wrench or pliers, Allen key, Dynamixel Wizard 2.0, U2D2 + U2D2 power hub + 12 V adapter (per the manual; the sheet lists U2D2/hub only under Teleoperation) +6
- +16 assembly steps across 10 subassemblies
- +Flashing firmware for Dynamixel X-series servos (Protocol 2.0, TTL, 2 Mbps), TTL power board V8 (CH348L 8-port USB-to-TTL, no MCU firmware), Jetson Orin NX host (JetPack 6.1+, RT kernel)
- +Testing in simulation (URDF/MJCF) before touching hardware
- +Running published learned policies
Openness
- publicCAD
- publicBOM
- publicFirmware
- publicSim model
- publicSoftware
- publicPolicies
Score 100/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Hardware license: CC-BY-NC-SA-4.0. Software license: MIT.
Repos & models
Build it
Has an ORP build package.Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
None. This is the top. Find people building it on humanoidrobots.team.
This is the top of the ladder.
NoteToddlerBot 2.0 released Aug 2025; variants 2XC and 2XM both in Menagerie (toddlerbot_2xm). Onshape CAD + MakerWorld print files + BOM sheet public. Locomotion Beyond Feet follow-up Jan 2026. Mirror fork exists at kscalelabs/toddlerbot. Licenses per README: code and docs MIT; hardware design (Onshape, STL/3MF) CC BY-NC-SA 4.0, non-commercial.
Sources
- [1]Official repo (README license section: code MIT, design CC BY-NC-SA 4.0)checked 2026-09-25
- [2]arXiv paperchecked 2026-09-24
- [3]Project sitechecked 2026-09-24