ArmThe Robot Studio / Hugging FaceFR
SO-100 (SO-ARM100)
Original Standard Open Arm 100: a 3D-printable 6-DOF low-cost arm that served as the first reference hardware for LeRobot; superseded by the SO-101.
Difficulty index
3.4/13| Class | arm | +2 |
|---|---|---|
| Cost | $244 BOM | +0.4 |
| DOF | 6 DOF | +0.6 |
| Parts | 26 parts | +0.4 |
Specimen photographs
6 items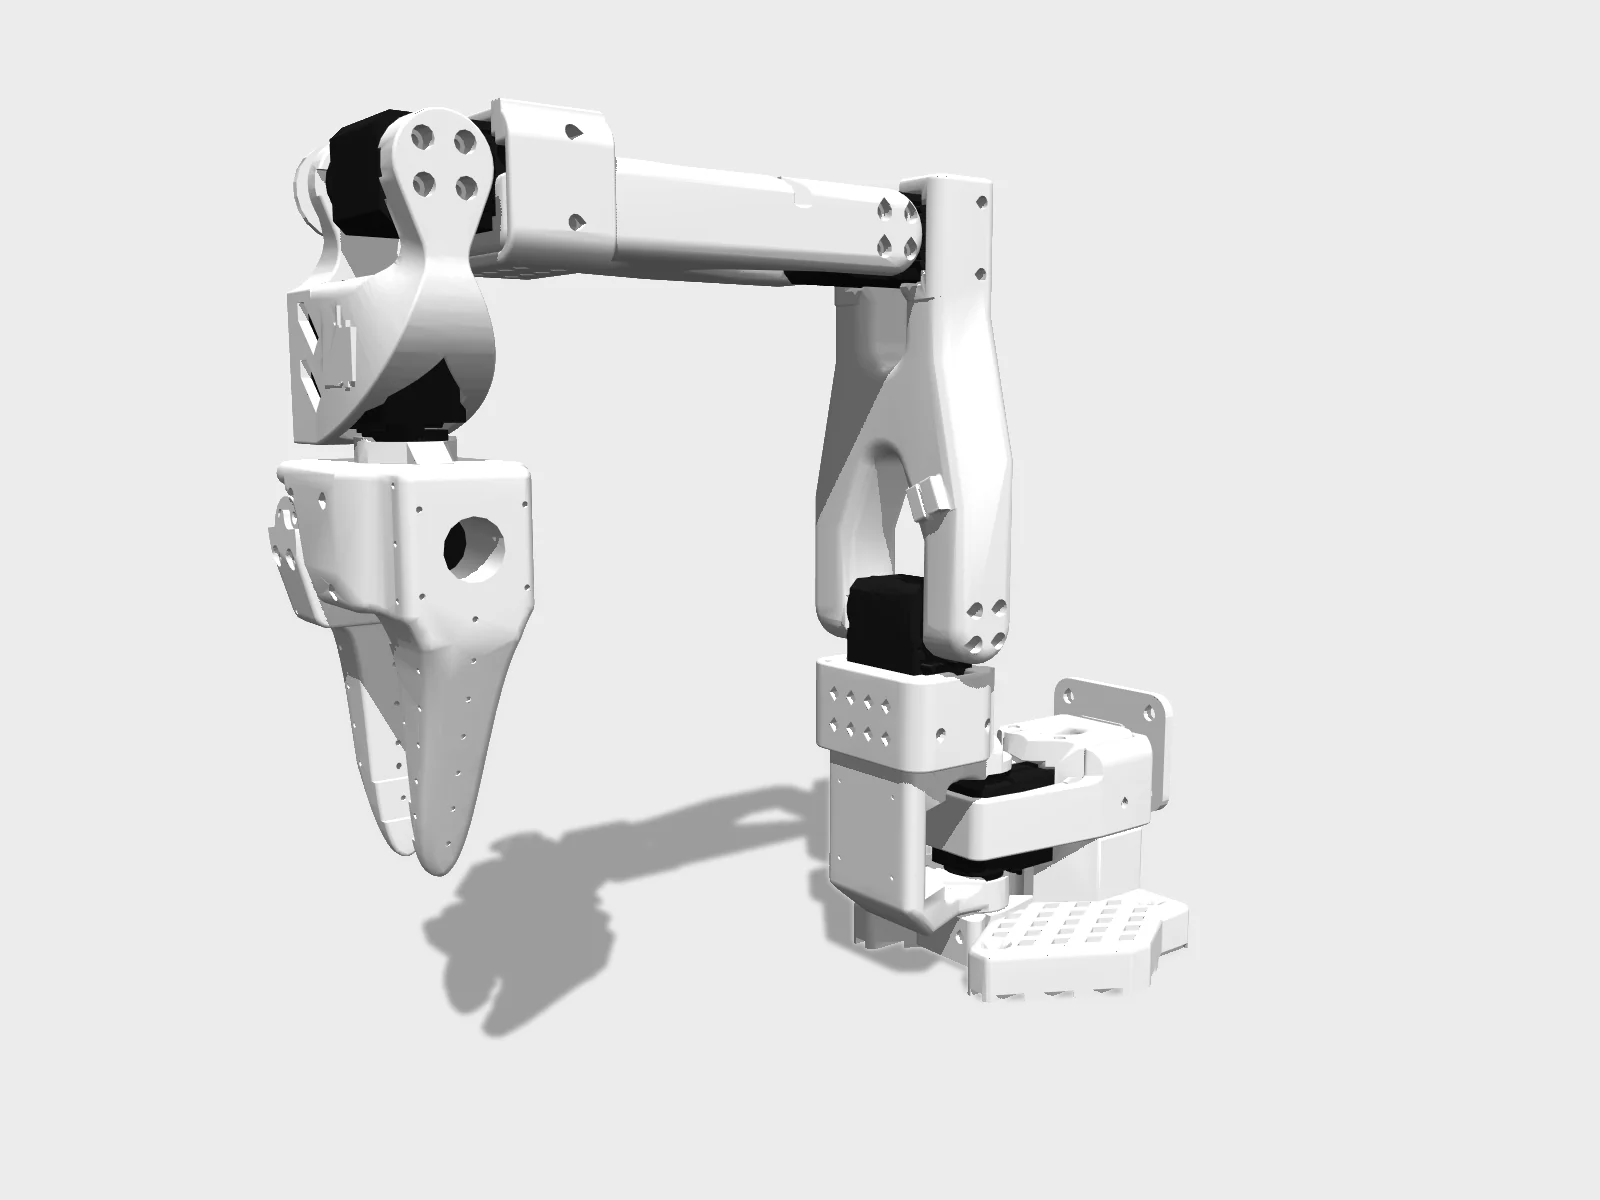
Studio render of the published MJCF, keyframe pose from the model. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/trs_so_arm100 (Apache-2.0) · Hyperspawn render · source 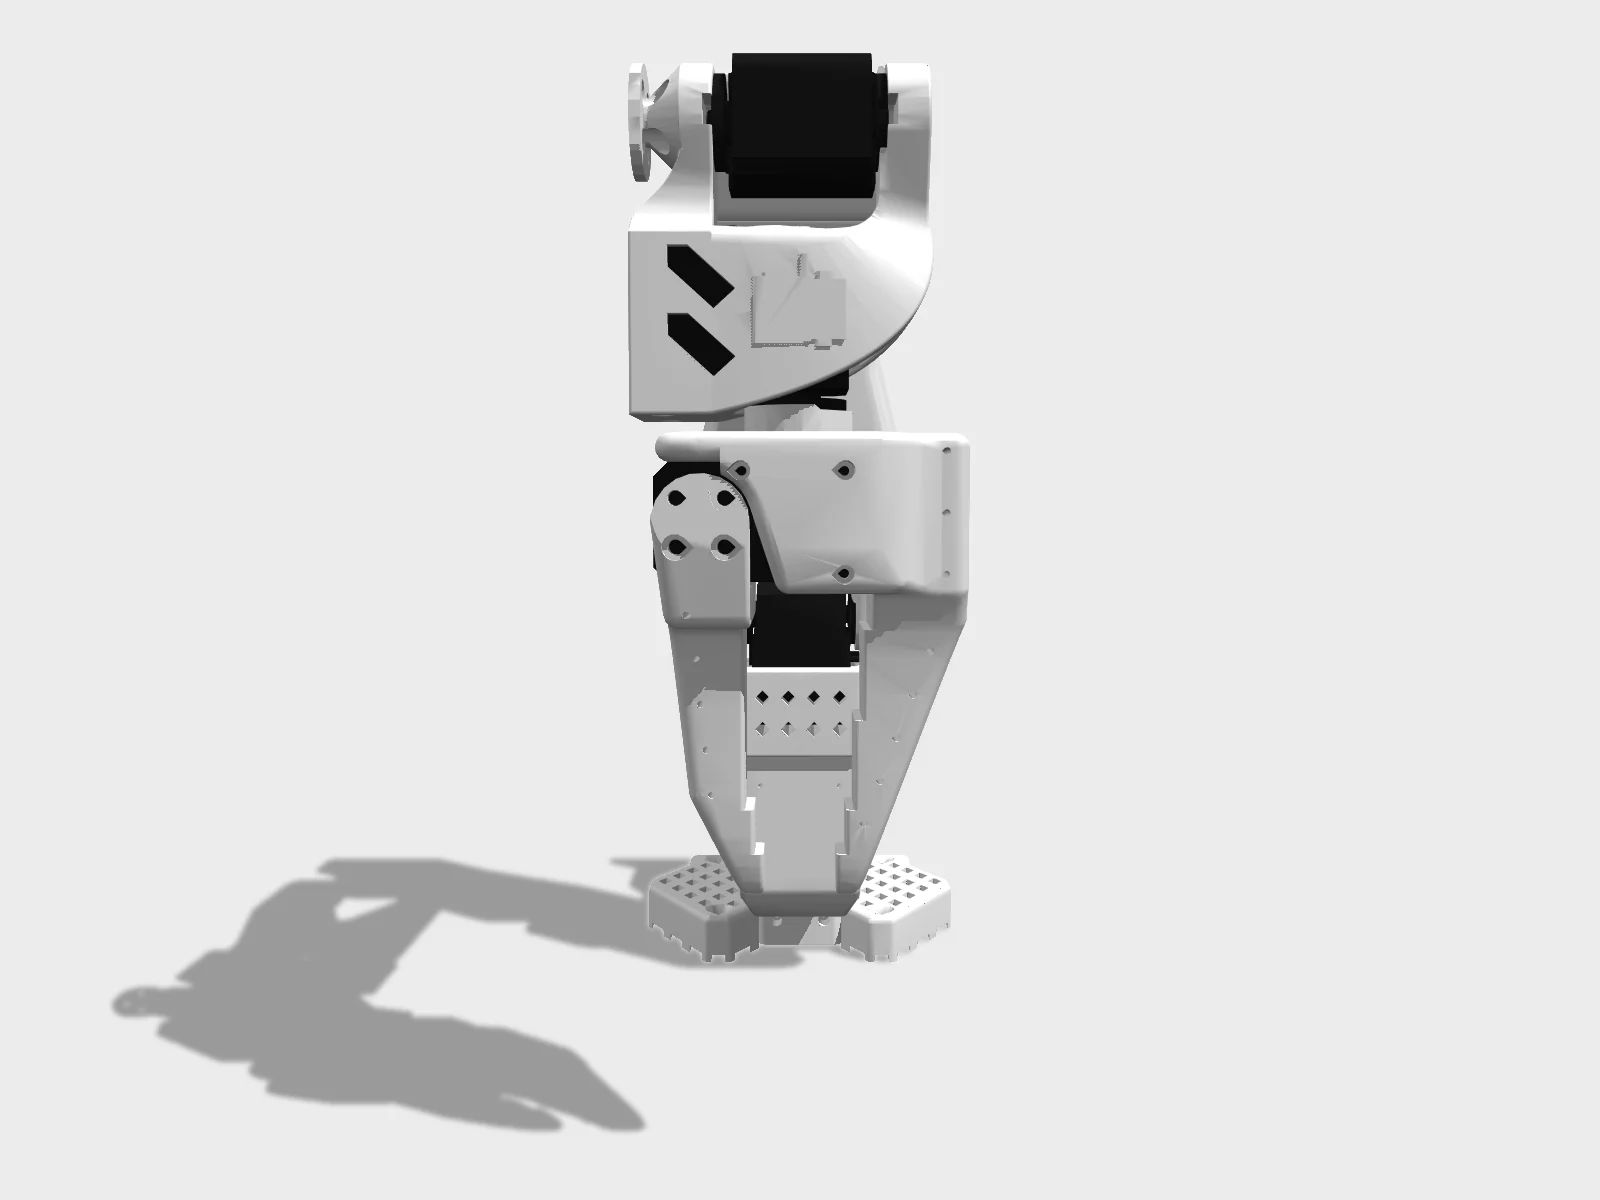
Side view of the same MJCF render, keyframe pose from the model.Rendered by Hyperspawn from mujoco_menagerie/trs_so_arm100 (Apache-2.0) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/trs_so_arm100 (Apache-2.0) · Hyperspawn render · source 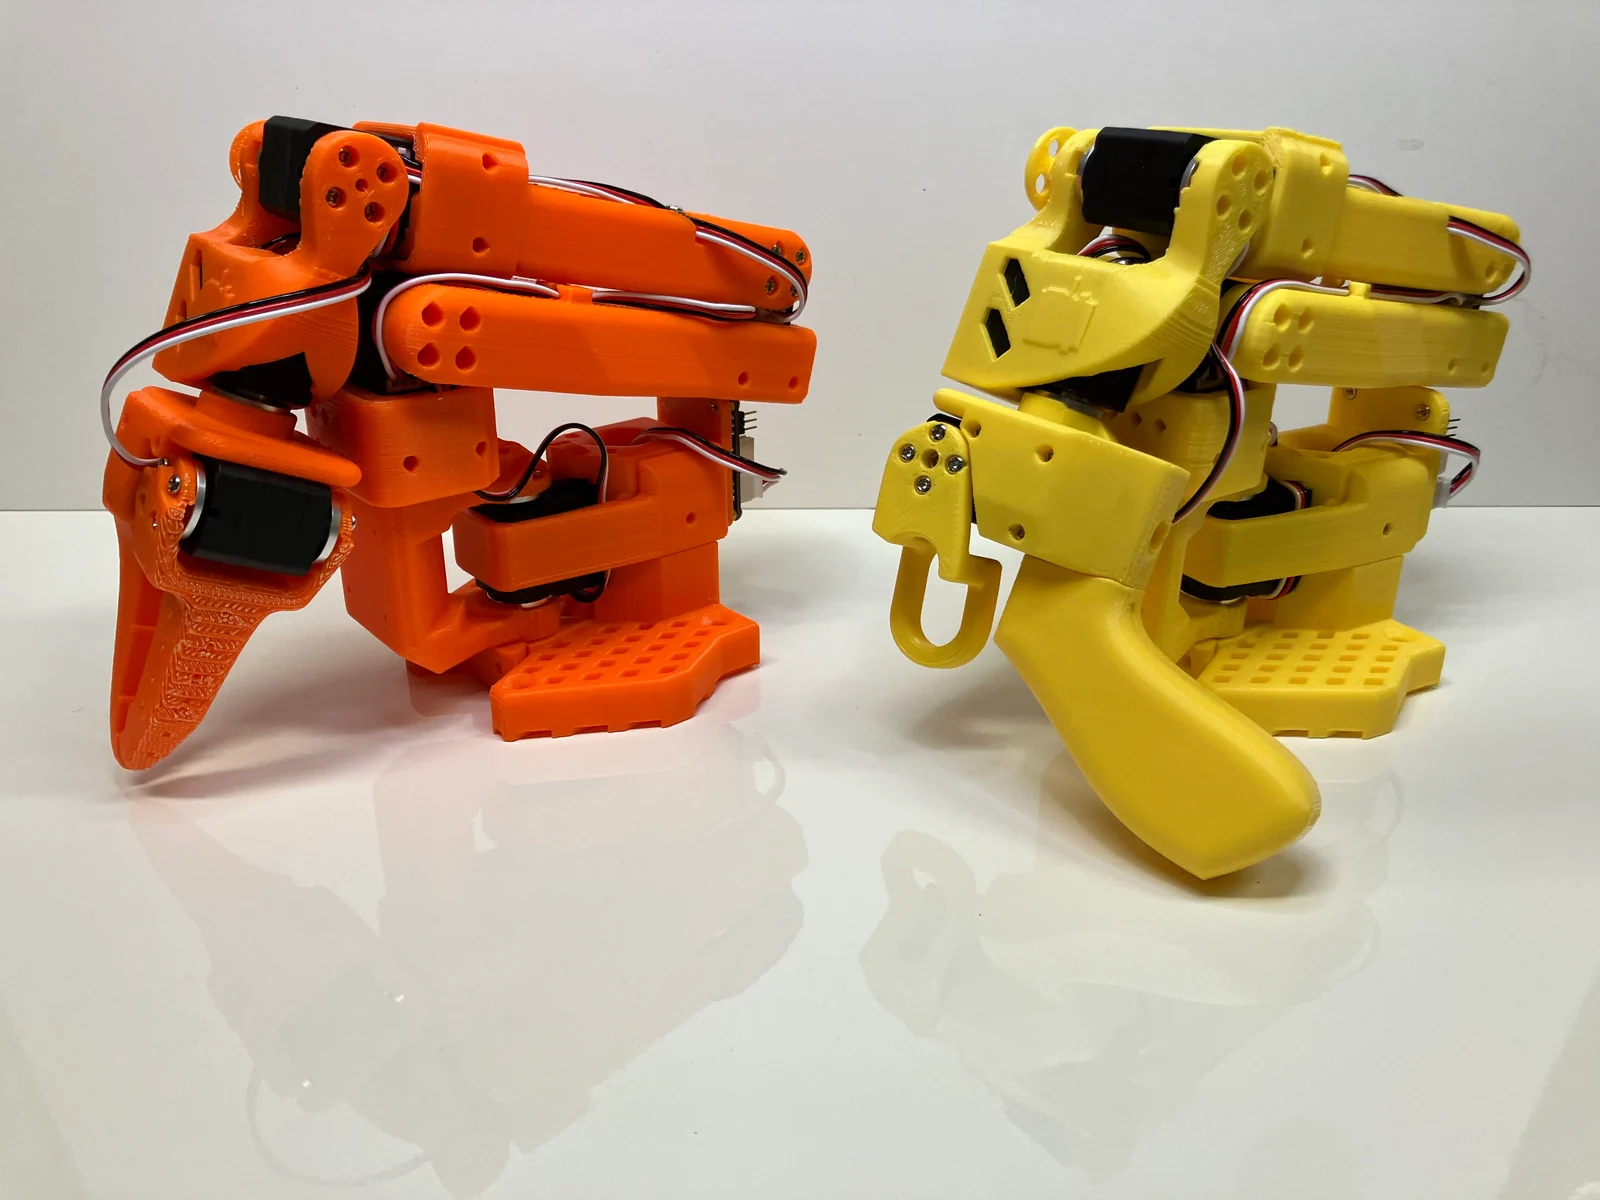
From the SO-ARM100 repo media folder.The Robot Studio (SO-ARM100) · Apache-2.0 · source Build guide for Standard Open ARM 100 5DOF - Low cost DIY 3dprinted robot arm Le Robot Hugging Facetherobotstudio · official video, embedded · source Assemble and Calibrate SO-100: LeRobot Tutorial #7 by Jess MossHugging Face · official video, embedded · source

Spec card
4/13 known- Degrees of freedom
- 6
- BOM total
- $244 · 6/8 lines priced
- Part count
- 26
- Actuators
- Feetech STS3215 serial bus servos
Not in the registry: height, mass, payload, speed, runtime, battery, price, compute, sensors. Left blank rather than guessed.
What you learn building it
- +Forward and inverse kinematics
- +Joint calibration and homing
- +Trajectory planning
- +Teleoperation and collecting demonstrations for learning
- +FDM 3D printing: 5 parts
- +Tools used: FDM printer, 220x220 mm bed or larger, PLA filament, Putty knife, Phillips #0, Phillips #1, Hugging Face account, CUDA or Apple-silicon machine, or HF Jobs
- +13 assembly steps across 8 subassemblies
- +Flashing firmware for Feetech STS3215 servo (EEPROM: ID 1-6 and baudrate via lerobot-setup-motors), Waveshare serial bus servo driver (USB bridge, no user firmware)
- +Testing in simulation (URDF/MJCF) before touching hardware
- +Running published learned policies
Openness
- publicCAD
- publicBOM
- publicFirmware
- publicSim model
- publicSoftware
- publicPolicies
Score 100/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Hardware license: Apache-2.0. Software license: Apache-2.0.
Repos & models
Build it
Discontinued.- BOM total
- $244
- Lines priced
- 6/8
- Parts
- 26
- Steps
- 13
- Version
- 0.1.0
2 lines have no price yet, so the real total is higher.
Largest BOM lines
| Part | Qty | Unit |
|---|---|---|
| Feetech STS3215 servo, 7.4 V (6 follower + 6 leader; gears are removed from the 6 leader units)STS3215 | 12 | $15 |
| Motor control board: Waveshare serial bus servo driver (USB-C), one per arm | 2 | $11 |
| DC power supply, 5 V, 5.5x2.1 mm barrel (one per arm) | 2 | $10 |
| Table clamp, 4 pcs | 1 | $9 |
| USB-C cable, 2-pack | 1 | $7 |
| Precision screwdriver set (Phillips) | 1 | $6 |
| Wrist camera (optional): 32x32 mm USB UVC camera module, min 720p / 30 fps | 1 | ? |
| Overhead / scene camera (optional): USB webcam | 1 | ? |
- Superseded. The SO-ARM100 README marks the SO-100 docs as deprecated and points new builds to the SO-101 (improved wiring, no gear removal, purpose-geared leader servos). The files remain for existing arms and DIY.
- SO-100 vs SO-101: SO-100 leader servos are standard 7.4 V STS3215 with the gears removed by hand, while the SO-101 leader uses intact 1/191 and 1/147 geared servos. SO-100 motor IDs must be set before assembly because the connectors are hard to reach afterwards. The SO-100 gripper motor takes 3 screws per side, the SO-101 2. The two use different STL sets (SO_ARM100_08k vs *_SO101), and some SO-101 add-ons, such as the hex-nut wrist camera mount, are stated not to fit the SO-100.
- USD prices are the SO100.md figures (two-arm total $232, 244€, ¥1343.16) and exclude printing and cameras. The two-arm servo line links a 6-pack listing while the unit price is per servo.
- The table-clamp row in SO100.md is misaligned: a ¥9.2 TaoBao entry sits in the EU columns and there is no EU link.
- SO100.md footnotes 1-3 (servo, power supply, screwdriver) are referenced but not present in the file. Its printing links point to /stl_files_for_3dprinting/..., which no longer exists; the files are now under STL/SO100/.
- The upstream BOM has no fastener line. Screws are not itemised and the SO-100 assembly text gives no screw sizes (the SO-101 guide uses M2x6 and M3x6).
- Cameras are not in the core BOM; the camera lines come from the optional mount guides and are marked optional.
Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
Aero Hand Open →Chestnut Robotics (formerly TetherIA) · hand · index 5.5Easiest buildable hand, the next class up from arm. Adds tendon and linkage transmissions.
Note'discontinued' = superseded by SO-101 in the same repo (SO100.md kept); files remain available for DIY.
Sources
- [1]GitHub repochecked 2026-09-24
- [2]Hackster: SO-101 as next-gen of SO-100checked 2026-09-24
- [3]LeRobot SO-100 docschecked 2026-09-25