RoverSIGRobotics UIUC / Hugging Face LeRobotUS
LeKiwi
Low-cost mobile manipulator combining a three-omni-wheel holonomic base with an SO-101 arm, a Raspberry Pi 5 and two RGB cameras, supported in LeRobot.
Difficulty index
4.4/13| Class | rover | +1.5 |
|---|---|---|
| Cost | $490 BOM | +0.7 |
| DOF | unknown · midpoint | +1.5 |
| Parts | 50 parts | +0.7 |
Specimen photographs
4 items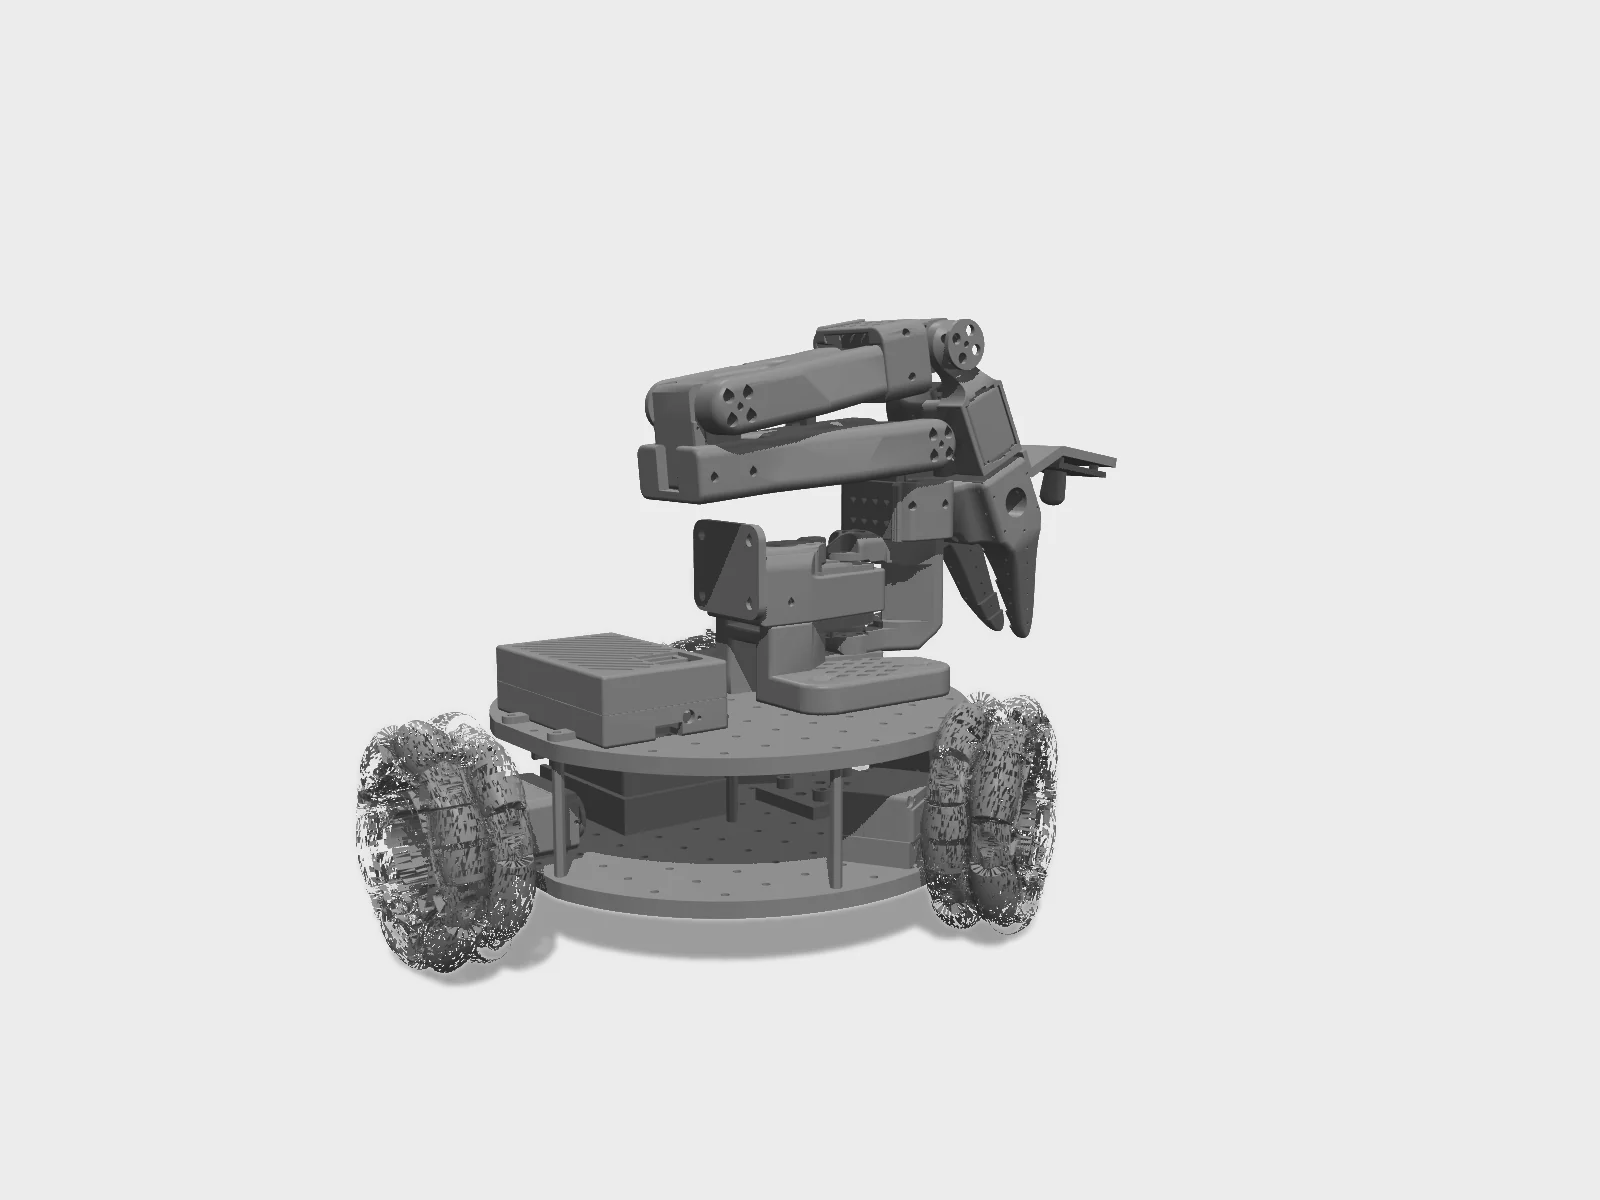
Studio render of the published URDF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from SIGRobotics-UIUC/LeKiwi (Apache-2.0) · Hyperspawn render · source 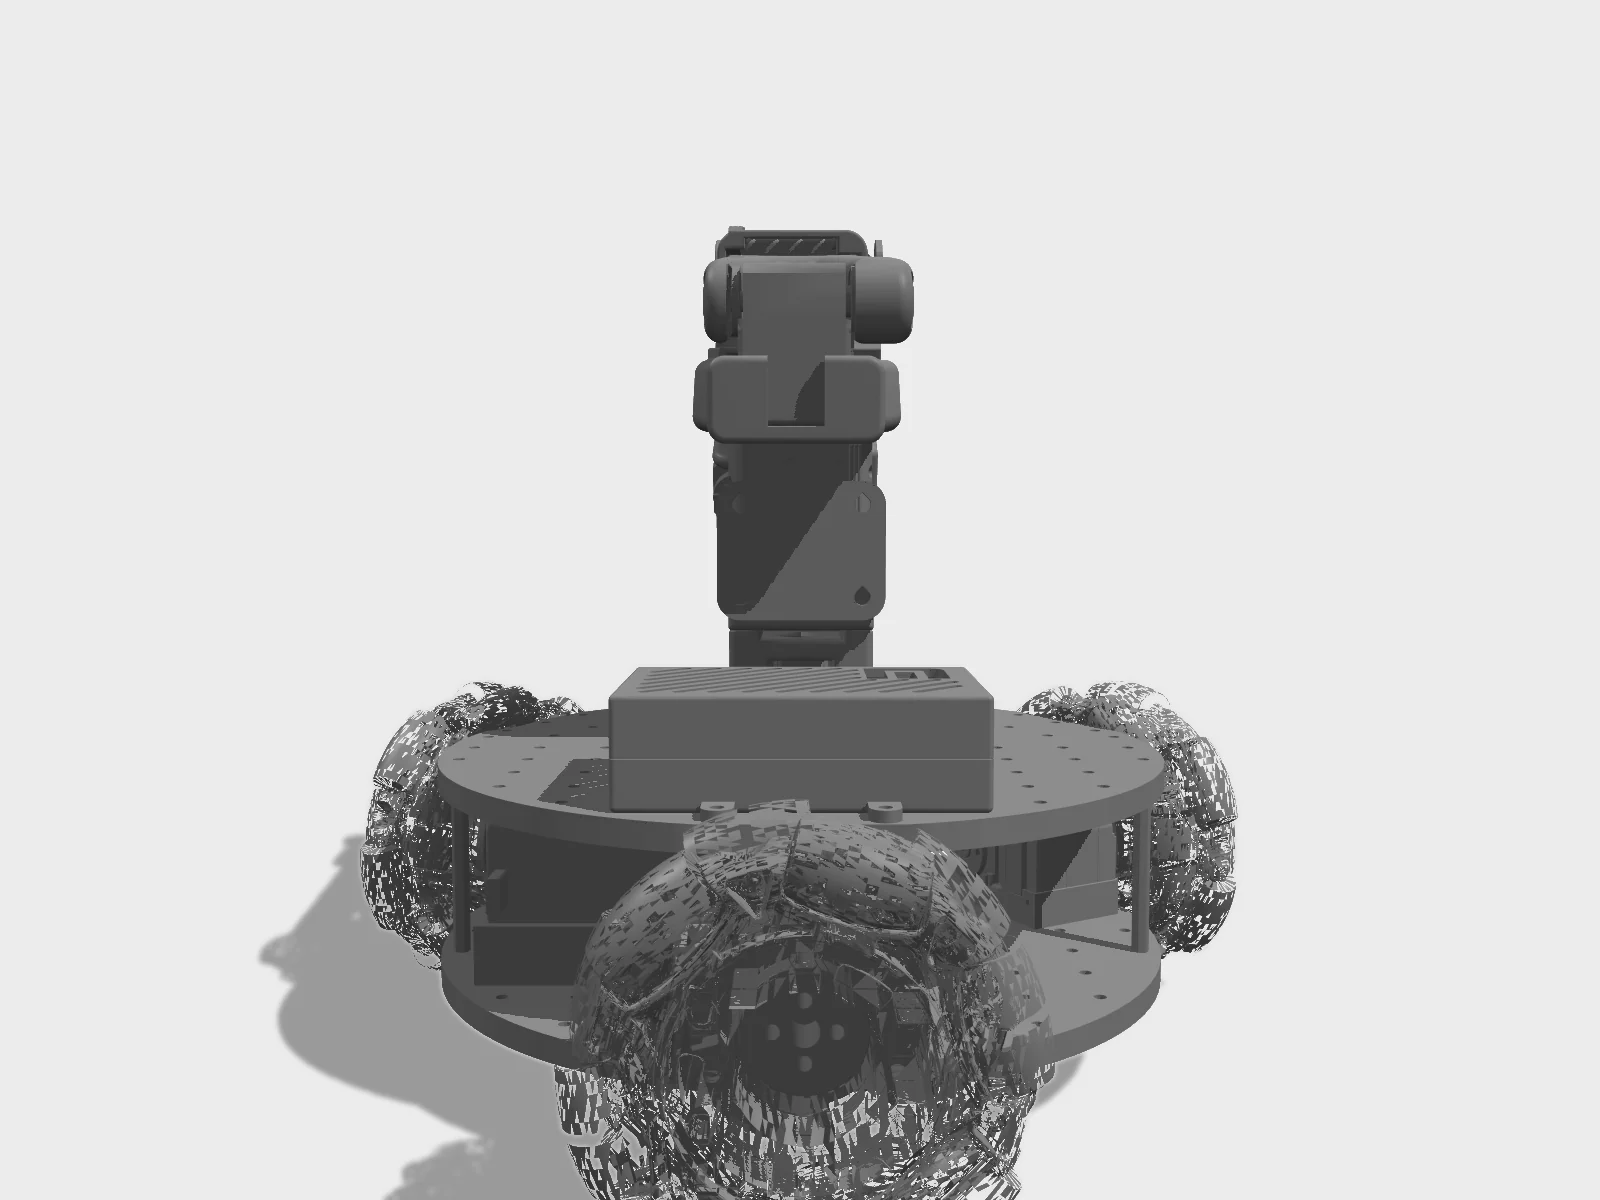
Side view of the same URDF render, the model's zero pose.Rendered by Hyperspawn from SIGRobotics-UIUC/LeKiwi (Apache-2.0) · Hyperspawn render · source 4 s turntable of the URDF studio render.Rendered by Hyperspawn from SIGRobotics-UIUC/LeKiwi (Apache-2.0) · Hyperspawn render · source 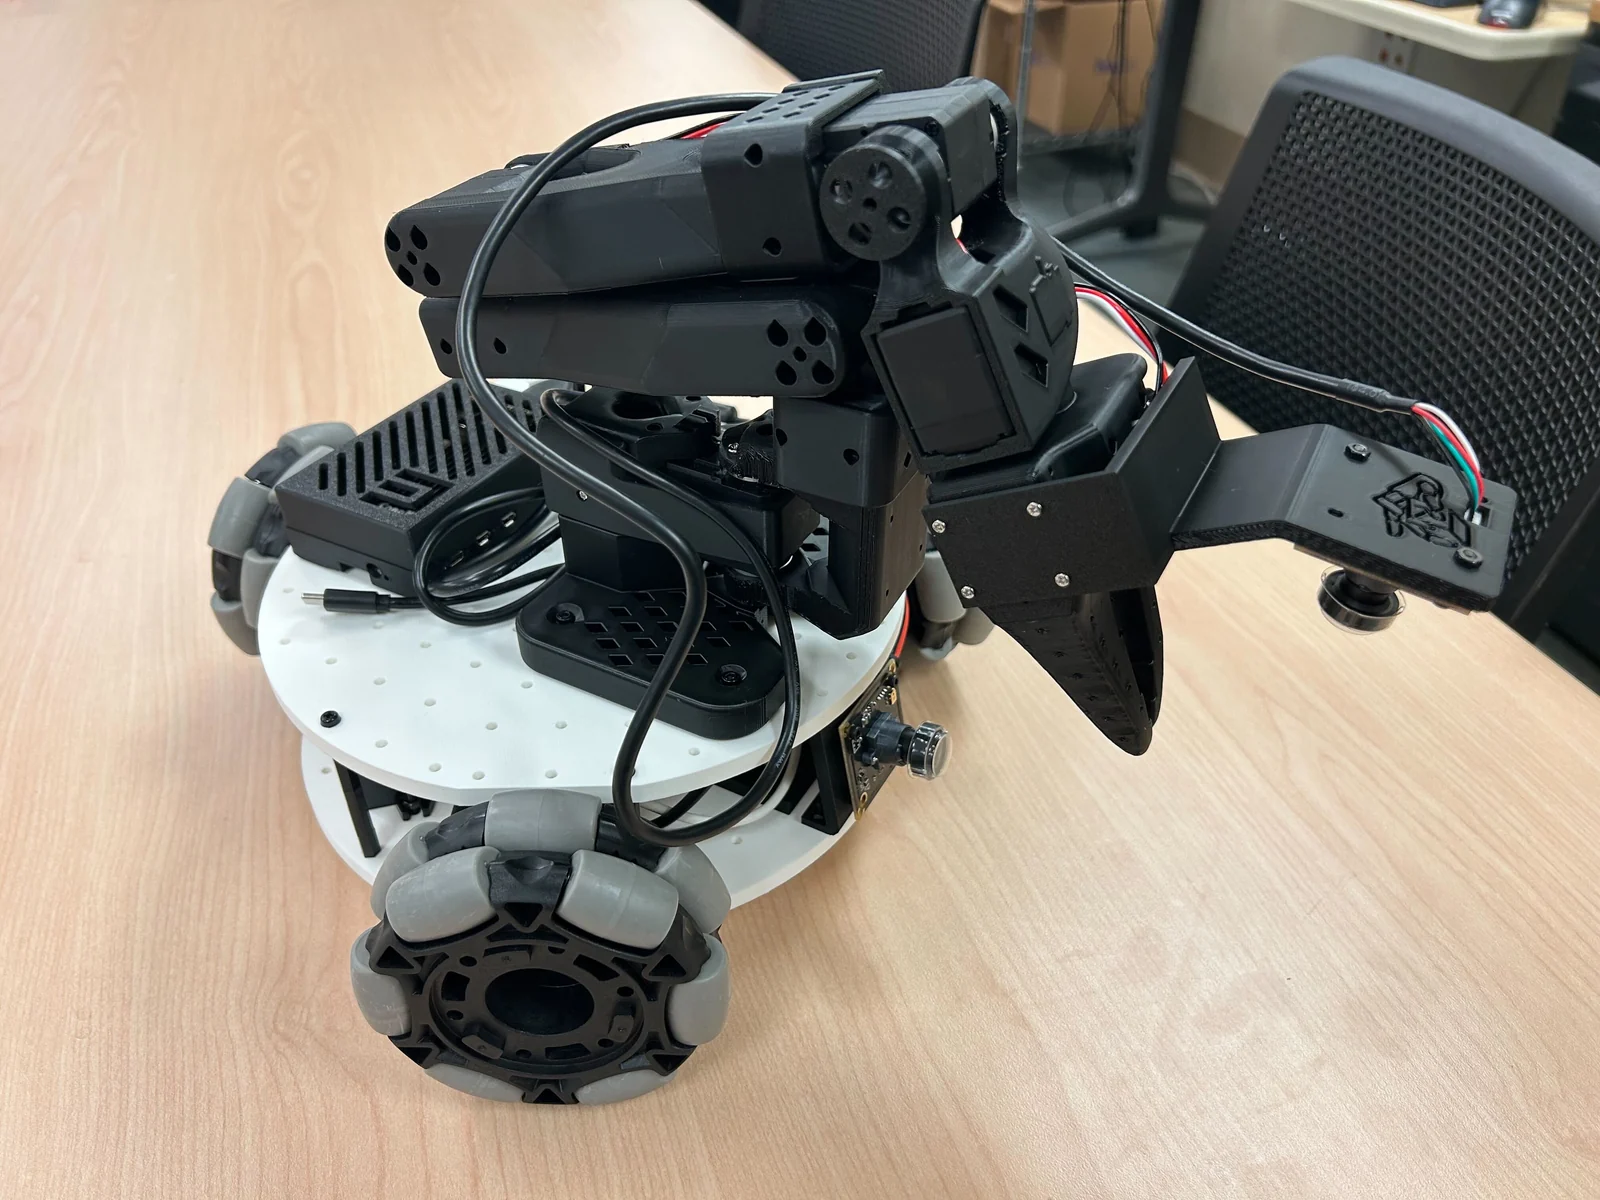
Real build, from the LeKiwi README.SIGRobotics UIUC (LeKiwi) · Apache-2.0 · source

Spec card
4/13 known- BOM total
- $490 · 15/15 lines priced
- Part count
- 50
- Compute
- Raspberry Pi 5
- Sensors
- Workspace and wrist RGB cameras
Not in the registry: degrees of freedom, height, mass, payload, speed, runtime, battery, price, actuators. Left blank rather than guessed.
What you learn building it
- +Differential drive and odometry
- +Battery sizing and power budgets
- +Reading IMUs, encoders and range sensors
- +Navigation and mapping
- +FDM 3D printing: 18 parts
- +Tools used: FDM printer (tested on Bambu Lab P1S), PLA filament, Phillips #0, Phillips #1, Raspberry Pi Imager, Laptop on the same network, Hex key set, Multimeter +3
- +16 assembly steps across 10 subassemblies
- +Flashing firmware for Feetech STS3215 x9 on one bus (arm IDs 1-6, wheels 7 left / 8 back / 9 right), Waveshare serial bus servo driver (USB bridge, no user firmware), Raspberry Pi 5 running lerobot.robots.lekiwi.lekiwi_host (ZeroMQ, ports 5555 cmd / 5556 observations)
- +Testing in simulation (URDF/MJCF) before touching hardware
Openness
- publicCAD
- publicBOM
- publicFirmware
- publicSim model
- publicSoftware
- not publicPolicies
Score 90/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Hardware license: Apache-2.0. Software license: Apache-2.0.
Repos & models
Build it
Has an ORP build package.- BOM total
- $490
- Lines priced
- 15/15
- Parts
- 50
- Steps
- 16
- Version
- 0.1.0
Largest BOM lines
| Part | Qty | Unit |
|---|---|---|
| Feetech STS3215 servo, 7.4 V: SO-101 follower (on the base) + leader (on the laptop), 6 + 6STS3215 | 12 | $15 |
| Raspberry Pi 5, 4 GBSC1111 | 1 | $60 |
| Feetech STS3215 servo, 7.4 V: 3 wheel drives (continuous rotation, IDs 7 left / 8 back / 9 right)STS3215 | 3 | $15 |
| 20000 mAh 85 W USB-C power bank (5 V version: powers the Pi and the servo board) | 1 | $42 |
| 4 in (100 mm) omni wheel | 3 | $9.99 |
| USB camera (front base camera + wrist camera) | 2 | $12.98 |
| Motor control board: Waveshare serial bus servo driver (one on LeKiwi for arm + wheels, one for the leader) | 2 | $11 |
| Table clamp, 4 pcs (leader arm) | 1 | $18 |
- Upstream pins: SIGRobotics-UIUC/LeKiwi@efa608d7ee5a495a4803b1d28cd0c955b4f1e033 (2026-08-05): BOM.md, 3DPrinting.md, Assembly.md, 3DPrintMeshes; huggingface/lerobot@e624f3f7f8411ec3a02635d06e79373341e5ef35 (2026-09-24, lerobot 0.6.2): docs/source/lekiwi.mdx, src/lerobot/robots/lekiwi; huggingface.co/docs/lerobot/lekiwi as of 2026-09-25. BOM lines follow the upstream 5 V version (recommended for first builds); 12 V and wired swaps are listed in alts.
- Three upstream variants: 5 V (power bank, recommended for first builds), 12 V (12 V 5 A battery and 12 V servos, for heavier lifts) and wired (no Pi or battery; laptop over USB hub). This package lists the 5 V BOM with 12 V and wired swaps in alts. Upstream totals: 5 V $499 / €526 / ¥2829; 12 V $482 / €545.8 / ¥2891; base-only wired $184 / €235 / ¥963.9. All exclude 3D printing.
- The LeKiwi BOM's SO-101 teleoperation set lists 12 identical STS3215 servos from a 6-pack listing. The SO-ARM100 README specifies mixed leader gearing for the SO-101 (1/191 on joints 1 and 3, 1/147 on joints 4-6). Buy the leader servos per the SO-ARM100 BOM if you want the SO-101 leader behaviour.
- The LeKiwi docs and examples use so100_leader for the teleop arm. In lerobot 0.6.x so100_leader and so101_leader map to the same class, so either works.
- Webcam mounting needs M3x12, 2x M3x35 bolts and M3 nuts, and the Arducam option needs M2.5x12 screws. These may not all be in the assorted screw set.
- The upstream 5 V wiring is given only as a diagram image in Assembly.md, and the 12 V wiring is in prose (Wago lever connectors). There is no fuse or power switch in either BOM.
- Keyboard base teleoperation relies on a global key listener: it works on X11, Windows and macOS with Input Monitoring granted, not on Wayland or headless sessions.
- Several upstream vendor links are short links (a.co, e.tb.cn, qr.1688.com) or tracking URLs, and they resolve to marketplace listings that change often.
- Seeed Studio sells a LeKiwi full kit (12 V) at https://www.seeedstudio.com/LeKiwi-Full-Kit-12V-Verision.html (listed in BOM.md). The only public LeKiwi policies are community fine-tunes with no reported evaluation.
Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
SO-101 (SO-ARM101) →The Robot Studio / Hugging Face · arm · index 3.7Easiest buildable arm, the next class up from rover. Adds forward and inverse kinematics.
NoteMobile manipulator (wheeled base + arm), classed as rover. Fusion 360 CAD public. Dynamixel variant uses Koch v1.1 arm. City = UIUC campus. Three upstream variants: 5 V (power bank), 12 V and wired. Seeed Studio sells a 12 V full kit, listed in the repo BOM.
Sources
- [1]LeKiwi BOM (variant totals, Seeed kit link)checked 2026-09-25
- [2]Seeed Studio LeKiwi full kit (12 V)checked 2026-09-25
- [3]LeKiwi repochecked 2026-09-24
- [4]LeRobot LeKiwi docschecked 2026-09-24