HumanoidUnitree Robotics2023CN
Unitree H1
Full-size electric humanoid from Unitree with 5-DOF-per-leg design, known for a 3.3 m/s humanoid walking-speed record.
Difficulty index
9.8/13| Class | humanoid | +5 |
|---|---|---|
| Cost | unknown · midpoint | +1.5 |
| DOF | 23 DOF | +2.3 |
| Parts | unknown · midpoint | +1 |
Top of the ladder. This robot lives on the humanoid domains.
humanoidrobots.systems/unitree/h1 ↗
Full spec sheet and comparisons
humanoidrobot.build/unitree/h1
Closed hardware. Buy link only.
humanoidrobots.training/unitree/h1 ↗
Simulate and train policies
Specimen photographs
5 items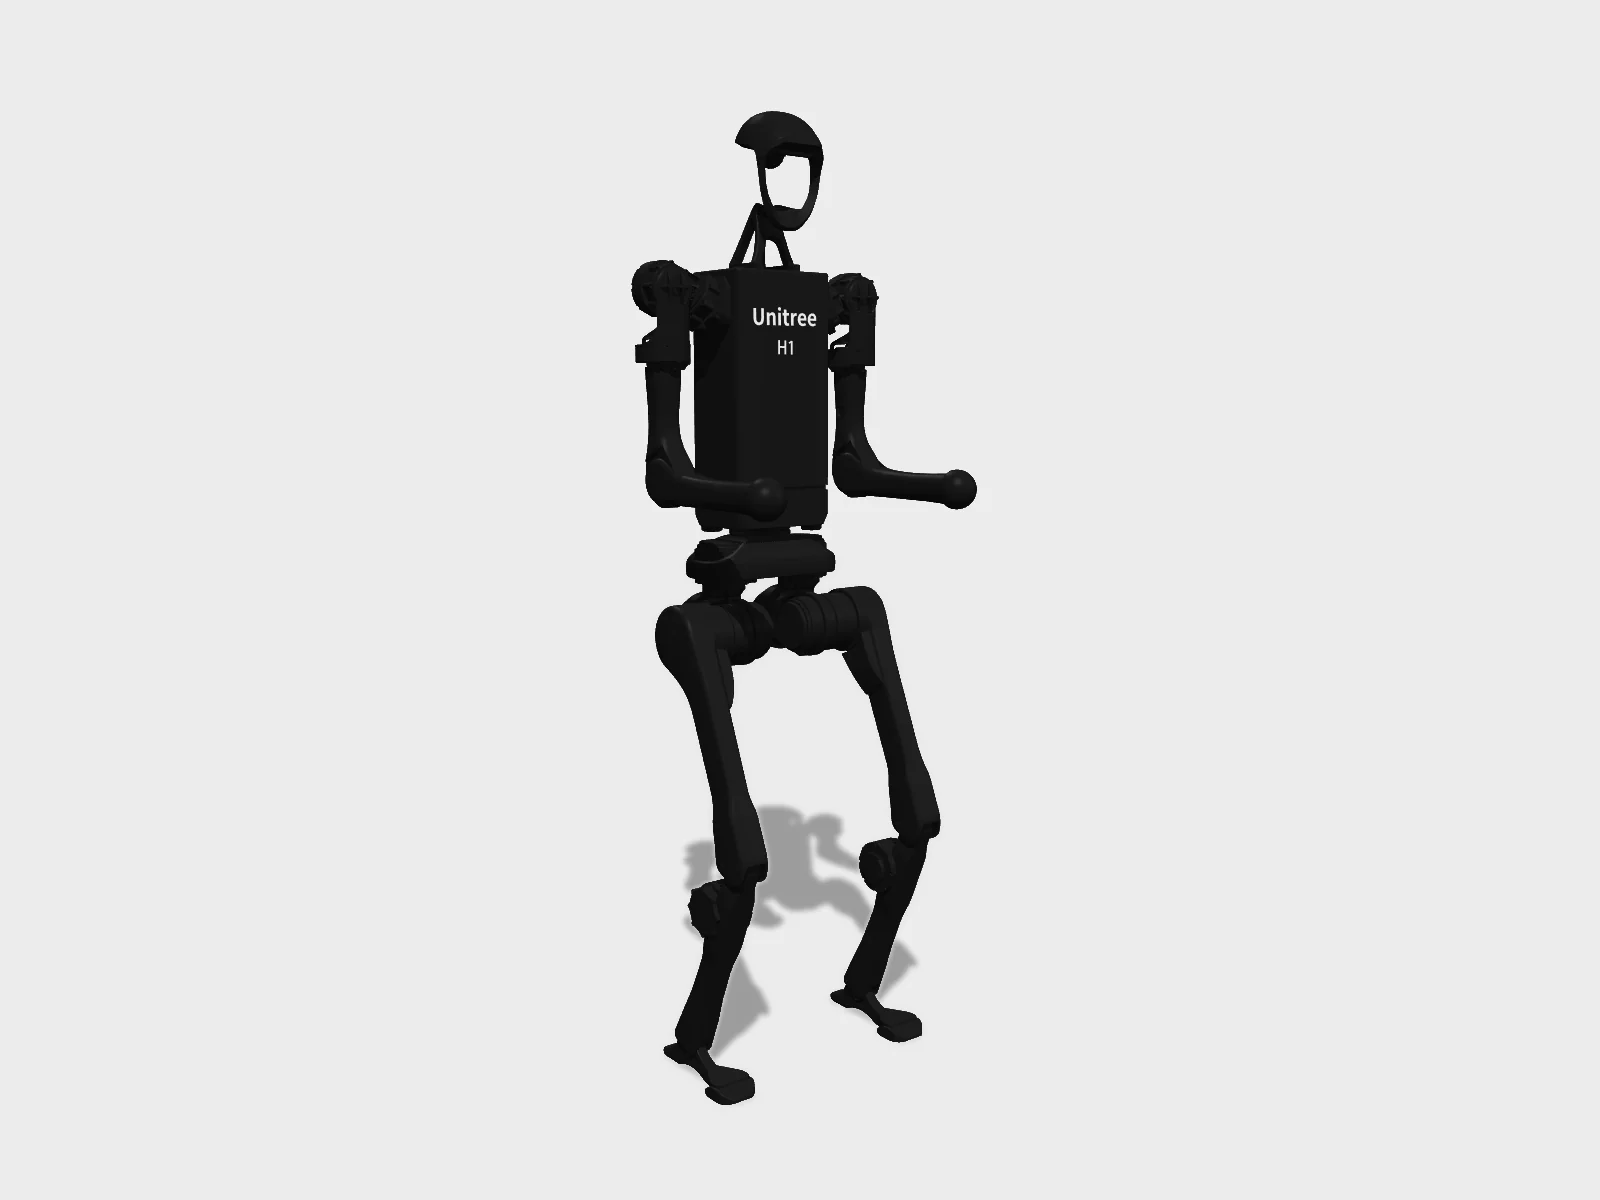
Studio render of the published MJCF, keyframe pose from the model. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/unitree_h1 (BSD-3-Clause) · Hyperspawn render · source 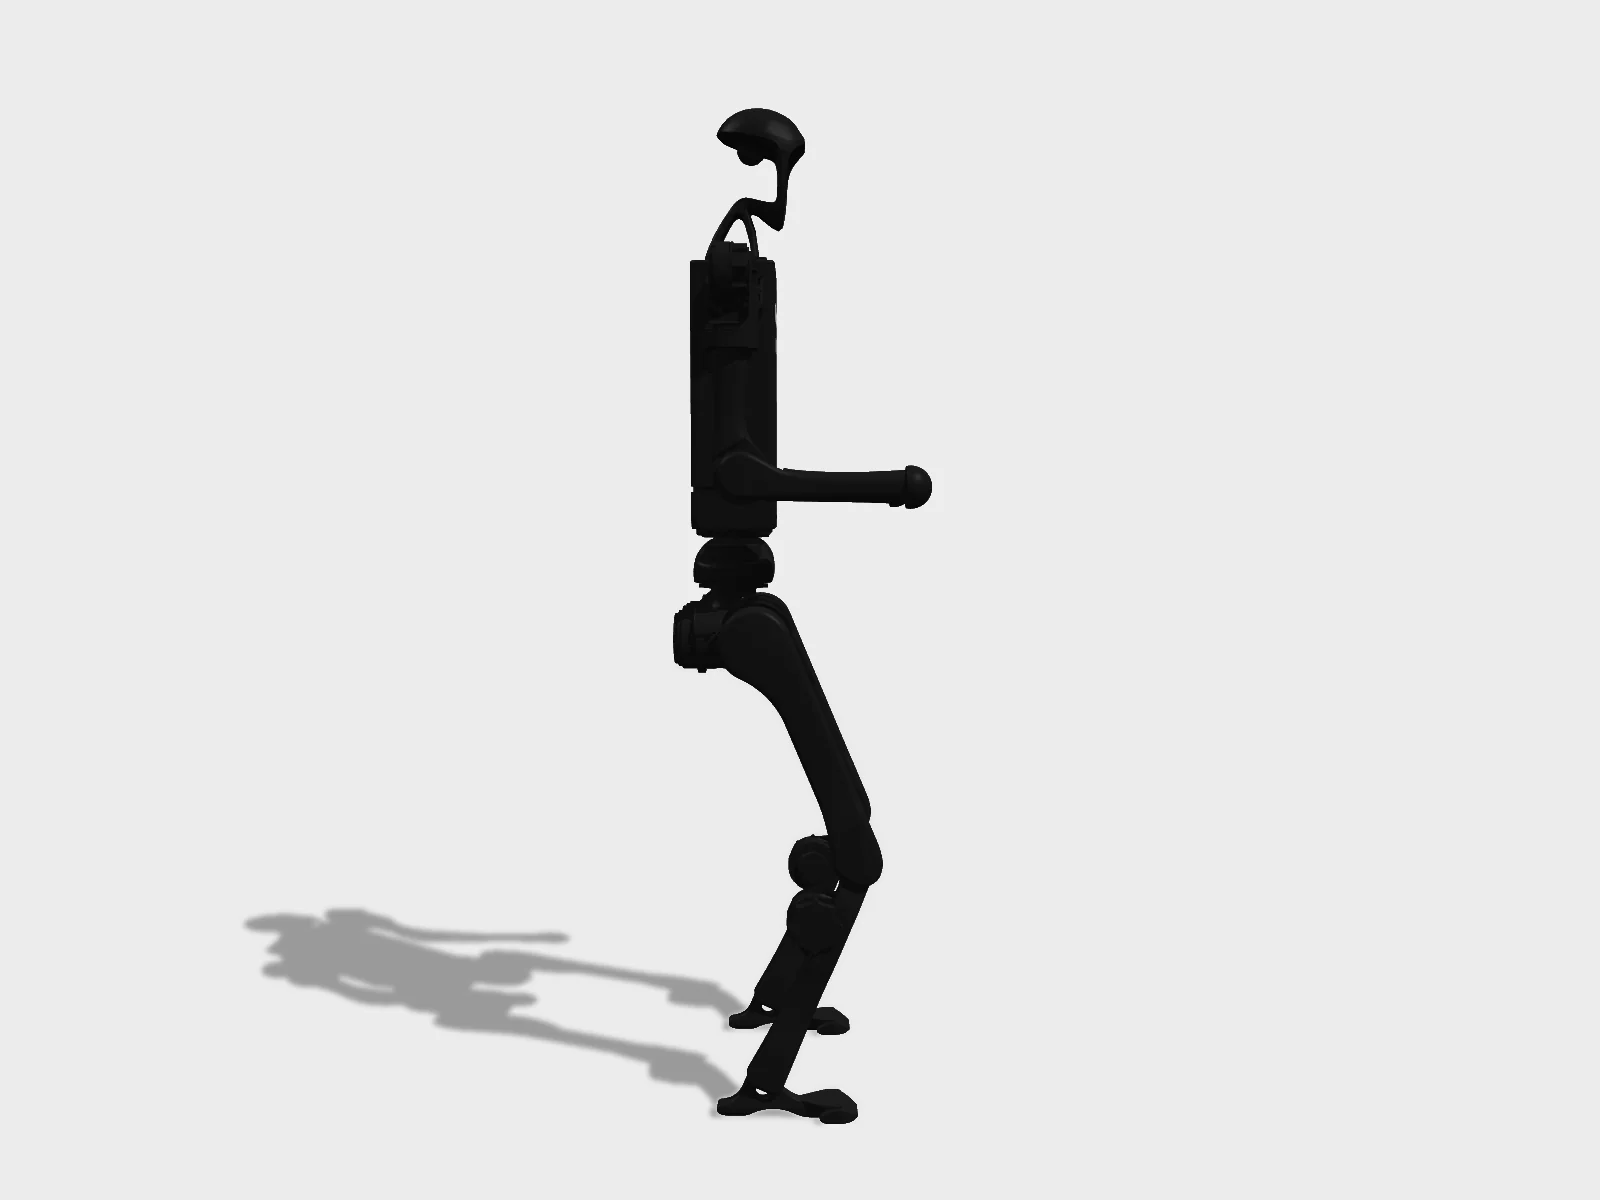
Side view of the same MJCF render, keyframe pose from the model.Rendered by Hyperspawn from mujoco_menagerie/unitree_h1 (BSD-3-Clause) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/unitree_h1 (BSD-3-Clause) · Hyperspawn render · source Introducing Unitree H1: Its First General-purpose Humanoid Robot| Embodied AI Price below $90kUnitree Robotics · official video, embedded · source Unitree H1 Breaking humanoid robot speed world record [full-size humanoid] Evolution V3.0Unitree Robotics · official video, embedded · source
Spec card
8/13 known- Degrees of freedom
- 23
- Height
- 180 cm
- Mass
- 47 kg
- Speed
- 3.3 m/s
- Battery
- 864 Wh
- Actuators
- Unitree in-house electric joint motors
- Compute
- Intel Core i5 standard; i7 or Jetson Orin NX optional
- Sensors
- 3D LiDAR, depth camera
Not in the registry: payload, runtime, price, bom total, part count. Left blank rather than guessed.
What you learn building it
- +Whole-body control
- +Dozens of actuators on one bus
- +Balance and fall handling
- +Safe bring-up of a full-size machine
- +Testing in simulation (URDF/MJCF) before touching hardware
- +Running published learned policies
Openness
- not publicCAD
- not publicBOM
- not publicFirmware
- publicSim model
- publicSoftware
- publicPolicies
Score 40/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Hardware license: Proprietary. Software license: BSD-3-Clause.
Repos & models
Build it
Closed hardware. Buy link only.humanoidrobot.build/unitree/h1 · Closed hardware. Buy link only.
Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
None. This is the top. Find people building it on humanoidrobots.team.
This is the top of the ladder.
NoteSDK/sim/RL code are BSD-3 open source; hardware proprietary. unitree_rl_gym ships pre-trained locomotion policies for g1, h1 and h1_2. Sibling H1-2 is a heavier, longer-armed variant.
Sources
- [1]Unitree H1 product pagechecked 2026-09-24
- [2]unitree_ros URDFschecked 2026-09-24