HumanoidUnitree Robotics2024CN
Unitree H1-2
Revised H1 with 7-DOF arms, added ankle DOF and higher arm payload, trading top speed for manipulation.
Difficulty index
10.2/13| Class | humanoid | +5 |
|---|---|---|
| Cost | unknown · midpoint | +1.5 |
| DOF | 27 DOF | +2.7 |
| Parts | unknown · midpoint | +1 |
Top of the ladder. This robot lives on the humanoid domains.
humanoidrobots.systems/unitree/h1-2 ↗
Full spec sheet and comparisons
humanoidrobot.build/unitree/h1-2
Closed hardware. Buy link only.
humanoidrobots.training/unitree/h1-2 ↗
Simulate and train policies
Specimen photographs
3 items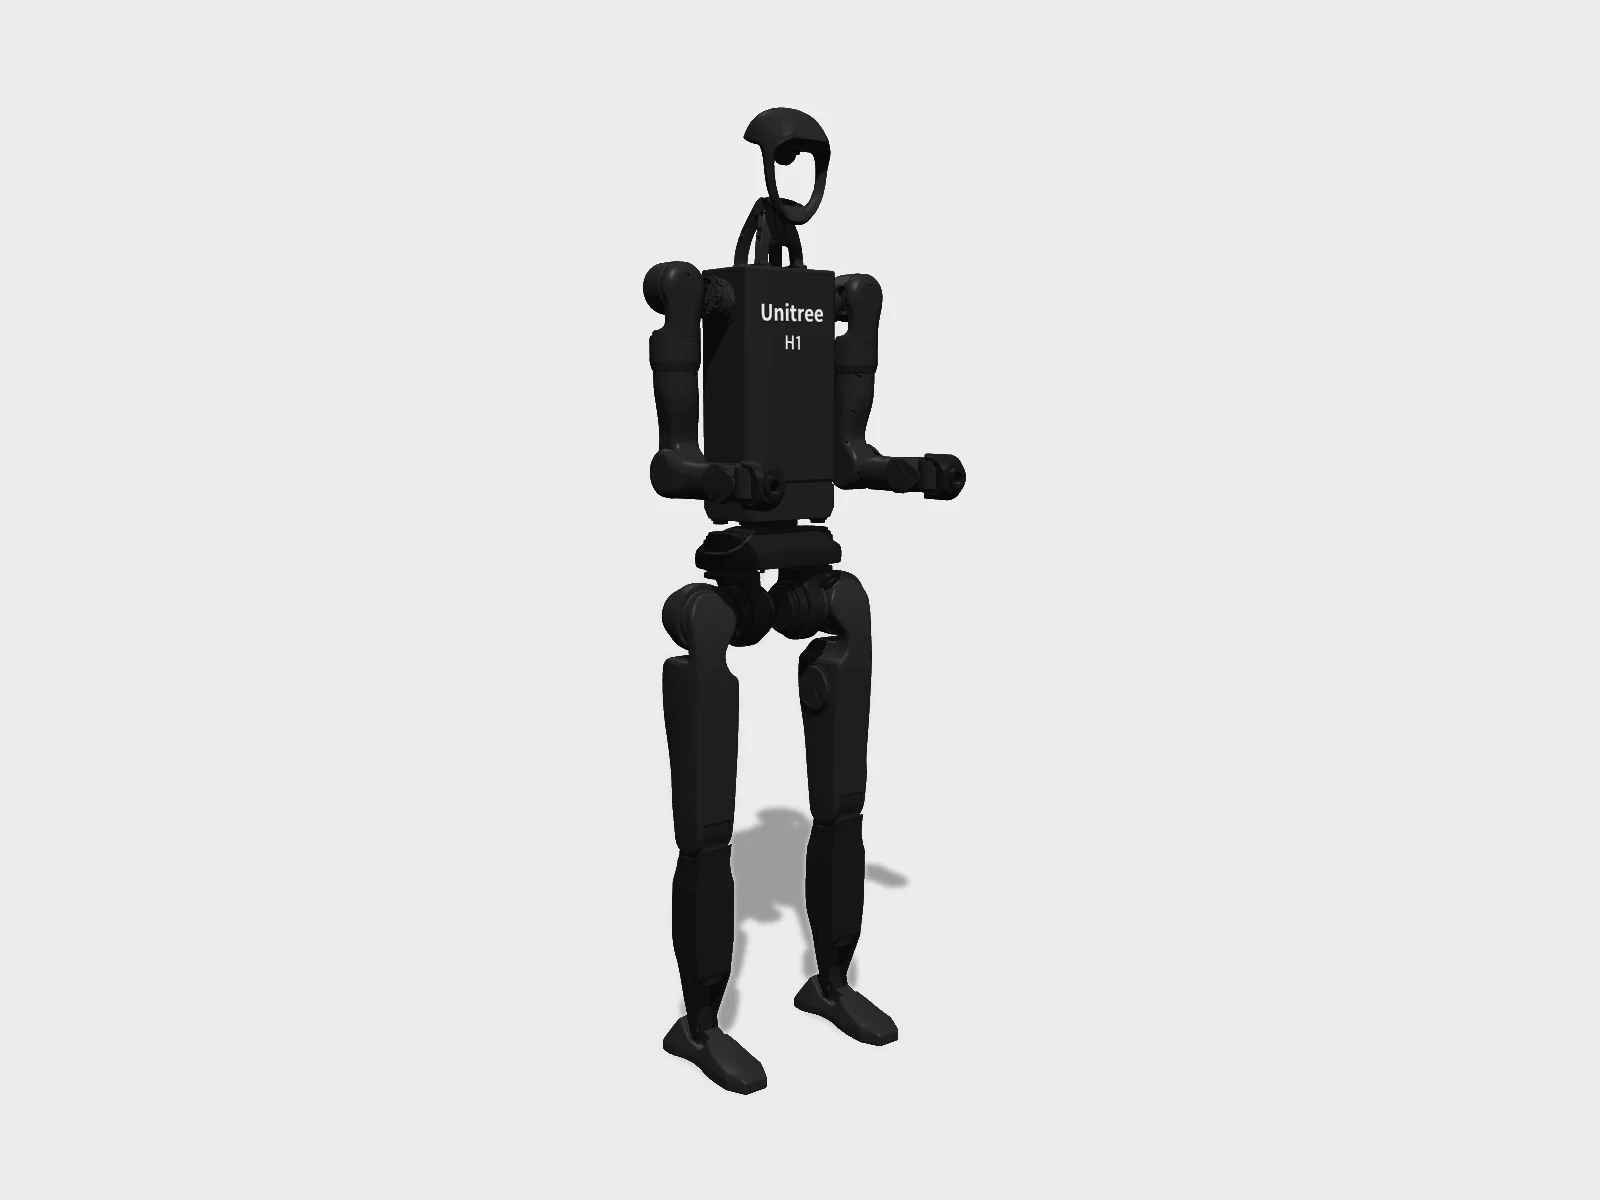
Studio render of the published MJCF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from unitreerobotics/unitree_mujoco (BSD-3-Clause) · Hyperspawn render · source 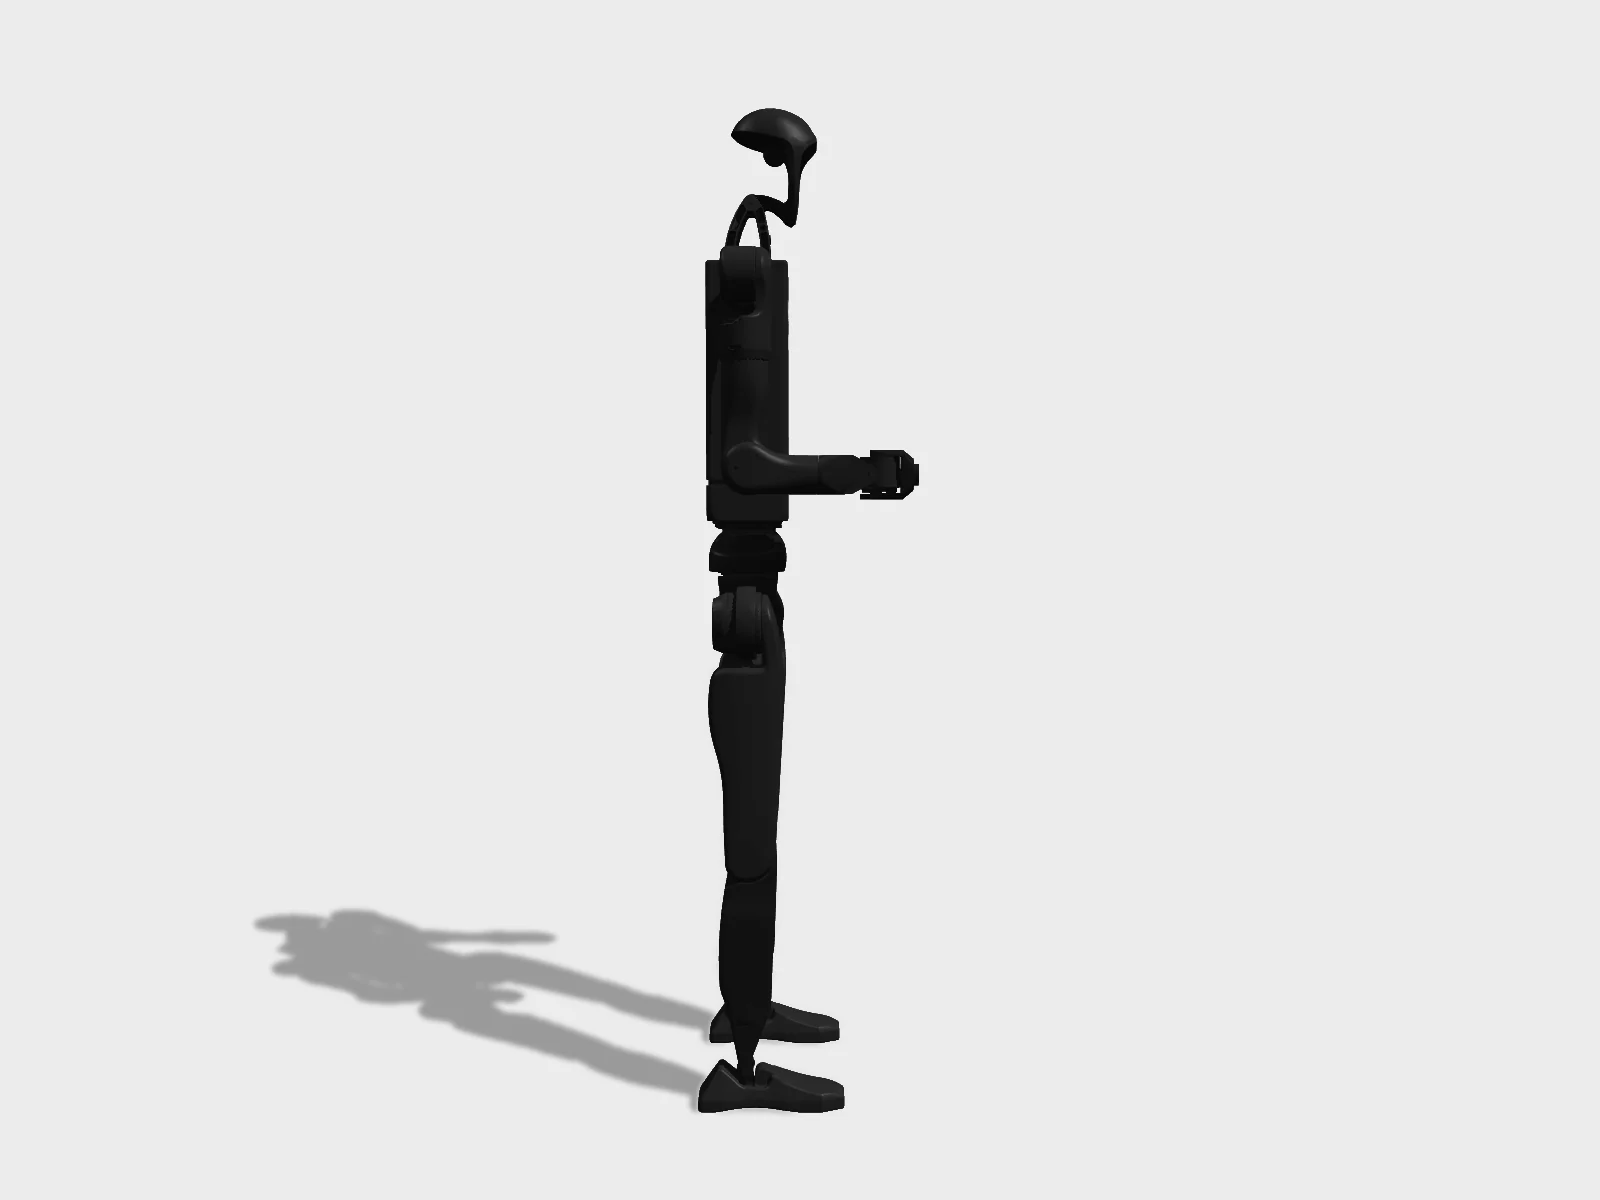
Side view of the same MJCF render, the model's zero pose.Rendered by Hyperspawn from unitreerobotics/unitree_mujoco (BSD-3-Clause) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from unitreerobotics/unitree_mujoco (BSD-3-Clause) · Hyperspawn render · source
Spec card
9/13 known- Degrees of freedom
- 27
- Height
- 178 cm
- Mass
- 70 kg
- Payload
- 7 kg
- Speed
- 2 m/s
- Battery
- 864 Wh
- Actuators
- Unitree in-house electric joint motors
- Compute
- Intel Core i5 standard; i7 or up to 3x Jetson Orin NX optional
- Sensors
- 3D LiDAR, depth camera
Not in the registry: runtime, price, bom total, part count. Left blank rather than guessed.
What you learn building it
- +Whole-body control
- +Dozens of actuators on one bus
- +Balance and fall handling
- +Safe bring-up of a full-size machine
- +Testing in simulation (URDF/MJCF) before touching hardware
- +Running published learned policies
Openness
- not publicCAD
- not publicBOM
- not publicFirmware
- publicSim model
- publicSoftware
- publicPolicies
Score 40/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Hardware license: Proprietary. Software license: BSD-3-Clause.
Repos & models
Build it
Closed hardware. Buy link only.humanoidrobot.build/unitree/h1-2 · Closed hardware. Buy link only.
Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
None. This is the top. Find people building it on humanoidrobots.team.
This is the top of the ladder.
NoteShares the H1 product page. The year is inferred from launch coverage and not confirmed on the maker page. Pre-trained h1_2 policy is in unitree_rl_gym/deploy/pre_train.
Sources
- [1]Unitree H1/H1-2 product pagechecked 2026-09-24
- [2]Humanoid.guide H1-2checked 2026-09-24