GripperStanford / Columbia / Toyota Research Institute2024US
UMI Gripper (Universal Manipulation Interface)
Handheld, trigger-activated 3D-printed parallel-jaw gripper with a GoPro and side mirrors for in-the-wild demonstration collection, with policies deployable on robot-mounted grippers.
Difficulty index
4.1/13| Class | gripper | +1 |
|---|---|---|
| Cost | $946 BOM | +1 |
| DOF | unknown · midpoint | +1.5 |
| Parts | 37.519999999999996 parts | +0.6 |
Specimen photographs
4 items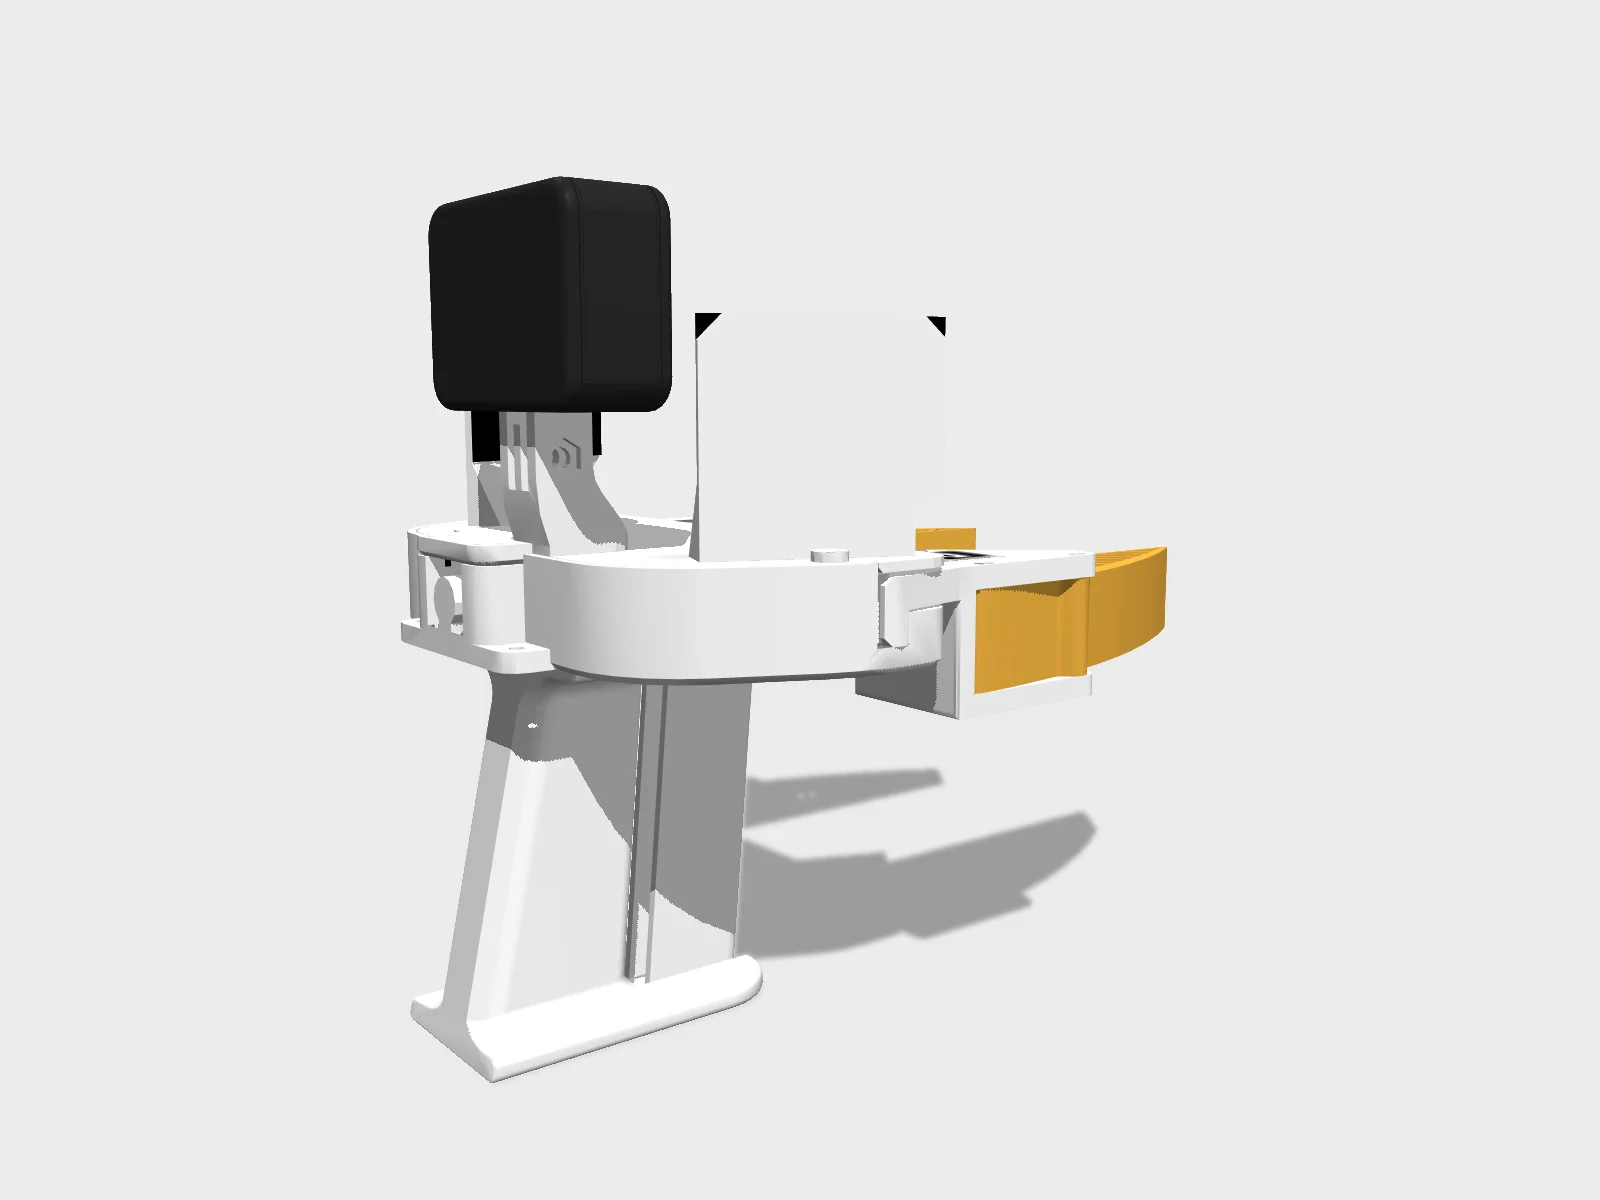
Studio render of the published MJCF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/umi_gripper (MIT) · Hyperspawn render · source 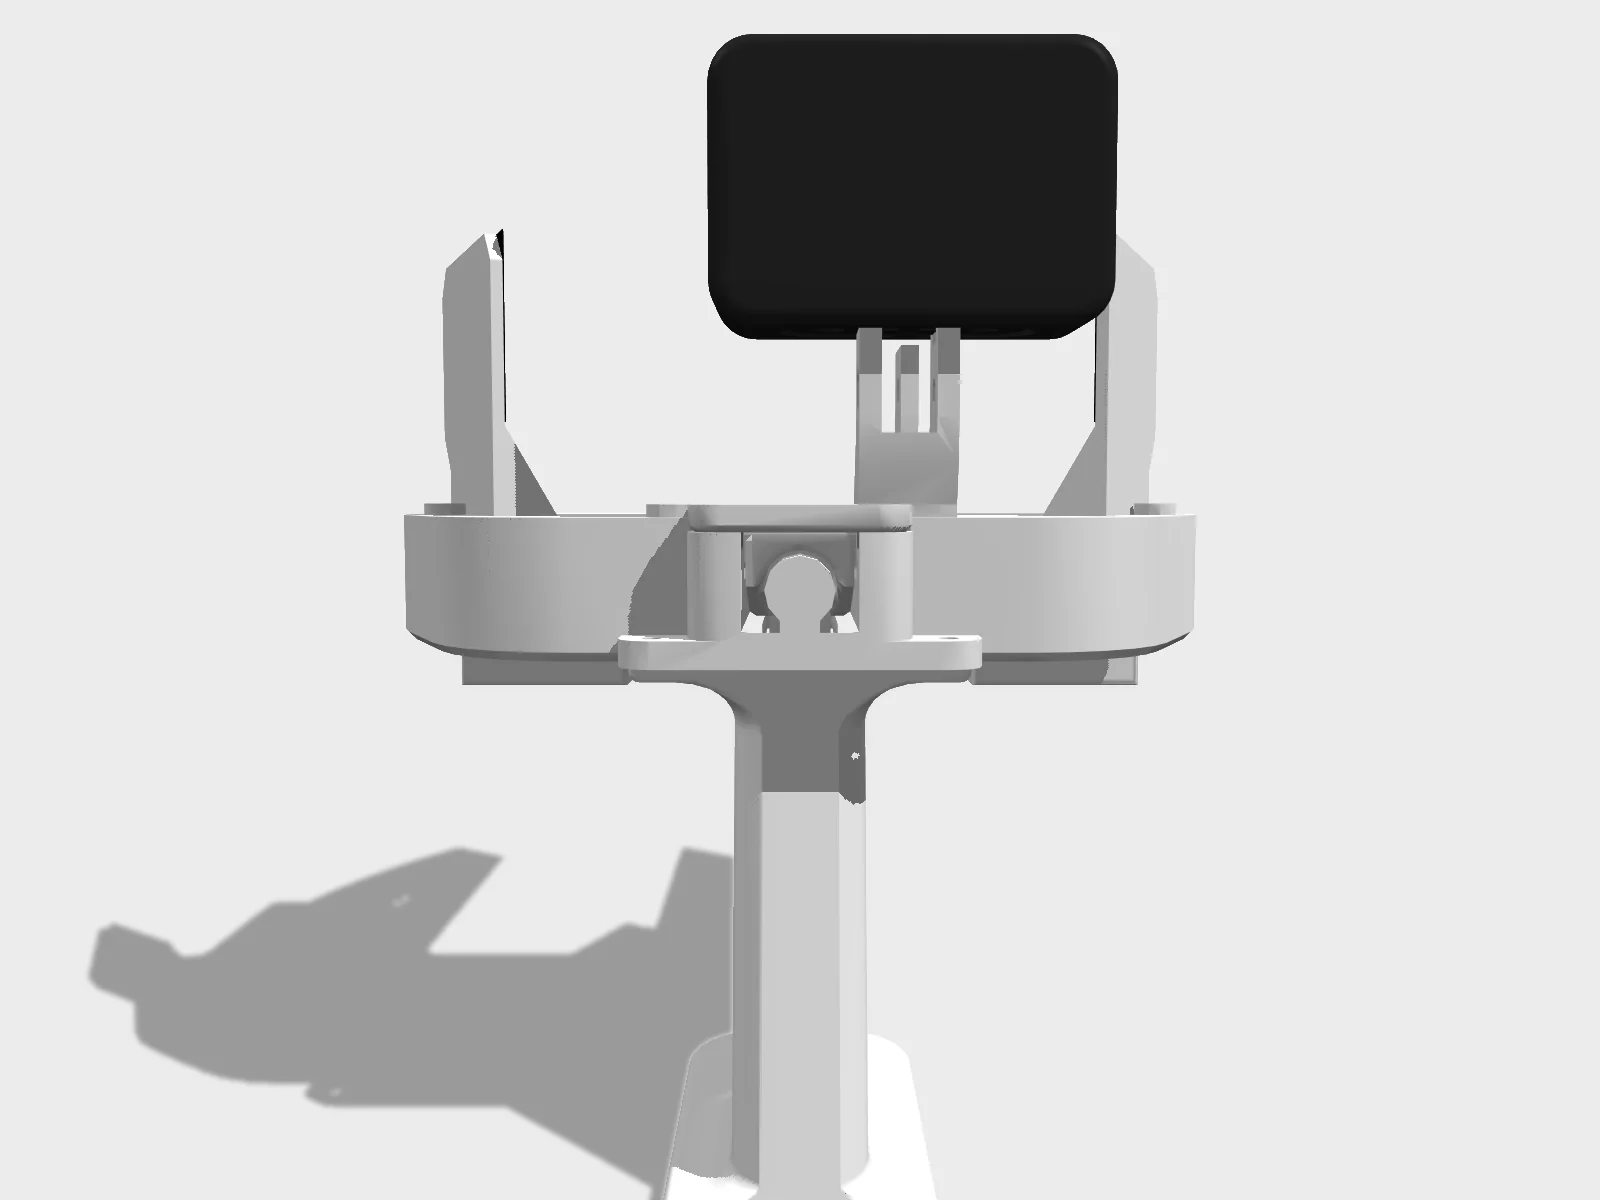
Side view of the same MJCF render, the model's zero pose.Rendered by Hyperspawn from mujoco_menagerie/umi_gripper (MIT) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/umi_gripper (MIT) · Hyperspawn render · source UMI - 3D Printing TutorialRobotics & Embodied Artificial Intelligence Lab · official video, embedded · source
Spec card
3/13 known- BOM total
- $946 · 18/26 lines priced
- Part count
- 37.519999999999996
- Sensors
- GoPro camera with side mirrors
Not in the registry: degrees of freedom, height, mass, payload, speed, runtime, battery, price, actuators, compute. Left blank rather than guessed.
What you learn building it
- +Driving a servo or DC motor from a microcontroller
- +Position vs. force control
- +Linkage and jaw geometry
- +Mounting an end effector to an arm or a bench
- +FDM 3D printing: 13 parts
- +Tools used: FDM printer with 0.6 mm nozzle, Ultimaker Cura, FDM printer with 0.6 mm nozzle (TPU-capable), M3 hex key, Screwdriver, Phone or PC screen for QR codes, Docker, Miniforge (mamba) +3
- +21 assembly steps across 8 subassemblies
- +Flashing firmware for GoPro HERO9 (GoPro Labs firmware + UMI settings QR), Weiss WSG-50 (Lua startup script umi/real_world/cmd_measure.lua), UR5e / UR5-CB3 (stock controller, remote control mode)
- +Testing in simulation (URDF/MJCF) before touching hardware
- +Running published learned policies
Openness
- publicCAD
- publicBOM
- not publicFirmware
- publicSim model
- publicSoftware
- publicPolicies
Score 85/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Software license: MIT.
Repos & models
Build it
Has an ORP build package.- BOM total
- $946
- Lines priced
- 18/26
- Parts
- 37.519999999999996
- Steps
- 21
- Version
- 0.1.0
8 lines have no price yet, so the real total is higher.
Largest BOM lines
| Part | Qty | Unit |
|---|---|---|
| GoPro HERO9 BlackHERO9 Black | 1 | $209.99 |
| GoPro HERO9 Black (robot wrist camera)HERO9 Black | 1 | $209.99 |
| Elgato HD60 X capture cardHD60 X | 1 | $147.34 |
| GoPro Media Mod for HERO9 (HDMI out) | 1 | $79.99 |
| GoPro Max Lens Mod 1.0 (ultra-wide lens for HERO9)Max Lens Mod 1.0 | 1 | $69.29 |
| GoPro Max Lens Mod 1.0 (robot camera)Max Lens Mod 1.0 | 1 | $69.29 |
| MGN9C 150 mm linear rail with carriageMGN9C 150 mm | 2 | $17.89 |
| USB-C to USB-A cable, 10 ft | 2 | $13.49 |
- BOM prices are the Hardware Guide's Jan 2024 Amazon US figures; some quantities are fractions of a pack (0.5 PLA spool, 0.25 TPU spool, 0.07 grip tape roll). Mirror, grease, double-sided tape and tag quantities are blank upstream and set to 1 here.
- Every gripper vendor link is Amazon US (reduced here to /dp/ASIN); there are no EU, CN or IN sources upstream. The guide specifies a GoPro HERO9 with Max Lens Mod 1.0; HERO9 and Max Lens Mod 1.0 availability may be limited now.
- BOM is per gripper; bimanual collection needs two grippers with different ArUco tag sets.
- Assembly steps come from the assembly video; there is no written step-by-step assembly doc, so screw placement per step is not documented in text.
- Deployment hardware is expensive and partly unpriced: UR5e is by quote, the WSG-50 is €3875 (EUR, not converted). Franka and ARX X5 deployments are documented in separate files and repos.
- The README's download command fetches cup_wild_vit_l_1img.ckpt but its eval command passes cup_wild_vit_l.ckpt (that URL returns 404).
- SLAM (ORB_SLAM3) is the most fragile stage per the README; scene choice and marker size matter.
- The software is only tested on Ubuntu 22.04. Code is MIT; the gripper mechanism is adapted from a Thingiverse Push/Pull Gripper and the soft finger from TRI, whose licenses are not stated in the repo.
- The MuJoCo Menagerie umi_gripper model is a simplified model and is not referenced by the UMI repo.
Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
LeKiwi →SIGRobotics UIUC / Hugging Face LeRobot · rover · index 4.4Easiest buildable rover, the next class up from gripper. Adds differential drive and odometry.
NotePresented at RSS 2024. Repo provides a pretrained checkpoint (cup arrangement). A simplified MJCF is in MuJoCo Menagerie (umi_gripper). The build guide (BOM, CAD, print settings, deployment) is the UMI Hardware Guide Google Doc; assembly is shown in video only. Code is MIT; the gripper mechanism and soft finger are adapted from third-party designs whose licenses are not stated.
Sources
- [1]MuJoCo Menagerie umi_gripperchecked 2026-09-24
- [2]UMI project pagechecked 2026-09-24
- [3]arXiv paperchecked 2026-09-24
- [4]Code repo (MIT)checked 2026-09-24
- [5]UMI Hardware Guide (BOM, CAD, print settings, deployment)checked 2026-09-25
- [6]UMI pretrained checkpointschecked 2026-09-25