Path 3 of 3 · Hu · 4 steps
Humanoid
Everything below at once, standing up. Small biped first, then a full humanoid with a published package.
- 01
A desk-scale biped
Bipedal bring-up at a size where falls are cheap.
Done whenA small biped stands, then walks with a learned policy, and you have a fall routine.
Read / watch / run
- Open Duck Mini
Antoine Pirrone · Repo · free · github.com/apirrone/Open_Duck_Mini
A small, printable bipedal robot with an RL walking policy: legged bring-up at desk scale.
- MuJoCo documentation
Google DeepMind · Docs · free · mujoco.readthedocs.io/en/stable/overview.html
The physics engine behind most open robot sims: MJCF models, actuators, contacts, sensors.
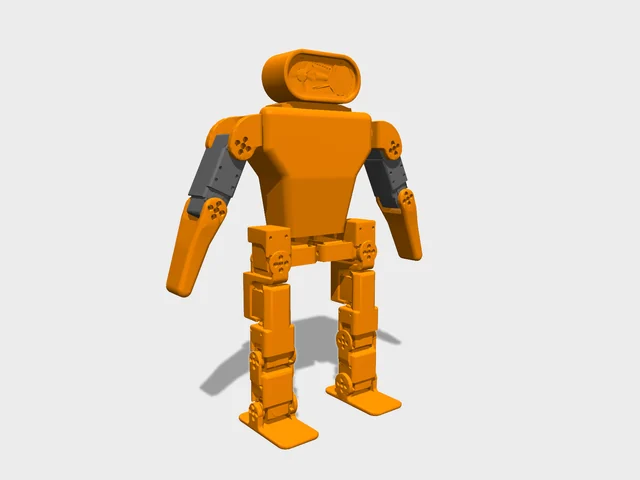
BenchOpen Duck Mini parts: printed shell, small servos, an IMU and a single-board computer, per its repo BOM. - Open Duck Mini
- 02
Build a humanoid
Dozens of actuators on one bus, harnessing, safe power-up.
Done whenEvery joint homes and holds; the e-stop cuts power; the robot holds a supported stand.
Read / watch / run
- Berkeley Humanoid Lite docs
UC Berkeley Hybrid Robotics · Docs · free · berkeley-humanoid-lite.gitbook.io/docs
Build an open, printed-gearbox humanoid: actuators, electronics, assembly and RL locomotion.
- ODrive getting started
ODrive Robotics · Docs · free · docs.odriverobotics.com/v/latest/guides/getting-started.html
Wiring, configuring and calibrating a BLDC motor driver: the core of every quasi-direct-drive leg.
Practise on · computed
Buildable robots of this class, easiest first by the difficulty index; robots with a build package listed first.
- Berkeley Humanoid Lite docs
- 03
Locomotion policies
Run and check published walking policies, then train your own.
Done whenA published policy walks your model in sim with the same observation contract as its source.
Read / watch / run
- unitree_rl_gym
Unitree Robotics · Repo · free · github.com/unitreerobotics/unitree_rl_gym
Train, sim2sim-check in MuJoCo and deploy walking policies for Unitree G1, H1 and Go2.
- Isaac Lab documentation
NVIDIA · Docs · free · isaac-sim.github.io/IsaacLab/main/index.html
GPU robot-learning framework: environments, RL and imitation workflows, sim-to-real.
- MuJoCo Playground
Google DeepMind · Tool · free · playground.mujoco.org
GPU-accelerated RL environments for quadrupeds, humanoids and hands, with sim-to-real examples.
- Underactuated Robotics
Russ Tedrake, MIT · Book · free · underactuated.mit.edu
Walking, balance and control of robots that can fall over: the theory behind legged locomotion.
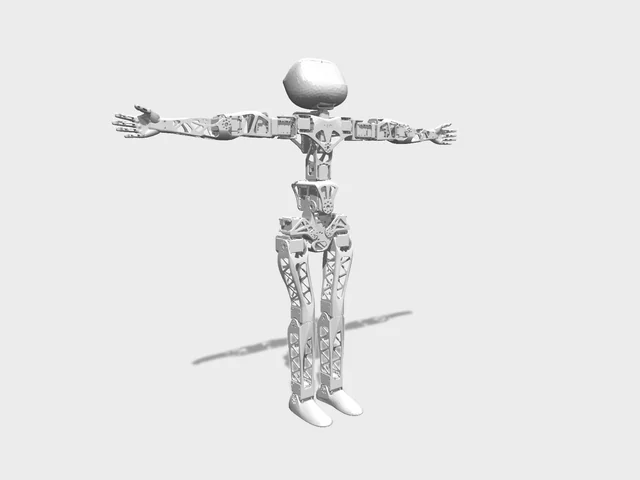
BenchThe robot you built in the build step of this path. - unitree_rl_gym
- 04
Hands and manipulation
Grasping, teleoperation and imitation learning on a whole body.
Done whenA recorded dataset of one bimanual task and a policy that repeats it.
Read / watch / run
- Robotic Manipulation
Russ Tedrake, MIT · Book · free · manipulation.mit.edu
Perception, planning and control for picking things up, with runnable notebooks.
- LeRobot documentation
Hugging Face · Docs · free · huggingface.co/docs/lerobot/index
Install LeRobot, record datasets, train and evaluate policies on low-cost arms.
- Robotics course
Hugging Face Learn · Course · free · huggingface.co/learn/robotics-course
Robot learning from the ground up with LeRobot: data, policies, real hardware.
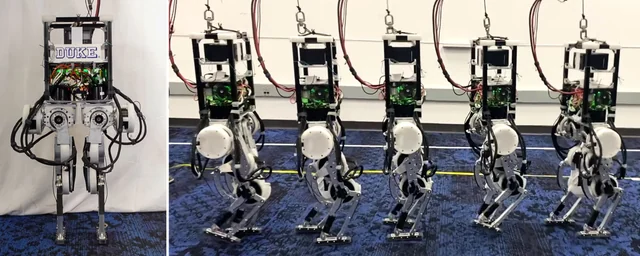
BenchThe robot you built in the build step of this path. - Robotic Manipulation
Resource links checked 2026-09-25.