Path 2 of 3 · Q · 4 steps
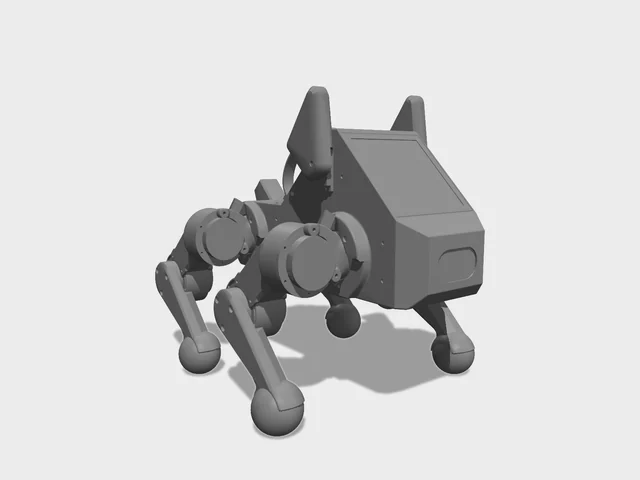
Quadruped
Four legs and a robot that can fall. Actuators, gaits, state estimation, then sim-to-real walking.
- 01
Start with a servo quadruped
Servo calibration, gait tables, a serial skill protocol.
Done whenYour robot walks, turns and stands up from a script you edited.
Read / watch / run
- Petoi documentation
Petoi · Docs · free · docs.petoi.com
Assemble, calibrate and program the Bittle and Nybble servo quadrupeds (OpenCat firmware).
- OpenCat firmware
Petoi · Repo · free · github.com/PetoiCamp/OpenCat
Open quadruped firmware for Arduino and ESP32 boards: gaits, skills, serial protocol.
- Pupper independent study
Stanford · Course · free · pupper-independent-study.readthedocs.io/en/latest
A self-paced course: build Stanford Pupper, then learn kinematics and gaits on it.
Practise on · computed
Buildable robots of this class, easiest first by the difficulty index; robots with a build package listed first.
- Petoi documentation
- 02
Understand the motor
BLDC drivers, encoders, current limits, torque control.
Done whenOne brushless joint holds position, then follows a torque command, on a bench supply with a current limit set.
Read / watch / run
- ODrive getting started
ODrive Robotics · Docs · free · docs.odriverobotics.com/v/latest/guides/getting-started.html
Wiring, configuring and calibrating a BLDC motor driver: the core of every quasi-direct-drive leg.
- moteus brushless controller
mjbots · Repo · free · github.com/mjbots/moteus
Open firmware and docs for a small high-rate BLDC controller used in many legged robots.
- Open robot actuator hardware
Open Dynamic Robot Initiative · Repo · free · github.com/open-dynamic-robot-initiative/open_robot_actuator
An open, printable brushless actuator module and leg: CAD, BOM and assembly.
BenchOne brushless motor, a driver board and a current-limited bench supply. - ODrive getting started
- 03
Gaits and balance
Leg kinematics, gait scheduling, IMU state estimation.
Done whenYou can explain why the robot tips in a trot and change a gait parameter to fix it.
Read / watch / run
- StanfordQuadruped code
Stanford Student Robotics · Repo · free · github.com/stanfordroboticsclub/StanfordQuadruped
The original Pupper controller: inverse kinematics, gait scheduler, joystick control.
- Pupper v3 documentation
Stanford Student Robotics · Docs · free · pupper-v3-documentation.readthedocs.io/en/latest
Build and program a brushless quadruped with ROS 2 and a learned walking policy.
- Underactuated Robotics
Russ Tedrake, MIT · Book · free · underactuated.mit.edu
Walking, balance and control of robots that can fall over: the theory behind legged locomotion.
BenchThe robot you built in the build step of this path. - StanfordQuadruped code
- 04
Learn to walk in sim
Train a locomotion policy in parallel simulation, check it sim-to-sim.
Done whenA trained policy walks in MuJoCo on a model that was not the training sim.
Read / watch / run
- MuJoCo Playground
Google DeepMind · Tool · free · playground.mujoco.org
GPU-accelerated RL environments for quadrupeds, humanoids and hands, with sim-to-real examples.
- legged_gym
ETH Zurich Robotic Systems Lab · Repo · free · github.com/leggedrobotics/legged_gym
The reference RL setup for learning to walk in parallel sim, used by many open policies.
- Isaac Lab documentation
NVIDIA · Docs · free · isaac-sim.github.io/IsaacLab/main/index.html
GPU robot-learning framework: environments, RL and imitation workflows, sim-to-real.
BenchA PC with a GPU for training; the robot from step 1 only to test afterwards. - MuJoCo Playground
Resource links checked 2026-09-25.